Related Experiment Video
Updated: Jun 13, 2026
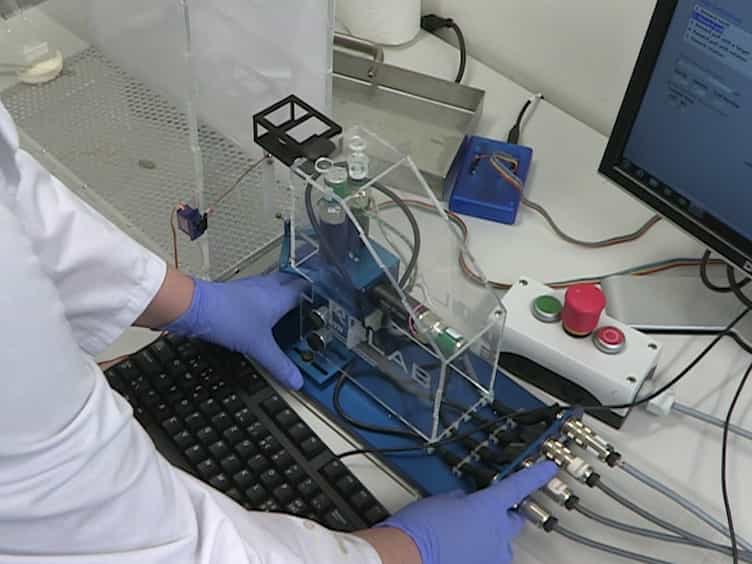
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
The ADePT framework for assessing autonomous laboratory robotics
Pablo Salazar-Villacis1, Brahim Benyahia2
1School of AACME, Loughborough University, Loughborough, UK.

Abstract:
Laboratory robotics is advancing from routine automation toward autonomous systems capable of intelligent decision-making and flexible execution. This perspective outlines key milestones and introduces the ADePT framework, which defines four core dimensions of robotic capability proficiency: adaptability and learning, dexterity, perception, and task complexity. We discuss future directions for self-driving laboratories, including robot-centric, end-to-end robotic integration, and collaborative human-robot environments. These scenarios highlight the importance of technological enablers and evolving regulatory paradigms. By connecting present technologies to emerging system configurations, this work offers a foundation for designing autonomous laboratory ecosystems that support scientific discovery and operational efficiency.
More Related Videos
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
 05:47
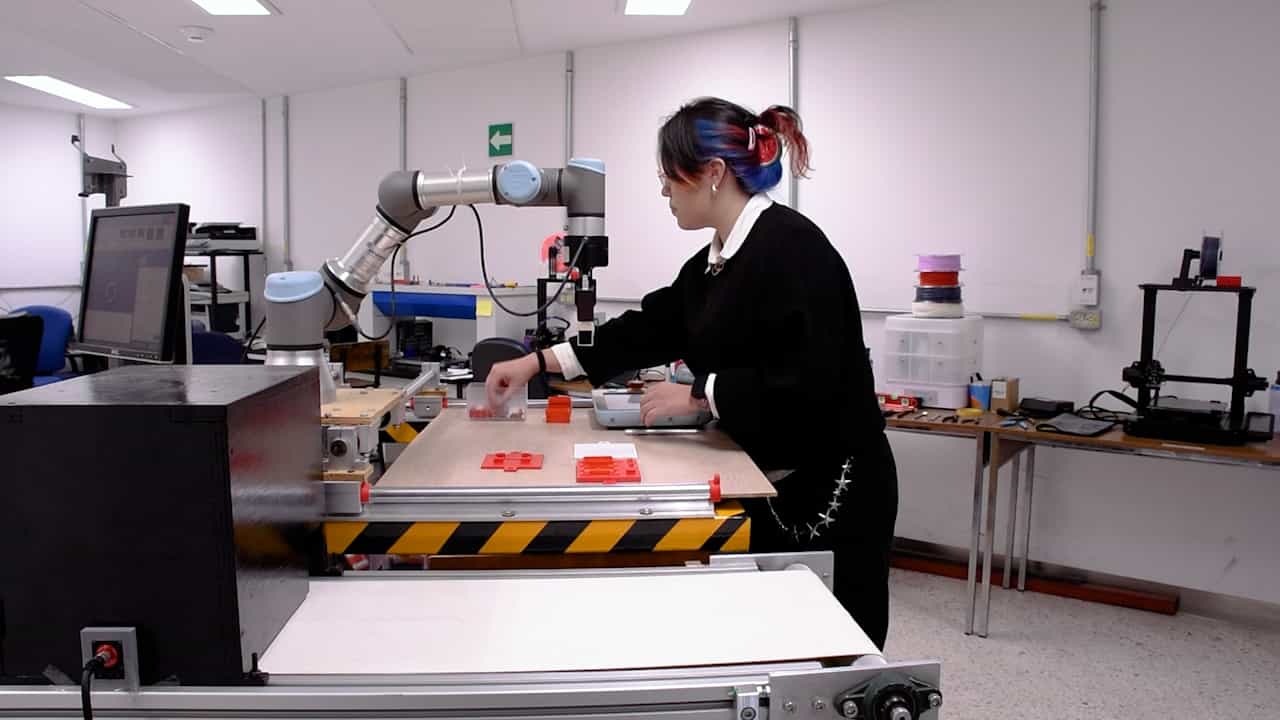
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Related Concept Videos
 01:30
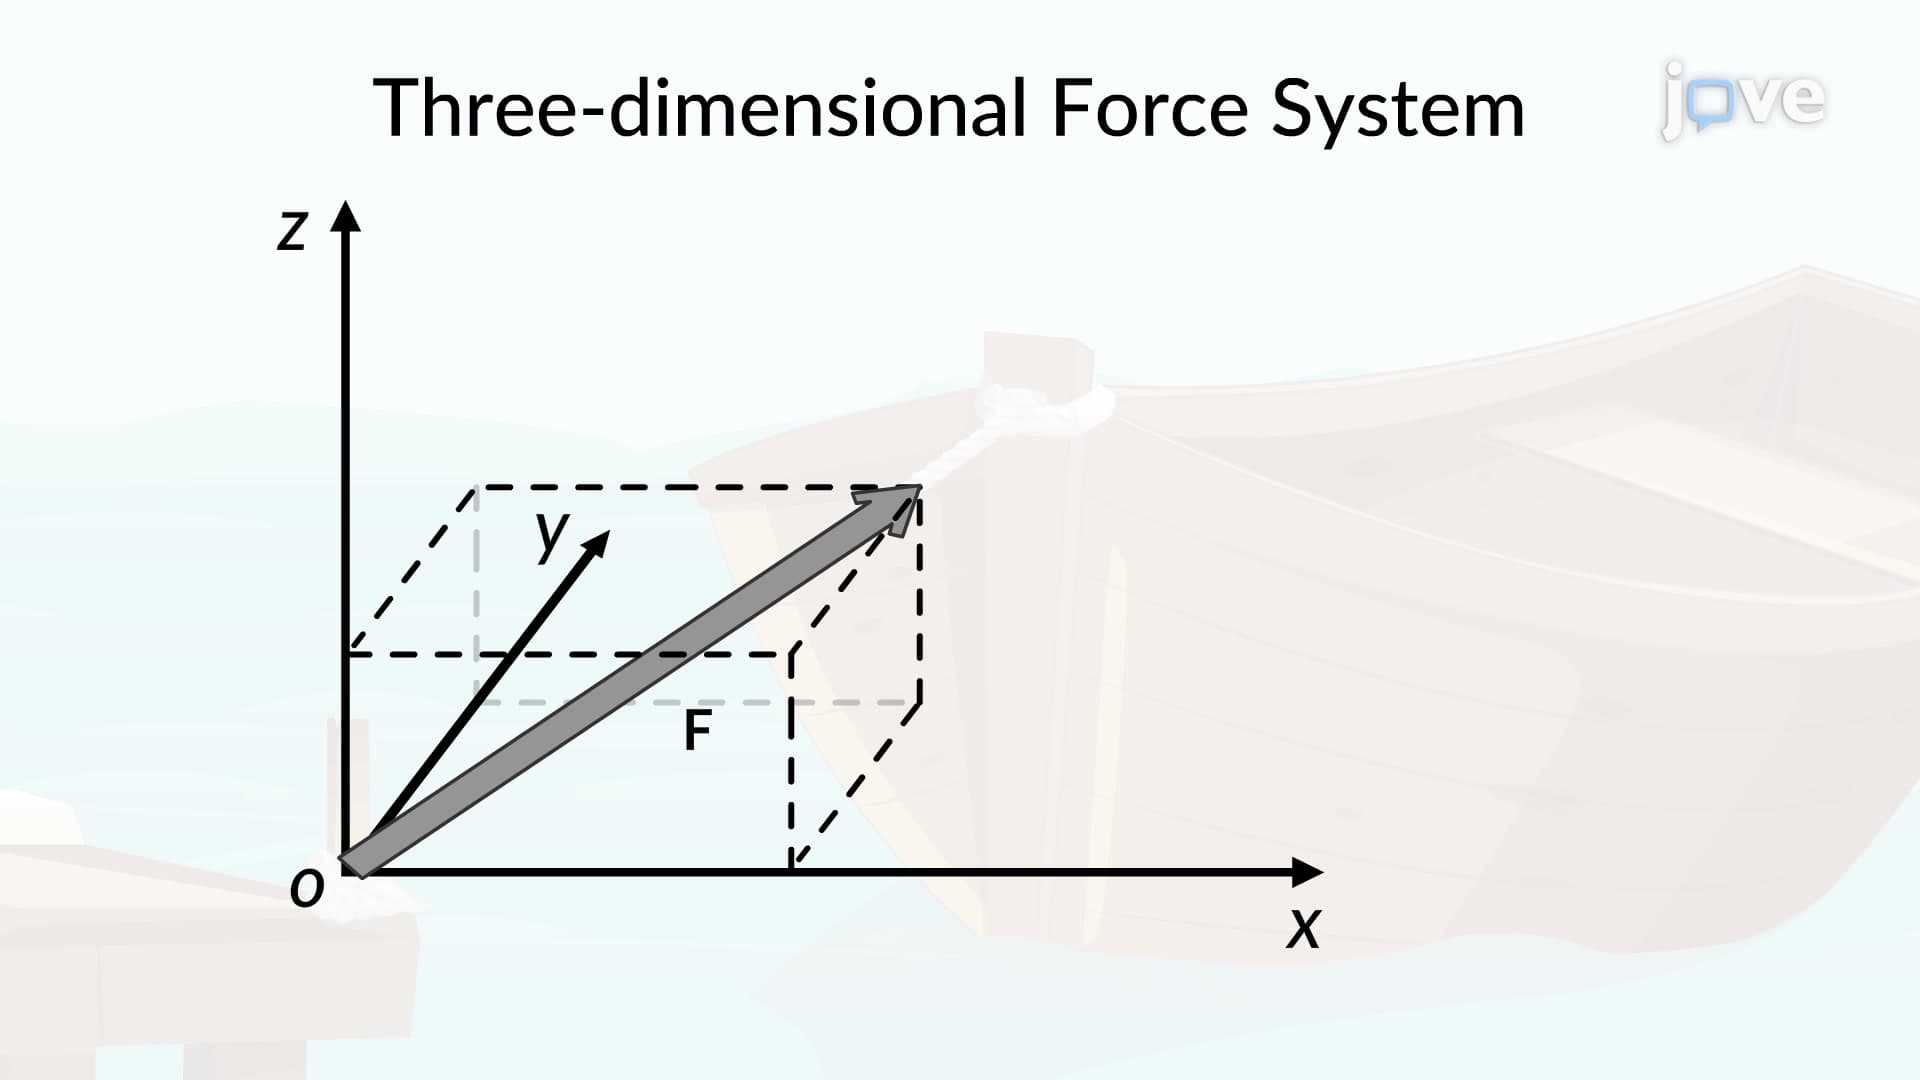
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:14
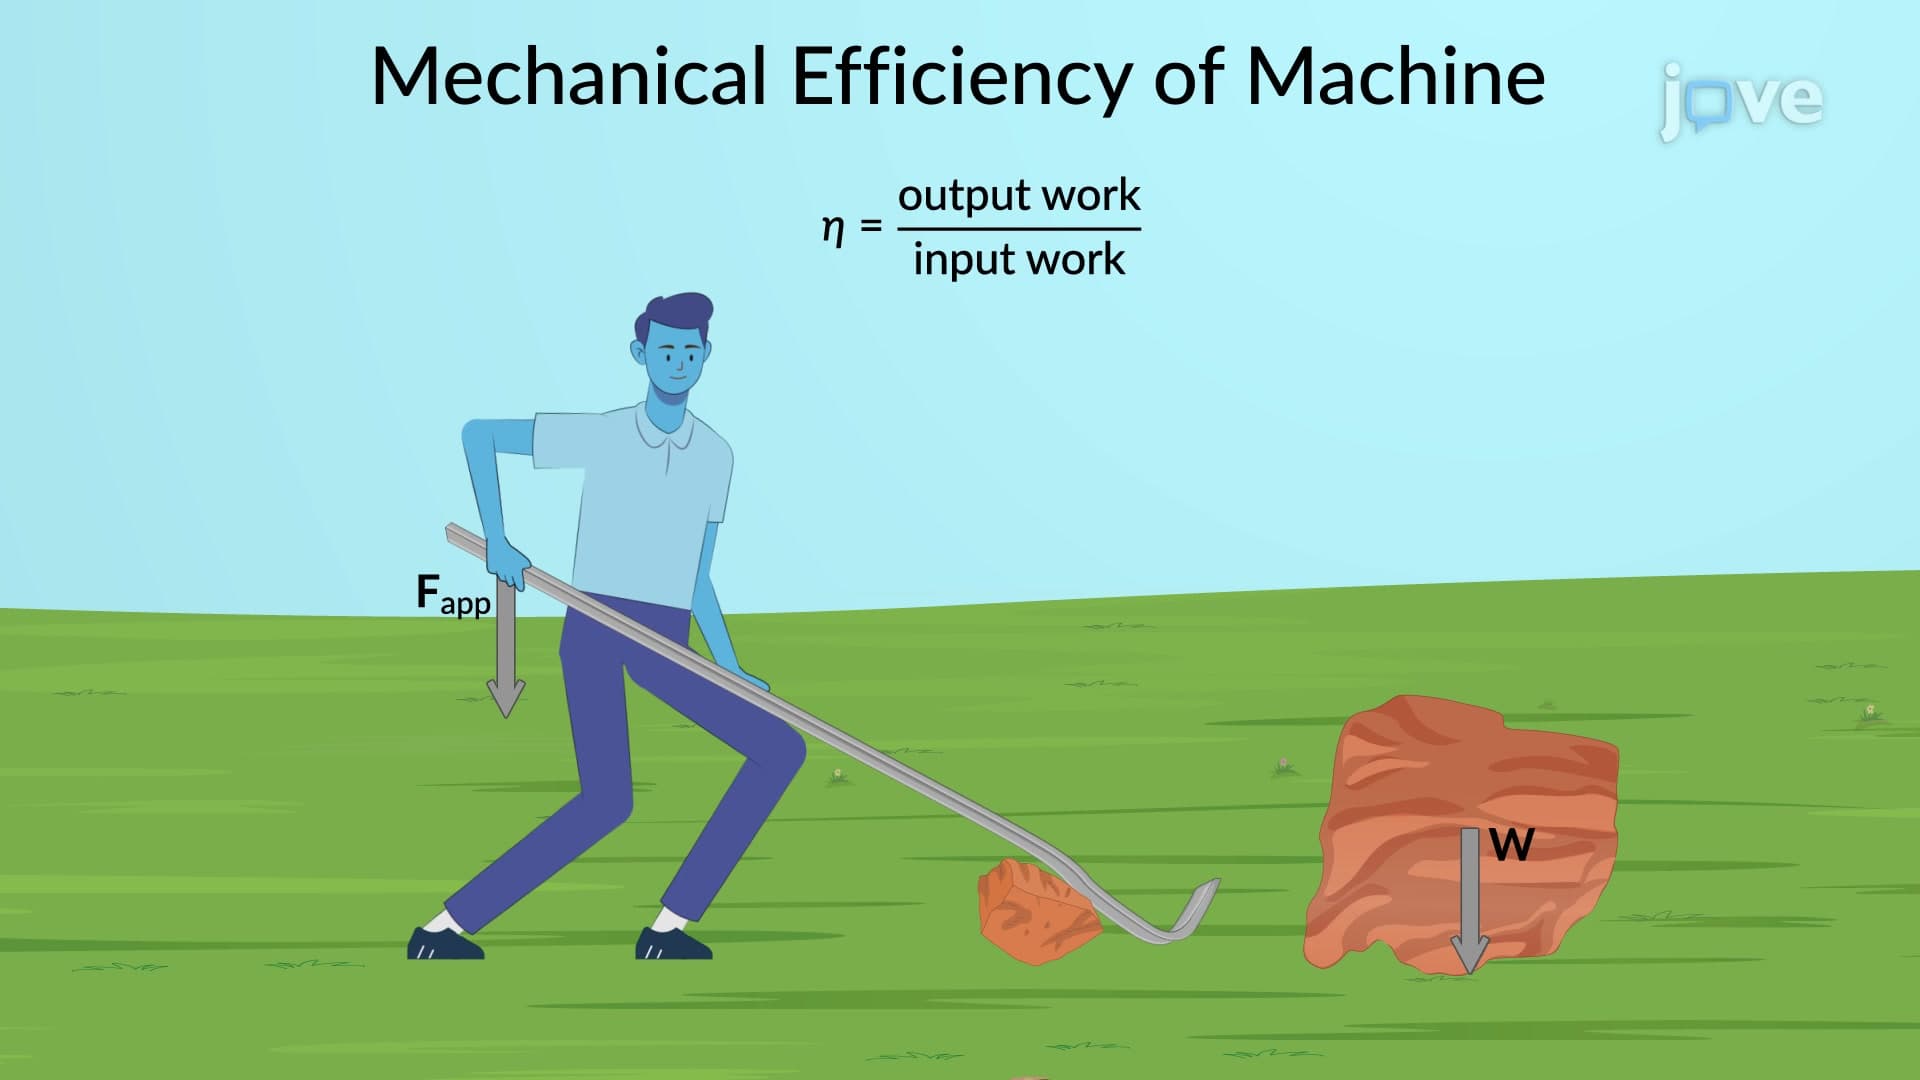
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
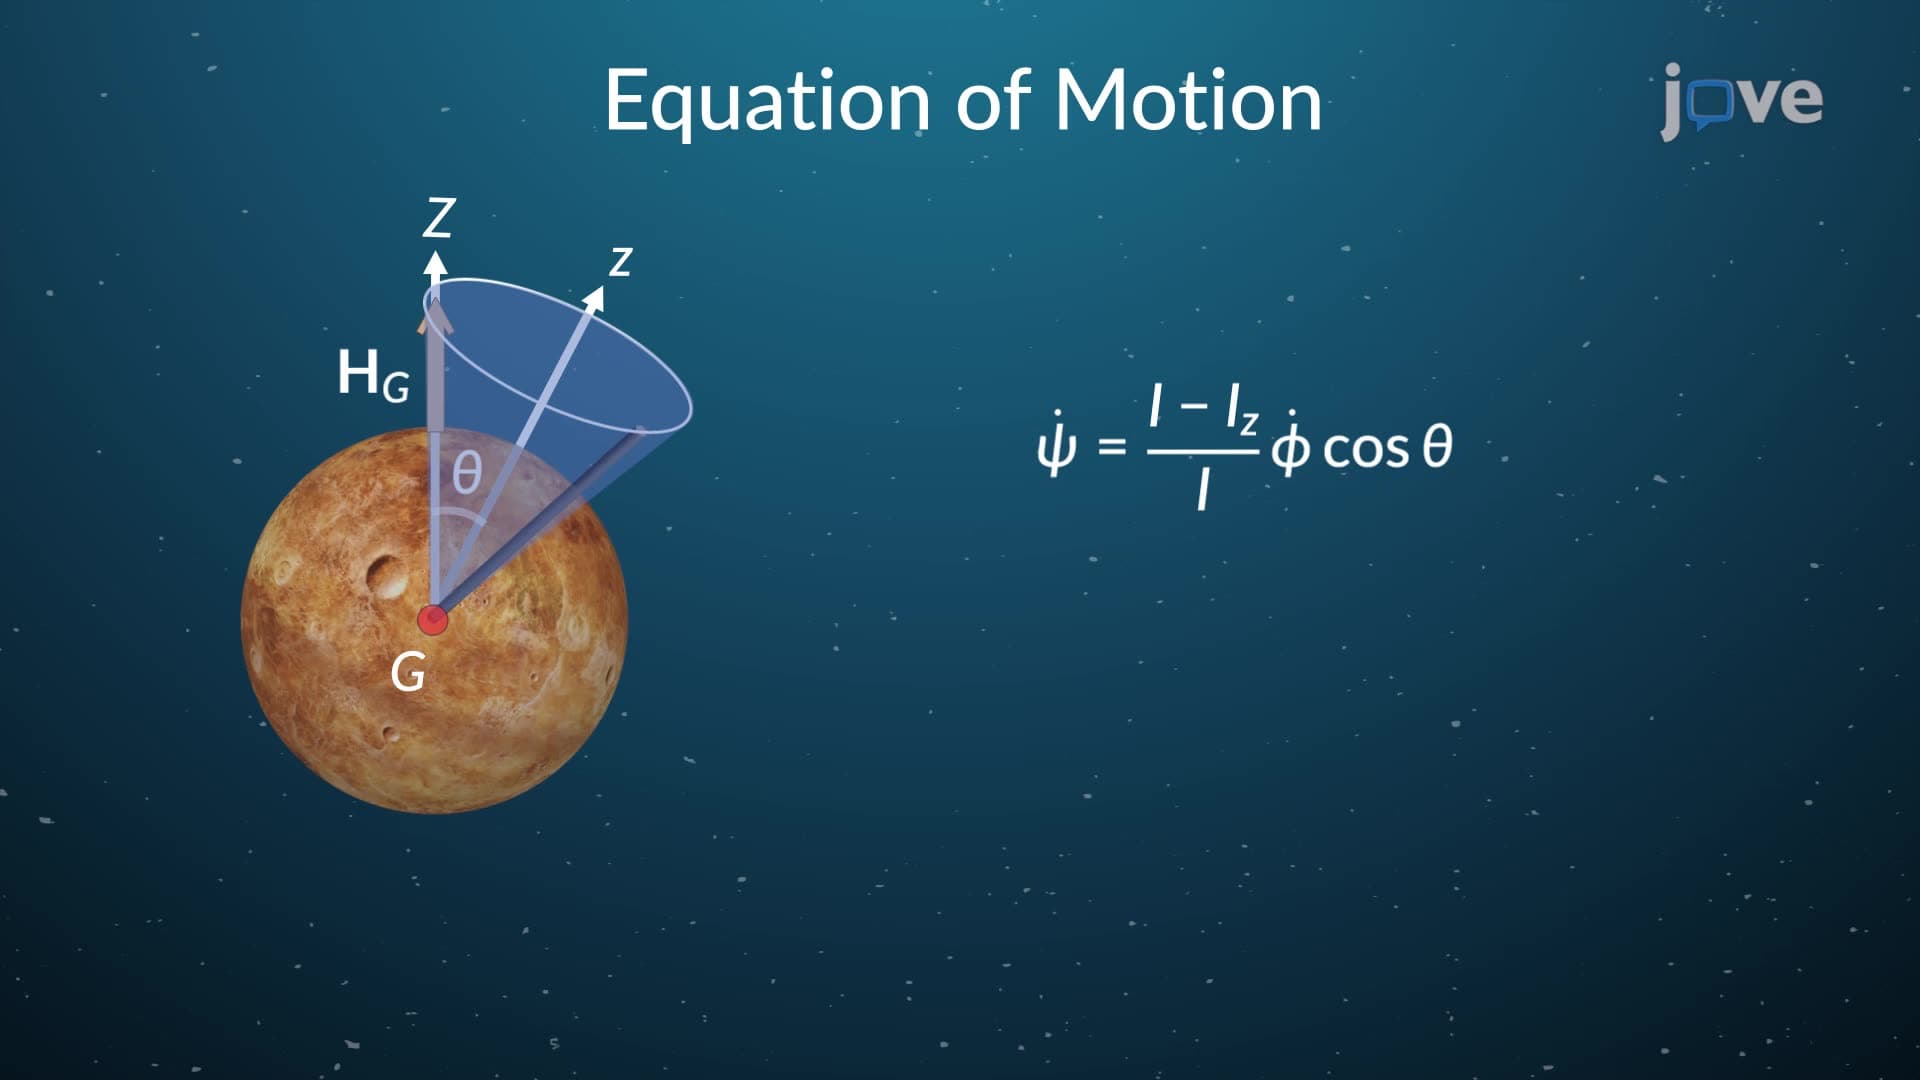
Torque Free Motion
 01:22
Mechanical Systems