Related Experiment Video
Updated: Mar 1, 2026
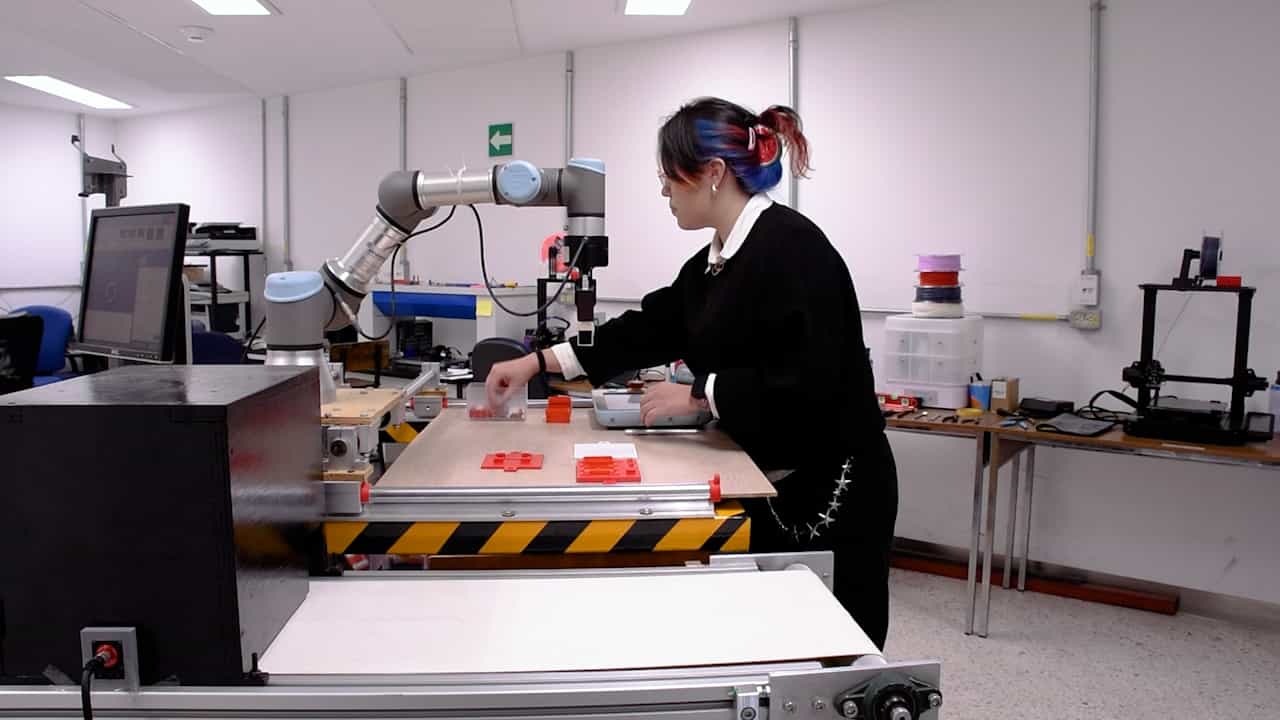
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Fuzzy-based multi-objective scheduling for human-robot manufacturing systems
Yijun Deng1, Binrong Huang1, Shouliang Lai2
1College of Packaging Design and Art, Hunan University of Technology, Zhuzhou, 412000, Hunan, China.

Abstract:
This study addresses the optimization of production planning and scheduling for human-robot interaction in a fuzzy environment, a critical challenge in modern manufacturing, especially under fluctuating market demand. The proposed model simultaneously determines production quantities, inventory/shortage levels, human-robot task allocation, and job sequencing. All decisions are optimized in a multi-period, multi-product setting. Three objective functions are considered: maximizing net present value, minimizing maximum completion time, and minimizing total early and tardy times. To handle uncertainties in demand and processing times, a pessimistic (credibility-constrained) fuzzy programming approach is employed. The model is solved using the epsilon-constraint method for small-scale problems and metaheuristic algorithms (NSGA-II, MOPSO, and MOWOA) for larger instances. Sensitivity analyses reveal that reducing completion times increases costs, lowering net present value, while higher uncertainty rates increase production times and shortages, reducing net present value. A 4% increase in bank interest rate reduces net present value by 15.68%, with no impact on completion or early/tardy times. The MOWOA algorithm demonstrates superior performance in generating efficient solutions for large-scale problems, offering practical insights for optimizing human-robot collaboration in manufacturing.


Related Concept Videos
 02:16
Stereotype Content Model
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...