Related Experiment Video
Updated: Mar 7, 2026
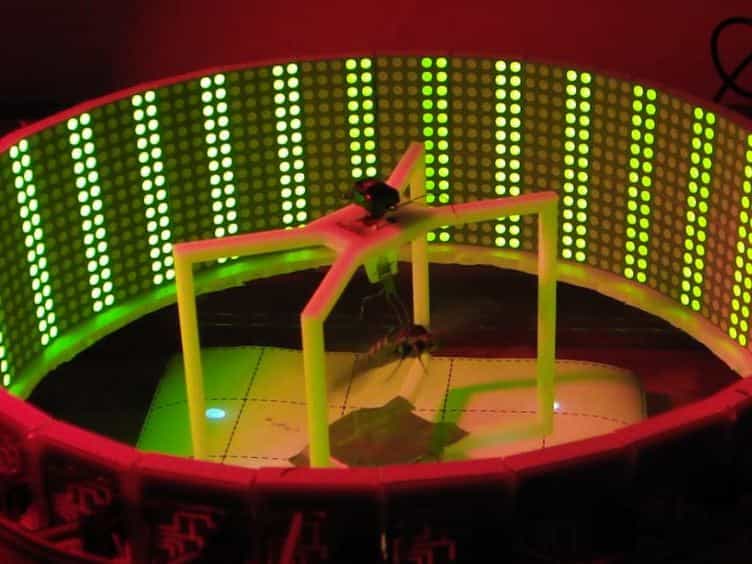

Early Metamorphic Insertion Technology for Insect Flight Behavior Monitoring
Published on: July 12, 2014
Mechanical intelligence for artificial wings: A philosophy for multifold high-degree morphing with its mechanisms
1Artificial Intelligence Innovation and Incubation Institute, College of Computer Science and Artificial Intelligence, Fudan University, Shanghai 200433, China.

Abstract:
Birds and fish have morphing propulsors and mechanical intelligence, which are the primary biomimetic inspirations. Myliobatid pectoral fins, which are morphologically similar to bird wings, are of particular interest. Artificial wings are expected to achieve multifold high-degree morphing, a substantial challenge and long-standing desire that current design philosophies have yet to effectively solve. Derived mathematically and inspired by the alignments of the skeletal joints of myliobatid fins, we propose a morphing philosophy for artificial wings: cross-section invariance. This philosophy facilitates simultaneous out-of-plane and planform morphing, simplifies proprioception, sensing, and control (the important aspects of mechanical intelligence), and features the intrinsic mechanisms analogous to the biological ones across morphing types and species. We mathematically characterize, verify, and validate the morphing philosophy and its intrinsic mechanisms. We present the mechanical implementations of the intrinsic mechanisms; each implementation mechanism is exquisitely designed to fulfill multifold roles to collaboratively enable multifold high-degree morphing. We demonstrate prototypes with a larger range of morphing performance that is currently unavailable in artificial wings and the biological counterparts. Our results suggest the potential of the philosophy for multimodal propulsion of biomimetic vehicles.

Related Concept Videos
 01:54
Convergent Evolution
 01:23
Lift
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:22
Mechanical Systems
 01:38
Limits to Natural Selection