Related Experiment Video
Updated: Mar 11, 2026
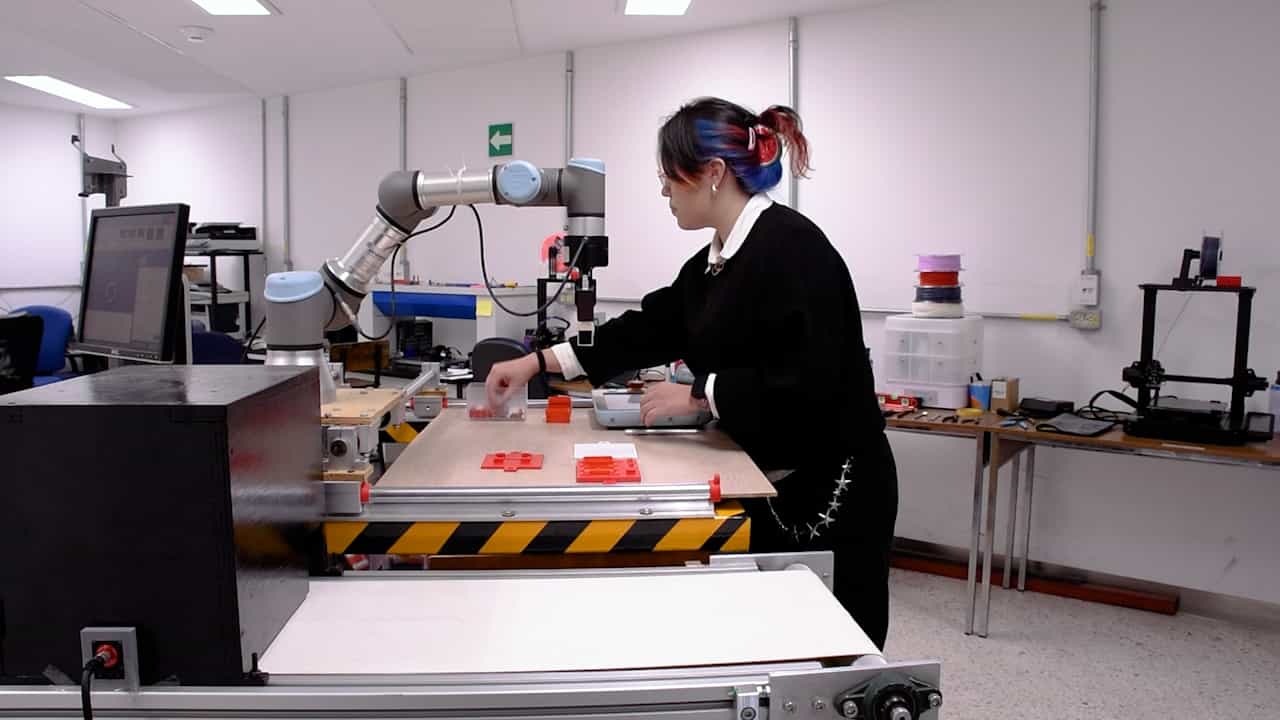

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Dynamic velocity scaling for industrial collaborative robots: a gaze-driven approach
Matteo Manzardo1, Federico Fraboni2, Sofia Morandini2
1Faculty of Engineering, Free University of Bozen/Bolzano, 39100, Bolzano, Italy.

Abstract:
Implementing an effective human-robot seamless interaction (HRSI) is a critical challenge for the industrial robotics community, which requires capturing all human mental processes and turn them into suitable robot's actions. This work presents a method to adjust the robot behavior in real-time considering both human's low-frequency, i.e. cognitive workload, and high-frequency cognitive processes, i.e. visual attention, which are generally overlooked in literature, to optimize safety, productivity and ergonomics. Regarding high-frequency processes, the system monitors the operator's gaze - the closer they look to the robot, the more attentive they are, while attention drops when the robot leaves their field of view, posing potential risks. The speed of the manipulator is then dynamically modulated based on operator's visual attention. Regarding low-frequency processes, the robot's trajectory is adjusted to optimize operator's cognitive workload. An experimental validation involving 26 participants led to three key findings: the developed algorithm improved productivity (18% improvement), cognitive workload (5%), fluency (10%), usability (5%), reliability (5%), and acceptance of the system (9%); the exploitation of high-frequency cognitive processes leads to a significant improvement in all mentioned metrics, suggesting its relevance for future research in the field of HRSI; increasing the level of adaptability of the robotic system positively affects collaboration's effectiveness.

Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:11
Relative Velocity in Two Dimensions
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Relative Velocity in One Dimension