Related Experiment Video
Updated: Mar 12, 2026
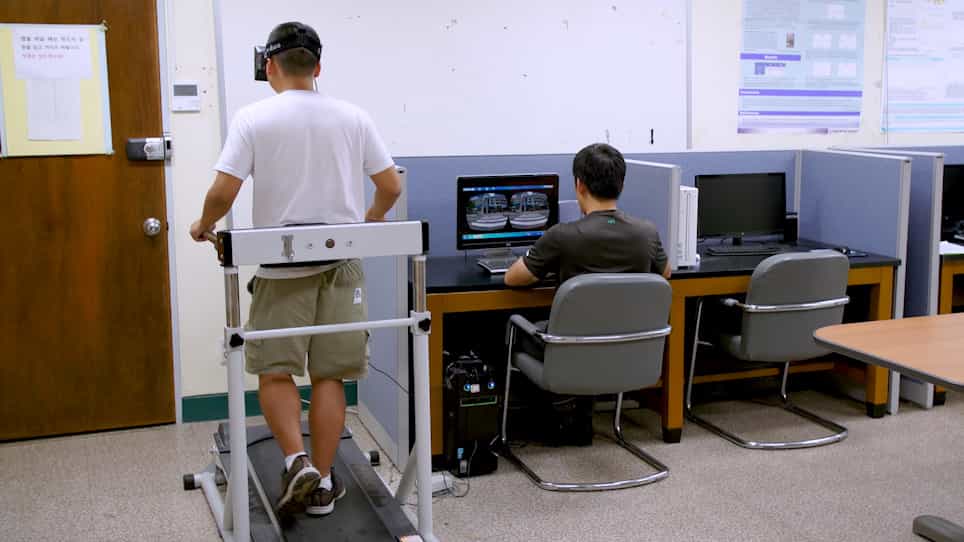

Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
A dynamic conflict-analysis framework for behaviour-centric safety evaluation of pedestrian-vehicle interactions at
Kaliprasana Muduli1, Indrajit Ghosh1
1Transportation Engineering Group, Department of Civil Engineering, Indian Institute of Technology (IIT) Roorkee, Roorkee 247667, Uttarakhand, India.

Abstract:
Pedestrian safety at unsignalized crosswalks remains a critical concern, particularly in heterogeneous traffic environments where formal right-of-way rules are often replaced by informal, real-time negotiations between pedestrians and drivers. Although surrogate safety measures are widely used to quantify interaction outcomes, they provide limited insight into how right-of-way negotiation evolves during pedestrian-vehicle encounters. To address this gap, this study proposes a behavior-oriented framework for analyzing pedestrian-vehicle negotiation dynamics at unsignalized crosswalks. The framework introduces a Negotiation Momentum (NM)-Sustained Dominance Duration (SDD) interaction space to capture both directional evolution of right-of-way and temporal stability of crossing advantage. These indicators are derived from a continuously defined Pedestrian Exit Buffer (PEB), estimated using a Dynamic Conflict Analysis Framework (DCAF) that models conflict geometry through road-user trajectories, heading angles, and representative vehicle dimensions. High-resolution trajectory data from four unsignalized crosswalks in India were used to classify interactions into ten behaviorally interpretable negotiation patterns. SDD thresholds were estimated using Extreme Value Theory, and a neutral NM band was defined to identify contested negotiation states. A multivariate linear mixed-effects model was then employed to examine safety implications of these patterns. Results indicate that safety margins are strongly shaped by negotiation structure: proactive yielding is associated with higher PET, TTC, and PEB values, whereas chaotic negotiation and pedestrian hesitation result in substantially reduced safety margins. The proposed framework provides a behaviorally grounded interpretation of pedestrian-vehicle interactions by explicitly linking safety outcomes with underlying right-of-way negotiation process, complementing conventional surrogate safety assessment at unsignalized crosswalks.


Related Concept Videos
 01:42
Schemas
 01:20
Frustration and Conflict: Approach-Approach, Approach-Avoidance
One common type of conflict is the Approach–Approach Conflict. In this case, a person faces two desirable...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:14
Frustration and Conflict: Avoidance-Avoidance, Double-Approach Avoidance
 01:25
Strategies for Assessing and Addressing Confounding
Confounding can be addressed at both the design phase of a study and through analytical methods after data...
 01:05
Collisions in Multiple Dimensions: Introduction