Related Experiment Video
Updated: Mar 16, 2026


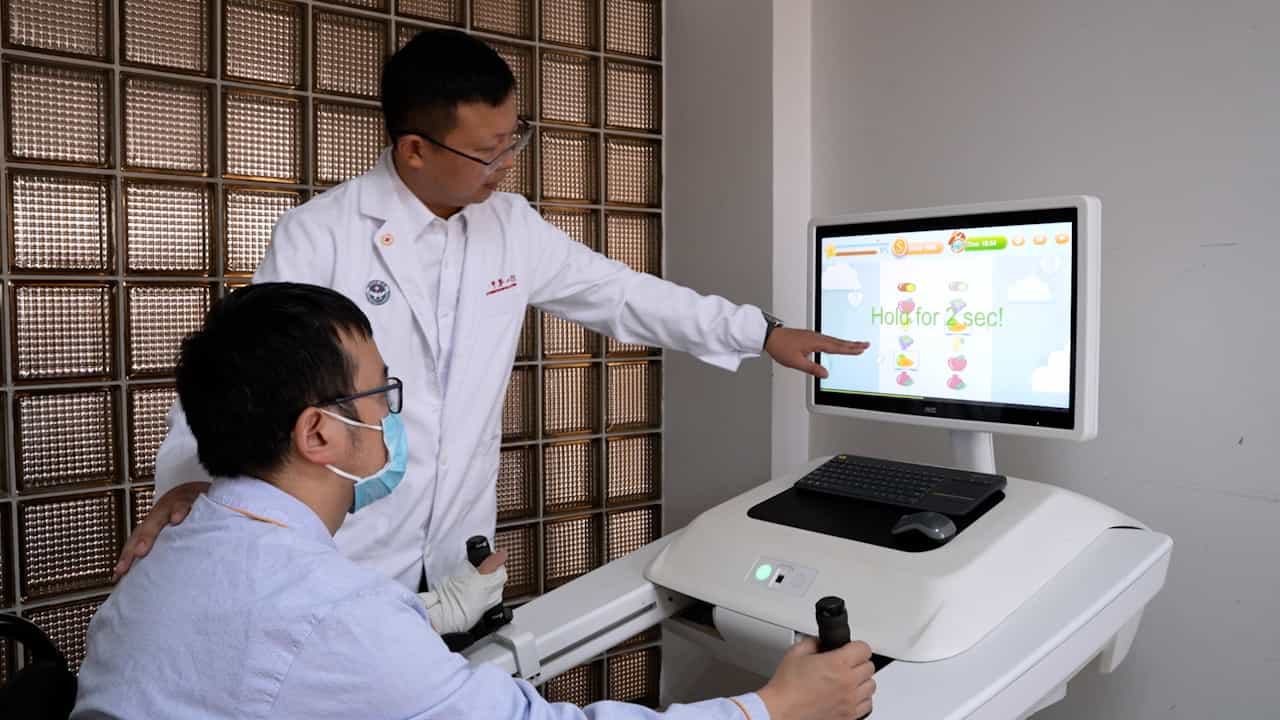
Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Diffeomorphism-transformed adaptive robust control for dual-arm collaborative robot systems with inequality
Qilin Wu1, Kaixuan Yin2, Zicheng Zhu2
1School of Advanced Manufacturing Engineering, Hefei University, Hefei, Anhui 230601, China; Anhui Provincial Engineering Technology Research Center of Intelligent Vehicle Control and Integrated Design Technology, Hefei 230601, China.

Abstract:
To address uncertainty and inequality constraints in dual-arm collaborative robot systems, this paper proposes an adaptive robust control strategy based on the diffeomorphism technique. Specifically, system uncertainties are characterized using fuzzy set theory, while inequality constraints are systematically incorporated into the constraint-following control framework via diffeomorphism. Moreover, an adaptive robust control scheme is developed to ensure practical stability in the presence of uncertainties. In addition, the control parameters are optimized based on the fuzzy description of uncertainty, striking a balance between system performance and control cost. Finally, numerical simulations are conducted to validate the effectiveness of the proposed scheme.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:29
Application of Nonlinear Inequalities
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:15
Kinematic Equations: Problem Solving