Related Experiment Video
Updated: Mar 19, 2026
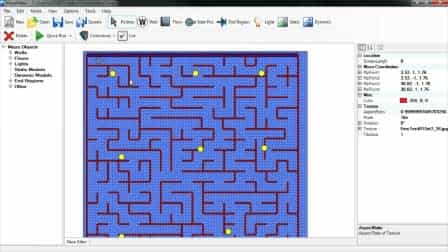

Using MazeSuite and Functional Near Infrared Spectroscopy to Study Learning in Spatial Navigation
Published on: October 8, 2011
Experimental research on visible light-inertial integrated navigation

Abstract:
Indoor positioning technology is very important in modern intelligent navigation systems, but the accuracy of traditional indoor visible light positioning methods is reduced due to signal occlusion, signal reflection, and environmental noise. In this paper, a visible light localization method based on a convolutional neural network optimized by thermal map is proposed. The discrete fingerprint coordinates are transformed into continuous probability distribution through Gaussian kernel function and trained combined with the characteristics of light intensity, so as to achieve accurate visible light localization. The adaptive federated integrated navigation algorithm is adopted, which combines the autonomous advantages of visible light positioning technology and inertial navigation system. The experimental results show that the average positioning error of the single visible light positioning method based on the thermal map optimization convolutional neural network is 5.8 cm while the average positioning error of the adaptive federated integrated navigation algorithm combined with inertial navigation is reduced to 3.7 cm. The integrated navigation algorithm can effectively overcome the environmental interference of inertial navigation, such as cumulative drift error and visible light signal interruption, and enhance the robustness of the system in complex environments.
More Related Videos
Related Concept Videos
 01:03
Inertial Frames of Reference
 01:30
Introduction to Global Positioning System
 02:16
Light Acquisition
 01:30
Types of Global Positioning System Surveys