Related Experiment Video
Updated: Mar 21, 2026


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
CoShMDM: Contact and Shape-Aware Latent Motion Diffusion Model for Human Interaction Generation

Abstract:
Generating realistic two-person interaction motions from text holds immense potential in computer vision and animations. While existing latent motion diffusion models offer compact and efficient representations, they often fail to produce physically plausible contacts and are typically constrained to a single canonical body shape. As a result, the generated motion sequences exhibit substantial mesh penetrations and lack interaction realism. To address these limitations, we propose a contact and shape-aware latent motion representation and diffusion model (CoShMDM) for generating realistic two-person interactions from text. Our framework begins by constructing contact-compatible motion using SMPL-based meshes and a normal alignment-based mesh contact matrix to capture fine-grained mesh-level contacts. To account for shape diversity, we incorporate SMPL shape parameters and iteratively learn contact dynamics across different body shapes. Additionally, a reinforcement learning-based mesh penetration avoidance policy network, guided by signed distance fields, is introduced to minimize mesh penetrations while preserving contact fidelity and shape-aware motion. We further employ a dual-encoder VQ-VAE to learn disentangled latent representations for motion and contacts, which are then utilized in a text- and body-shape-conditioned diffusion model. To ensure spatial, temporal, and semantic coherence, we integrate a novel contact and motion consistency module into the diffusion transformer. Extensive evaluations on the InterHuman and InterX datasets demonstrate that our method outperforms state-of-the-art approaches achieving lowest FID scores (4.801 and 0.013), with 19% and 17.3% reductions in mesh penetrations, and 17.8% and 33.2% gains in contact similarity, respectively.


Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:27
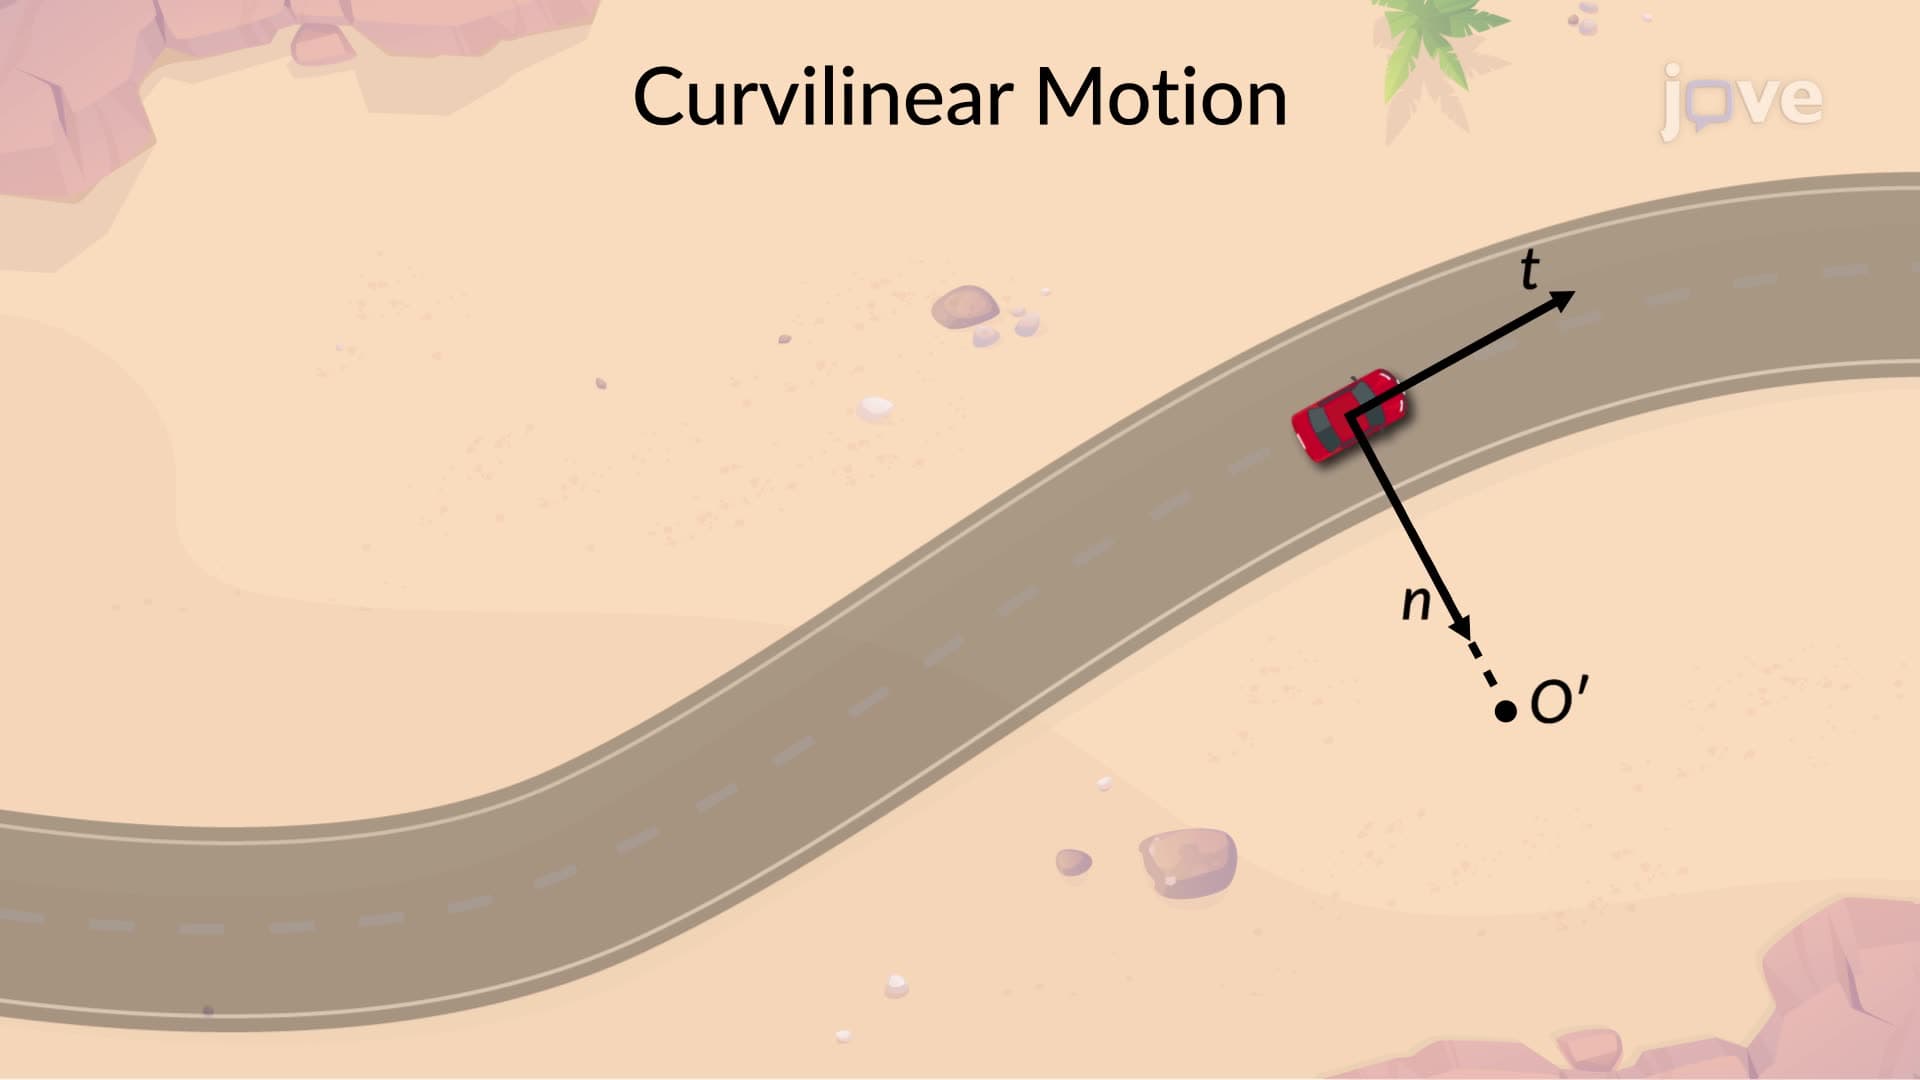
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:12
Modeling and Similitude