Related Experiment Video
Updated: Mar 21, 2026

A Simple Non-invasive Method for Temporary Knockdown of Upper Limb Proprioception
Published on: March 3, 2018
Robotic assessment of proprioception in individuals with patellar tendinopathy: A feasibility and pilot study
Elena Muñoz-Gómez1, Héctor González-Pons1, Marta Inglés1
1Department of Physiotherapy, Faculty of Physiotherapy, Research Unit in Clinical Biomechanics (UBIC), University of Valencia, Valencia, Spain.

Background:
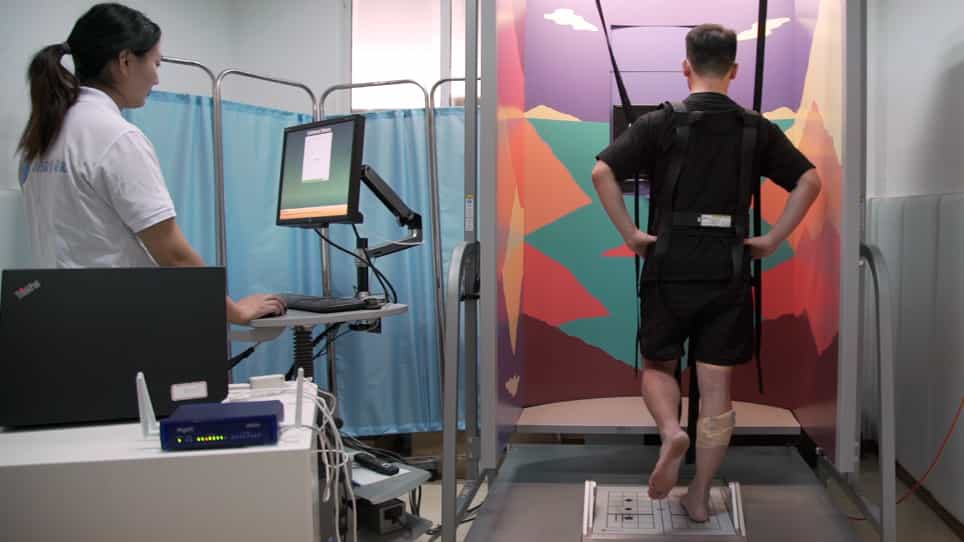
Individuals with patellar tendinopathy often exhibit impaired proprioception, which may contribute to symptom persistence and injury recurrence. A parallel robotic system based on a musculoskeletal knee model has shown valid and reliable performance for assessing joint position sense (JPS). This study aims to evaluate the feasibility of a protocol for the robotic assessment of knee proprioception in individuals with patellar tendinopathy and to compare their proprioceptive performance with that of healthy controls.
Methods:
Twenty-one participants with patellar tendinopathy (PTG) and fifteen healthy individuals (CG) (mean age: 32.36 (9.53) years) completed a single session of knee proprioception evaluation. JPS was assessed at 30° and 50° using passive (PJPS) and active (AJPS) repositioning tasks.
Findings:
The PTG exhibited greater absolute angular error than the CG during PJPS at 30° (p = 0.04) and 50° (p = 0.04), and during AJPS at 30° (p = 0.01), with no differences detected in the 50° AJPS task (p > 0.05). The feasibility analysis showed that perceived effort, difficulty, and pain were generally low, whereas comfort and satisfaction were rated highly.
Interpretation:
This study supports the use of a parallel robotic system as a viable instrument for assessing knee proprioception in people with patellar tendinopathy. Significant proprioceptive deficits were identified in this population compared to healthy controls, particularly in passive JPS at 30° and 50°, and in active JPS at 30°.