
Life-like behavior emerging in active and flexible microstructures
Mengshi Wei1, Daniela J Kraft1
1Leiden Institute of Physics, Huygens-Kamerlingh Onnes Laboratory, Leiden University, Leiden 2300 RA, The Netherlands.

Abstract:
Many organisms leverage an interplay between shape and activity to generate motion and adapt to their environment. Embedding such mechanical feedback into synthetic micrometer-sized robots could eliminate the need for sensors, software, and actuators. Current active micrometer-scale systems, however, do not possess a flexible body with which they can autonomously sense and react to their environment. Here, we experimentally realize active and flexible structures by concatenating anisotropic micrometer-sized units using 3D microprinting and activating them using AC fields. We demonstrate that this minimal design integrates mechanical feedback between activity and shape, resulting in a rich array of modes of motion-including railway and undulatory locomotion, rotation, and beating. It furthermore gives rise to emergent sense-response abilities, which enable autonomous reorientation, navigation, and collision avoidance. Our approach offers a versatile platform for designing biomimetic model systems and autonomously operating microrobots with embodied intelligence.
Related Concept Videos
 01:13
Actin Polymerization and Cell Motility
Actin cytoskeleton dynamics can produce pushing, pulling, and resistance forces that help the cell to migrate....
 01:17
Studying the Cytoskeleton
 01:15
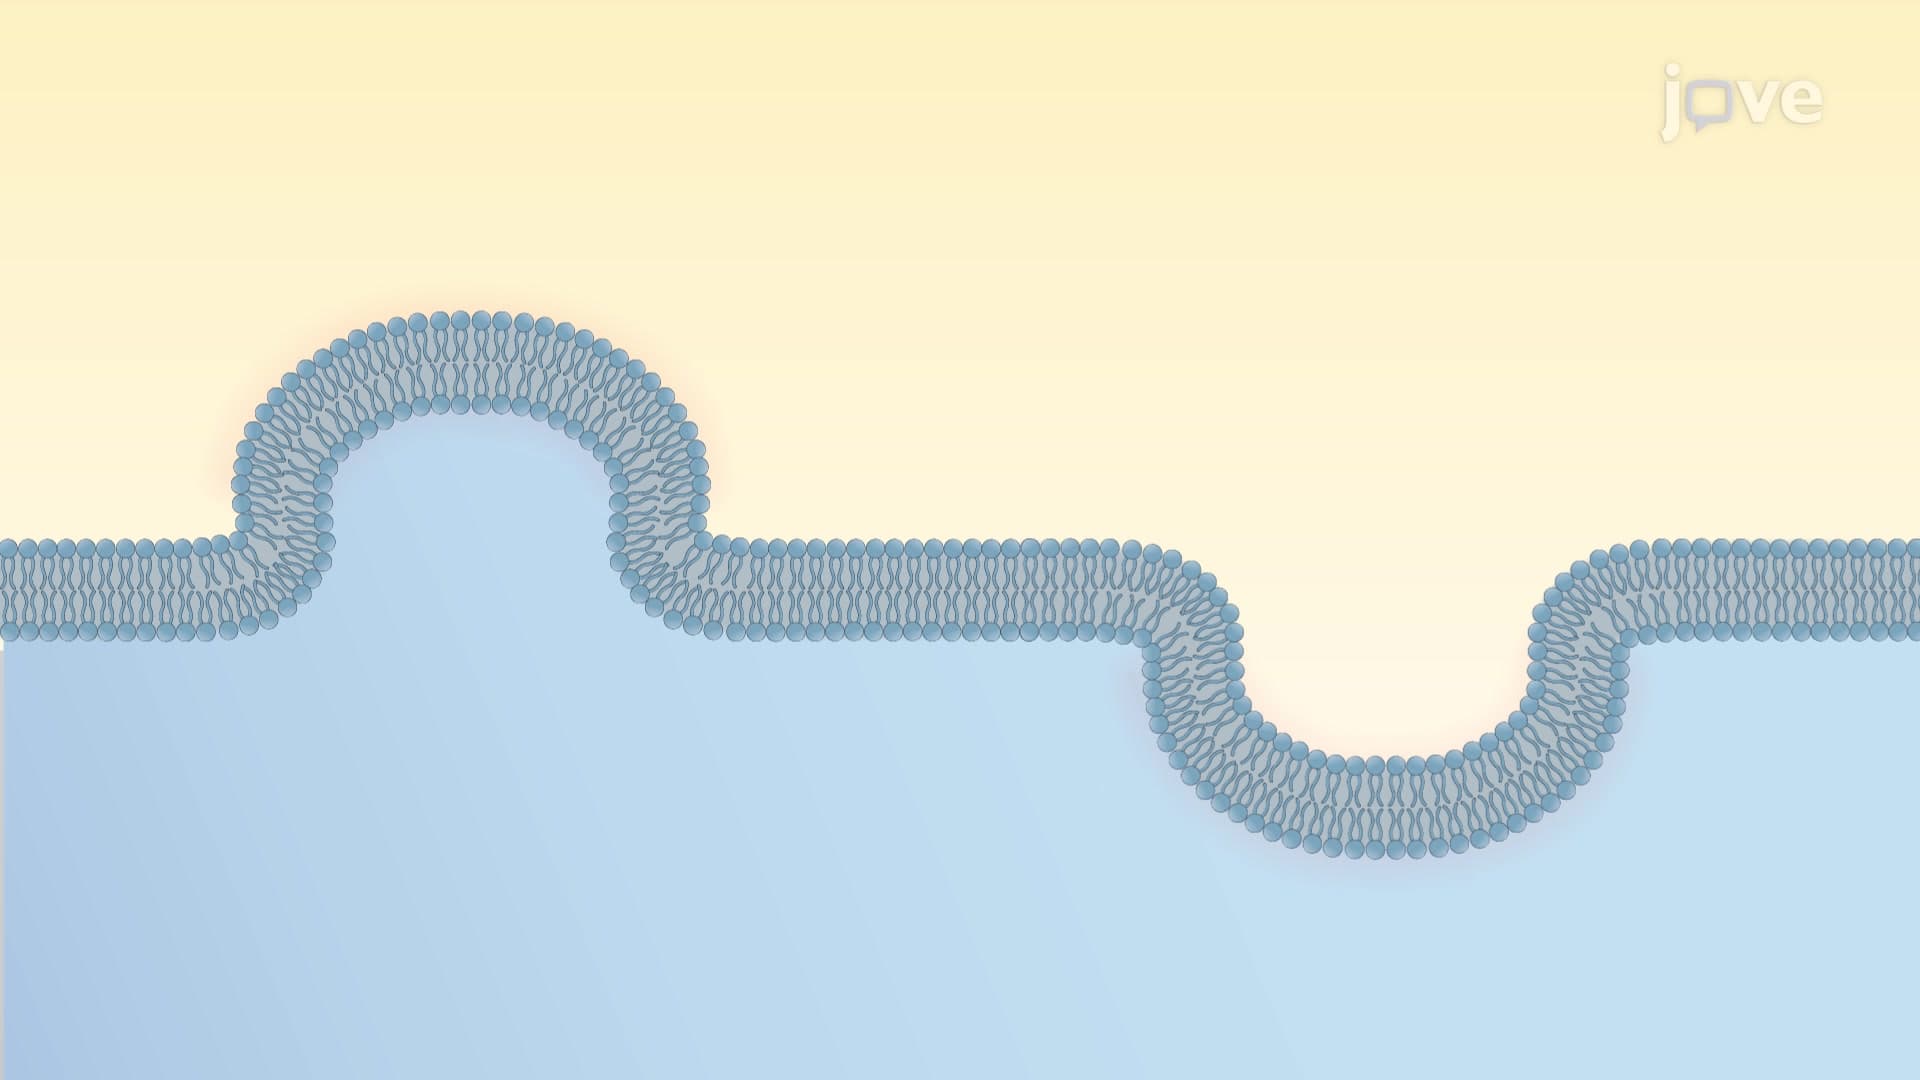
Mechanisms of Membrane-bending
Membrane bending can happen due to intrinsic changes in lipid composition or extrinsic association with different proteins. The proteins involved...
 01:31
Mechanism of Lamellipodia Formation
 01:39
Mechanism of Filopodia Formation
Their main function is to guide migrating cells during normal tissue morphogenesis or cancer metastasis by recognizing and making initial contacts with the extracellular matrix. However, they can also act as stationary cell anchors or help to establish communication...