

Optimization of the Spatial Position of the Vibration Acceleration Sensor and the Method of Determining Limit Values
Jan Monieta1, Lech Władysław Kasyk1
1Maritime University of Szczecin, 70-500 Szczecin, Poland.

Abstract:
A new procedure for diagnosing damage to the fuel injection system of marine engines, along with vibration acceleration signal symptoms, is explored with a related built, developed, and tested measuring system. This work fills an important gap given the current lack of a scientific solution to this problem. A vibration acceleration signal sensor, mounted on a holder elaborated on by the authors, is positioned on the injection pipe between the injection pump and the injector. The output signals from the sensor are sent to an acquisition and analysis system, which is used for processing the signals in the time, amplitude, frequency, and time-frequency domains. Experimental choices, using multiple parameters for a given signal analysis field, are based on the location of the optimal sensor, the direction of the sensor mounting, and the selection of a cumulative diagnostic symptom. The vibration acceleration signals recorded along the injection pipe are found to have the strongest magnitude. This article compares diagnostic values from these signals with previously determined upper and lower limits. As a result, the tested fuel injection system is classified as either able or disabled, using unparalleled tolerance ranges given for both the upper and lower limits. The values of the limits are determined based on the average value for an ability state plus or minus three times the standard error of this mean, which has not been reported in the literature previously. Multiple regression models are developed that relate identified symptoms to the state features of the fuel injection system. In addition, artificial neural networks and machine learning are used to detect developing damage. The probability of correctly classifying the states of the diagnostic parameters is 0.467, alongside a diagnostic accuracy of ≤±4%, with the network correctly classifying the state when the testing accuracy is at least 70.0%.
Related Concept Videos
 01:27
Otto and Diesel Cycle
 01:20
Internal Combustion Engine
 01:19
Root-Locus Method
This system can be represented by a block...
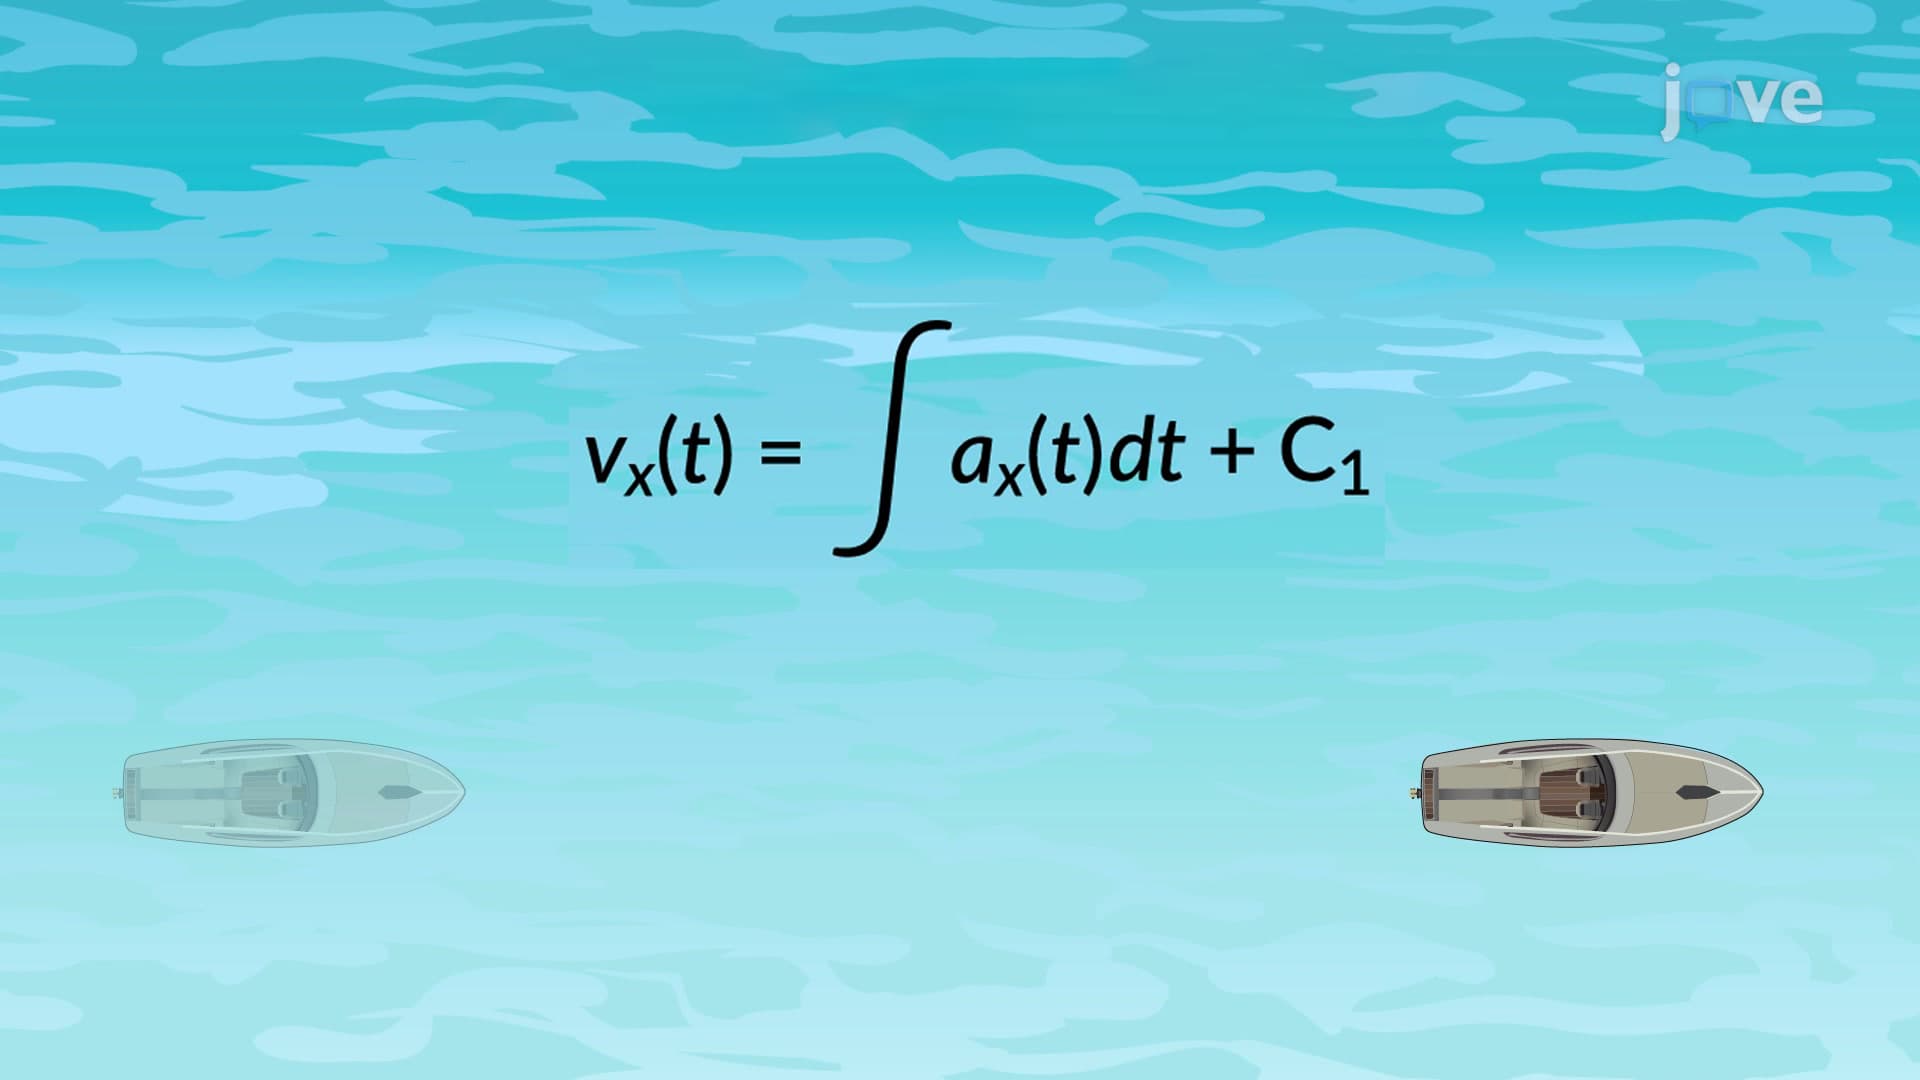 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:19
Turnover Number and Catalytic Efficiency
Chymotrypsin is a pancreatic enzyme that breaks down proteins during digestion....
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...