Related Experiment Video
Updated: Jul 7, 2026
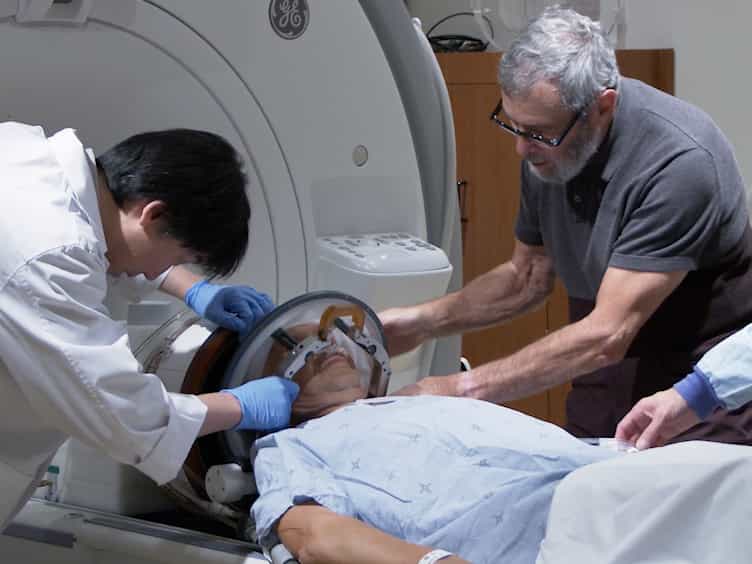

MRI-guided Focused Ultrasound Thalamotomy for Patients with Medically-refractory Essential Tremor
Published on: December 13, 2017
A Tremor Suppression Method for the Master-Follower Surgical Robot Manipulator Based on Kalman Filter Algorithm
Tanjing Zhang1,2, Congyu Sun1,3, Xianzheng Zhou1,4
1Key Laboratory of High Efficiency and Clean Mechanical Manufacture (Ministry of Education), School of Mechanical Engineering, Shandong University, Jinan, China.

Background:
Master follower surgical robotic systems are widely used in invasive procedures but remain vulnerable to end effector tremor transmitted from the operator's physiological tremor, reducing precision.
Methods:
Physiological tremor was characterised with a three-dimensional optical motion capture system and integrated into master follower control strategy enhanced with Kalman filter based tremor suppression algorithm. The method was validated on a custom platform using 24 predefined motion trajectories executed via a force feedback haptic master and robotic slave manipulator.
Results:
Physiological tremor exhibited amplitudes that did not exceed 1 mm and dominant frequencies within 5-15 Hz. Across all 24 motion sets, suppression significantly reduced in majority of cases standard deviations of end-effector velocity and acceleration and removed high-frequency components while preserving smooth motion.
Conclusions:
The Kalman filter based master follower tremor suppression strategy provides accurate and effective attenuation of physiological tremors, enhancing the precision, stability and operational safety of surgical robotic manipulation.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 05:57
A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
