Related Experiment Video
Updated: Apr 7, 2026
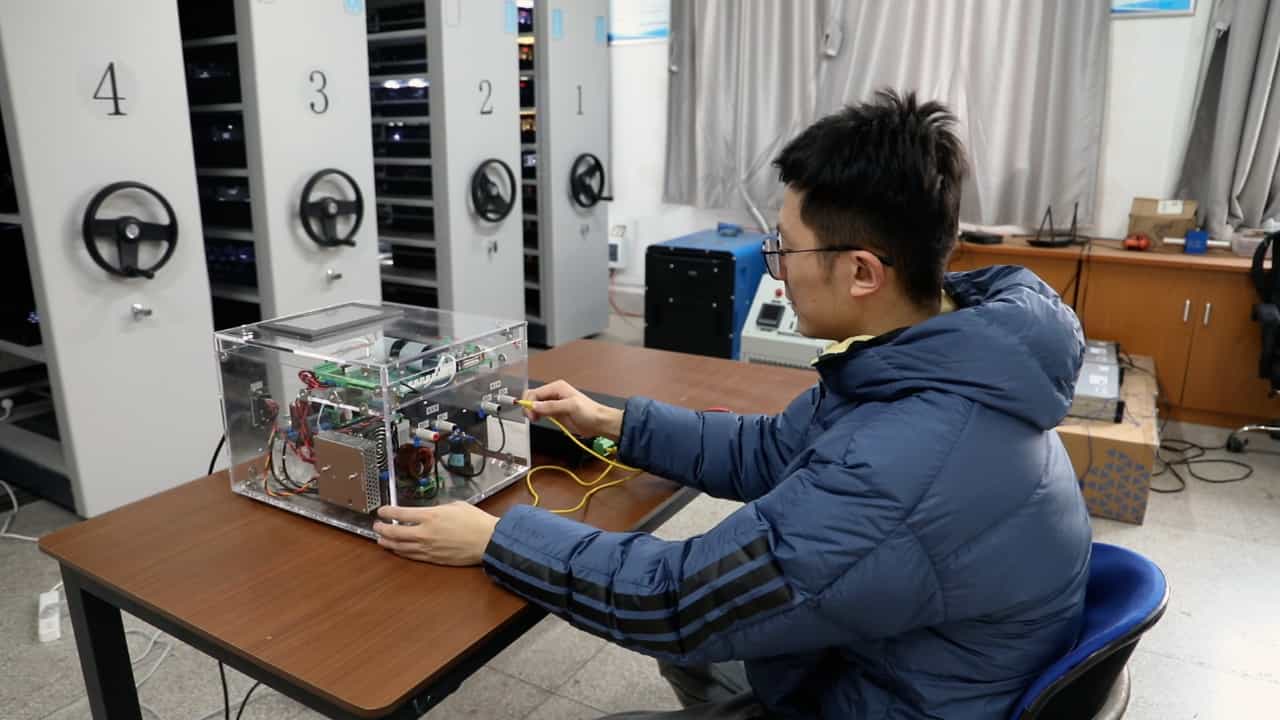

Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
Enhanced imitation learning of robust nonlinear model predictive control via temporal convolutional neural network
Xiaoyu Ge1, Saskia Putri2, Faegheh Moazeni2
1Electrical and Computer Engineering, Lehigh University, Bethlehem, United States.

Abstract:
Compared with land based systems, direct current shipboard microgrids pose greater control challenges due to the integration of hybrid energy sources required to meet the evolving demands of future loads, introducing increased system complexity and potential instability in the absence of grid support. In this work, an enhanced temporal convolutional neural network is developed to approximate the control policy of a robust nonlinear model predictive control framework. A formal Lyapunov-based stability analysis of the learning-based controller shows that it exhibits input-to-state stability under bounded disturbances, ensuring reliable voltage stabilization. The initialization of the proposed model is optimized via mean-field analysis at each neural network layer, yielding bounded and stable parameters. The proposed temporal convolutional neural network controller exhibits excellent accuracy and strong generalization, achieving an R2 score near unity, a mean squared error of 0.07, and a fast inference time of 10 ms, making it suitable for real-time deployment. In a controller-hardware-in-the-loop test, the temporal convolutional neural network controller achieved rapid voltage restoration post-disturbance within 22.4 ms with reduced overshoot to 1.67%. Extensive control comparison with a state-of-the-art controller demonstrates that the proposed controller reduces overshoot by 62% and achieves a 53.25% faster voltage settling time.

Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
Fast Decoupled and DC Powerflow
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:23
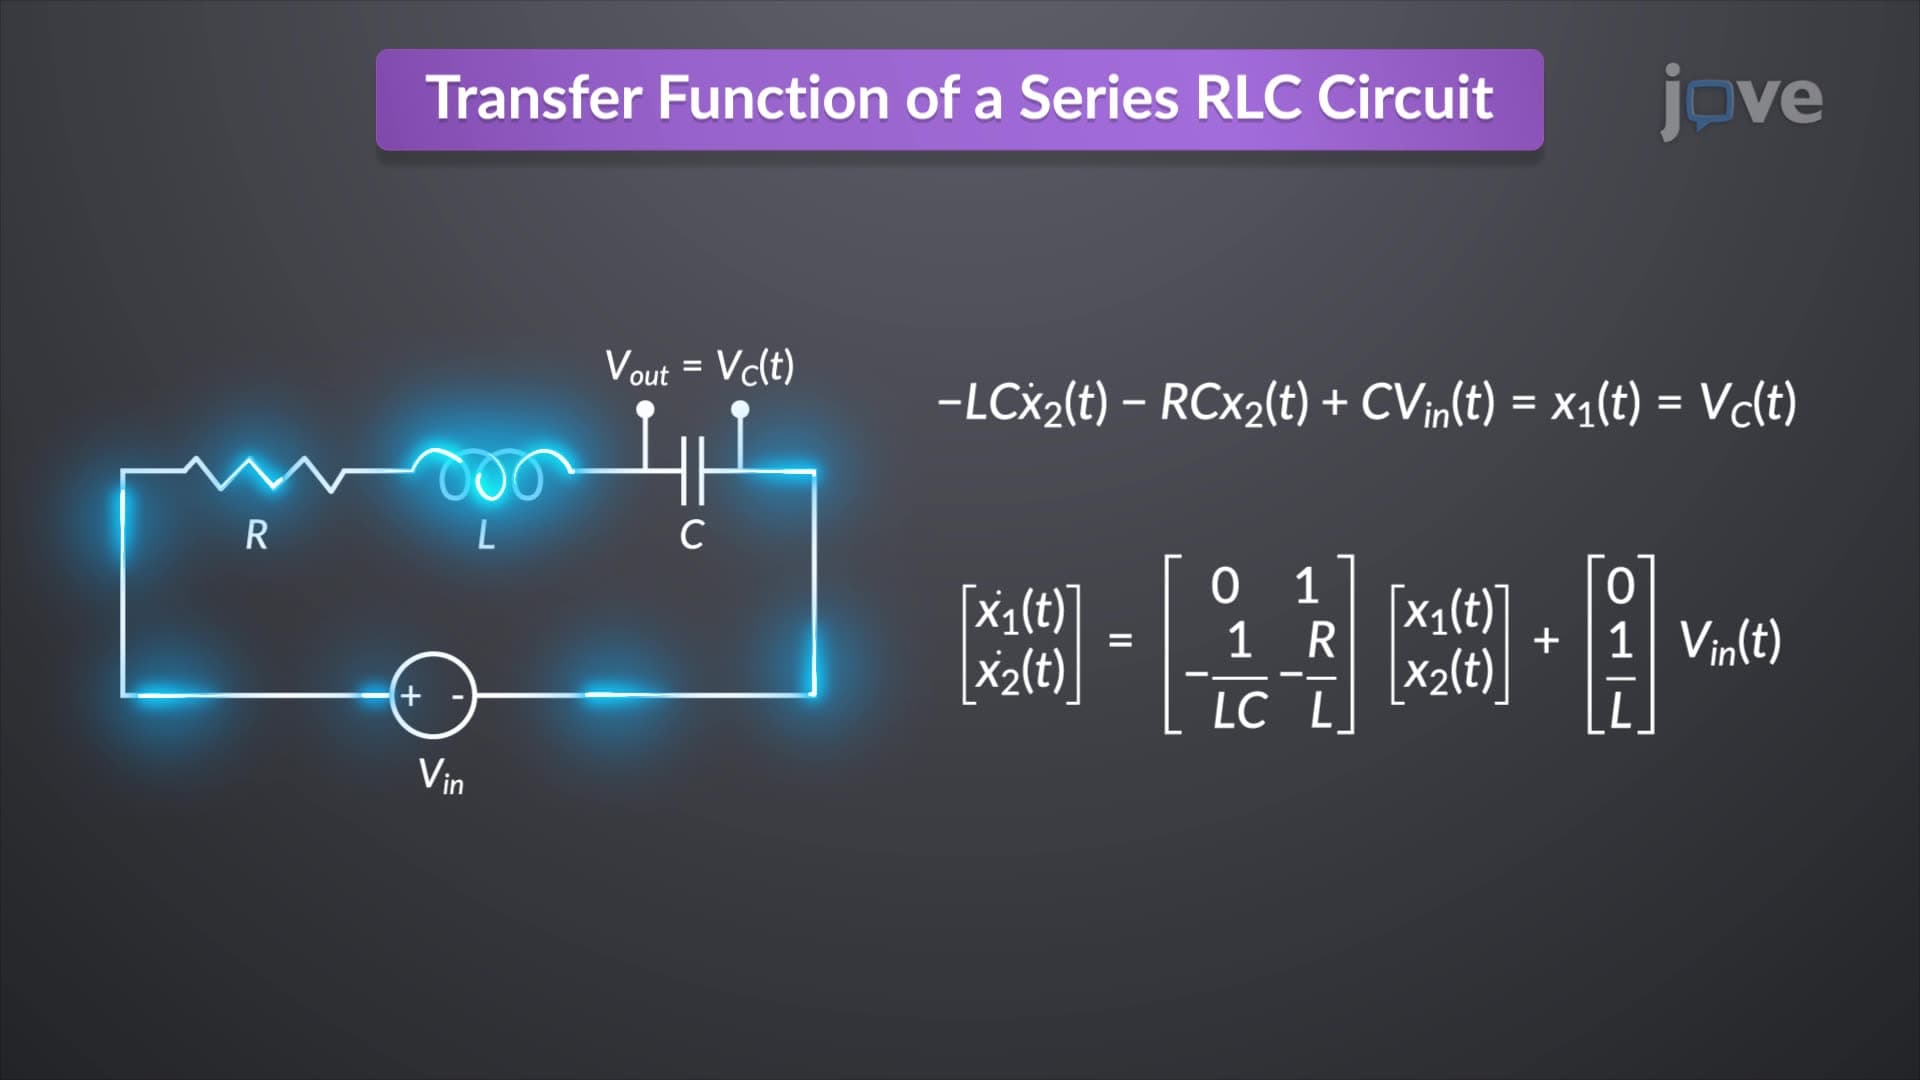
Transfer Function to State Space
In an RLC...
 01:21
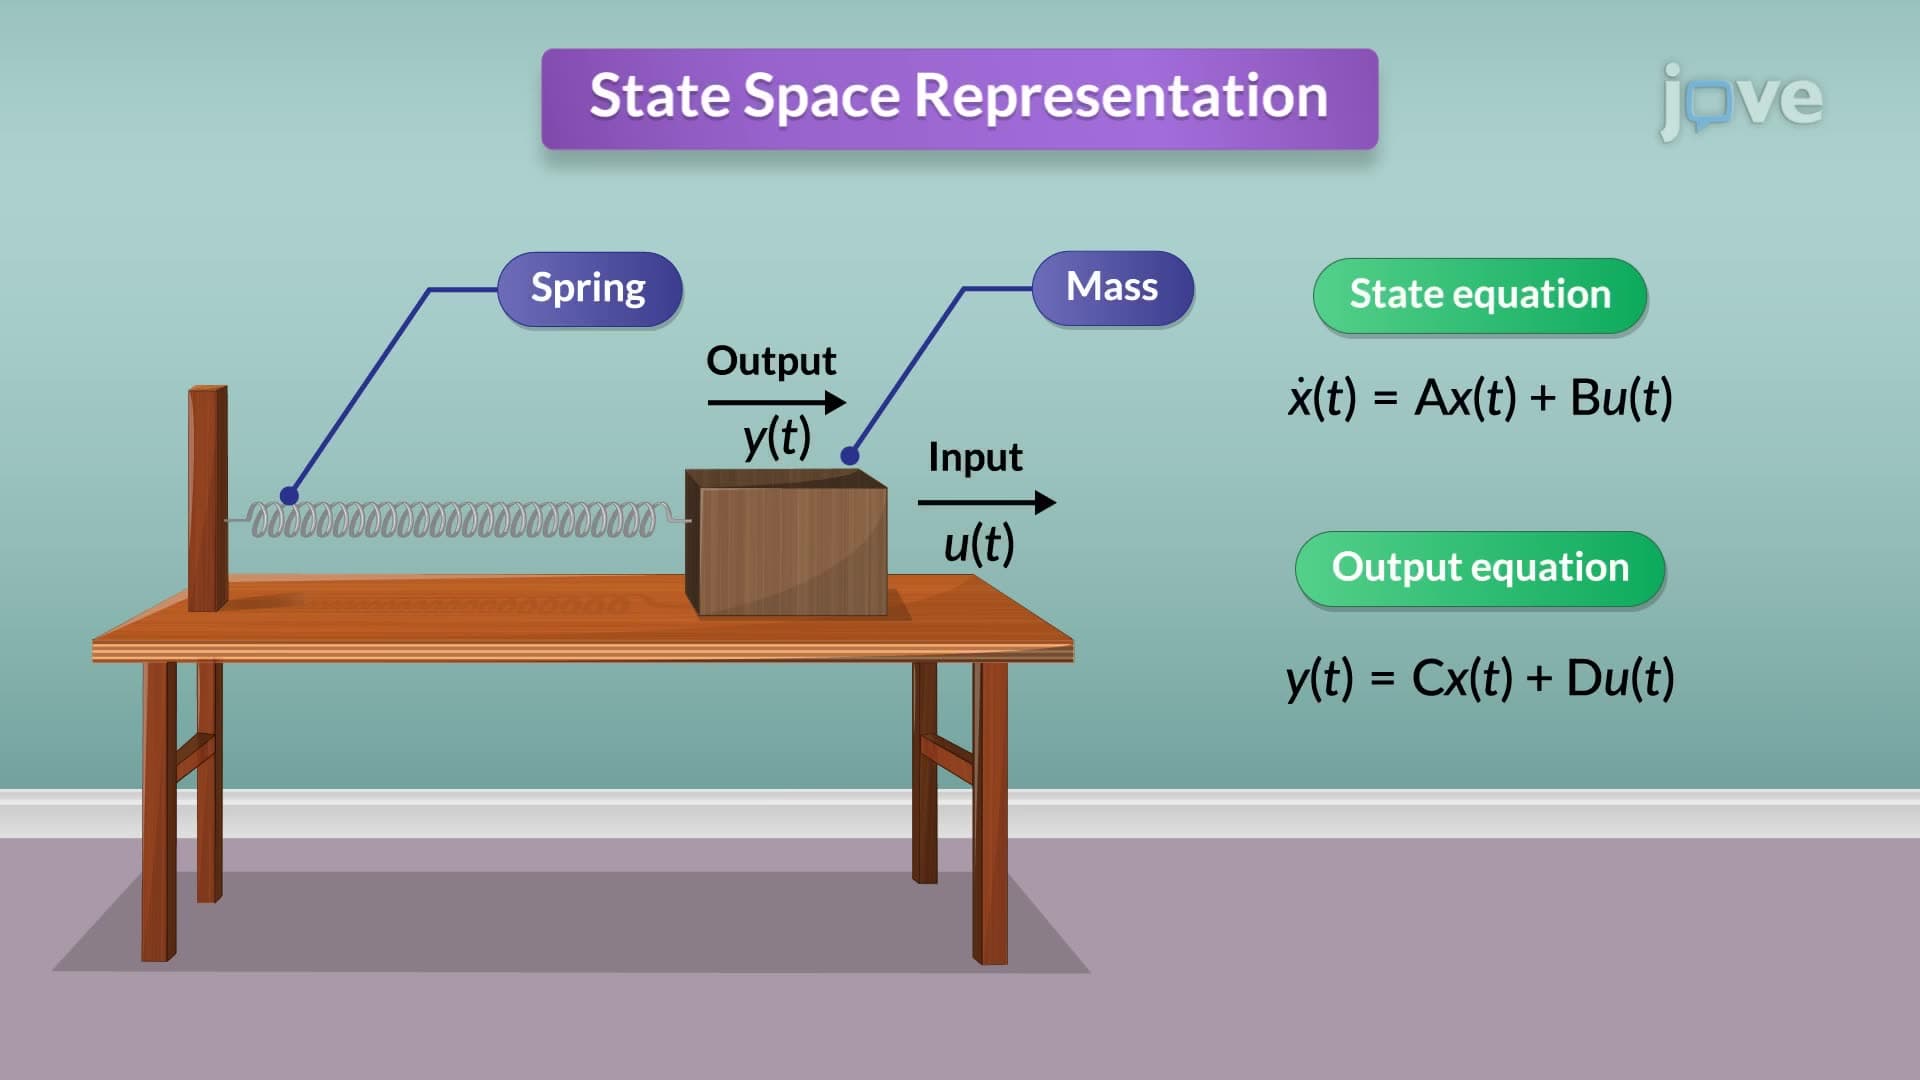
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:12
Observational Learning