Related Experiment Video
Updated: Jul 28, 2026

Image Recognition and Parameter Analysis of Concrete Vibration State Based on Support Vector Machine
Published on: January 5, 2024
Physics-guided contrastive temporal graph learning for anomaly detection and root-cause localization in industrial
1School of Electronics Engineering, Vellore Institute of Technology, Vellore, Tamilnadu, India.

Abstract:
Industrial control systems generate complex multivariate time series and detecting anomalies without labelled attacks is still difficult. In this work we propose a physics guided contrastive temporal graph learning framework for anomaly detection and root-cause localization in ICS. The method follows three main steps. First, a self-supervised contrastive encoder is trained only on normal data to learn robust representations of sensor windows. Augmented views of the same signal are used so that normal behaviour is pulled together in latent space. Second, a physics guided graph is built from the plant P&ID where sensors and actuators are nodes and physical dependencies form edges. Third, a temporal graph module operates on the learned embeddings to capture both time evolution and cross-sensor relations. Anomaly score is computed from graph representations and node level scores are used to rank possible root causes. Experiments on ICS dataset show higher detection performance than LSTM-AE and CNN-AE baselines. Additional robustness tests such as distribution shift, sensor drift and missing channels are conducted to study practical behaviour. The main innovation of this work is the combination of contrastive learning with physics guided graph reasoning without using any attack labels, and the ability to provide interpretable sensor ranking for operators.
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:19
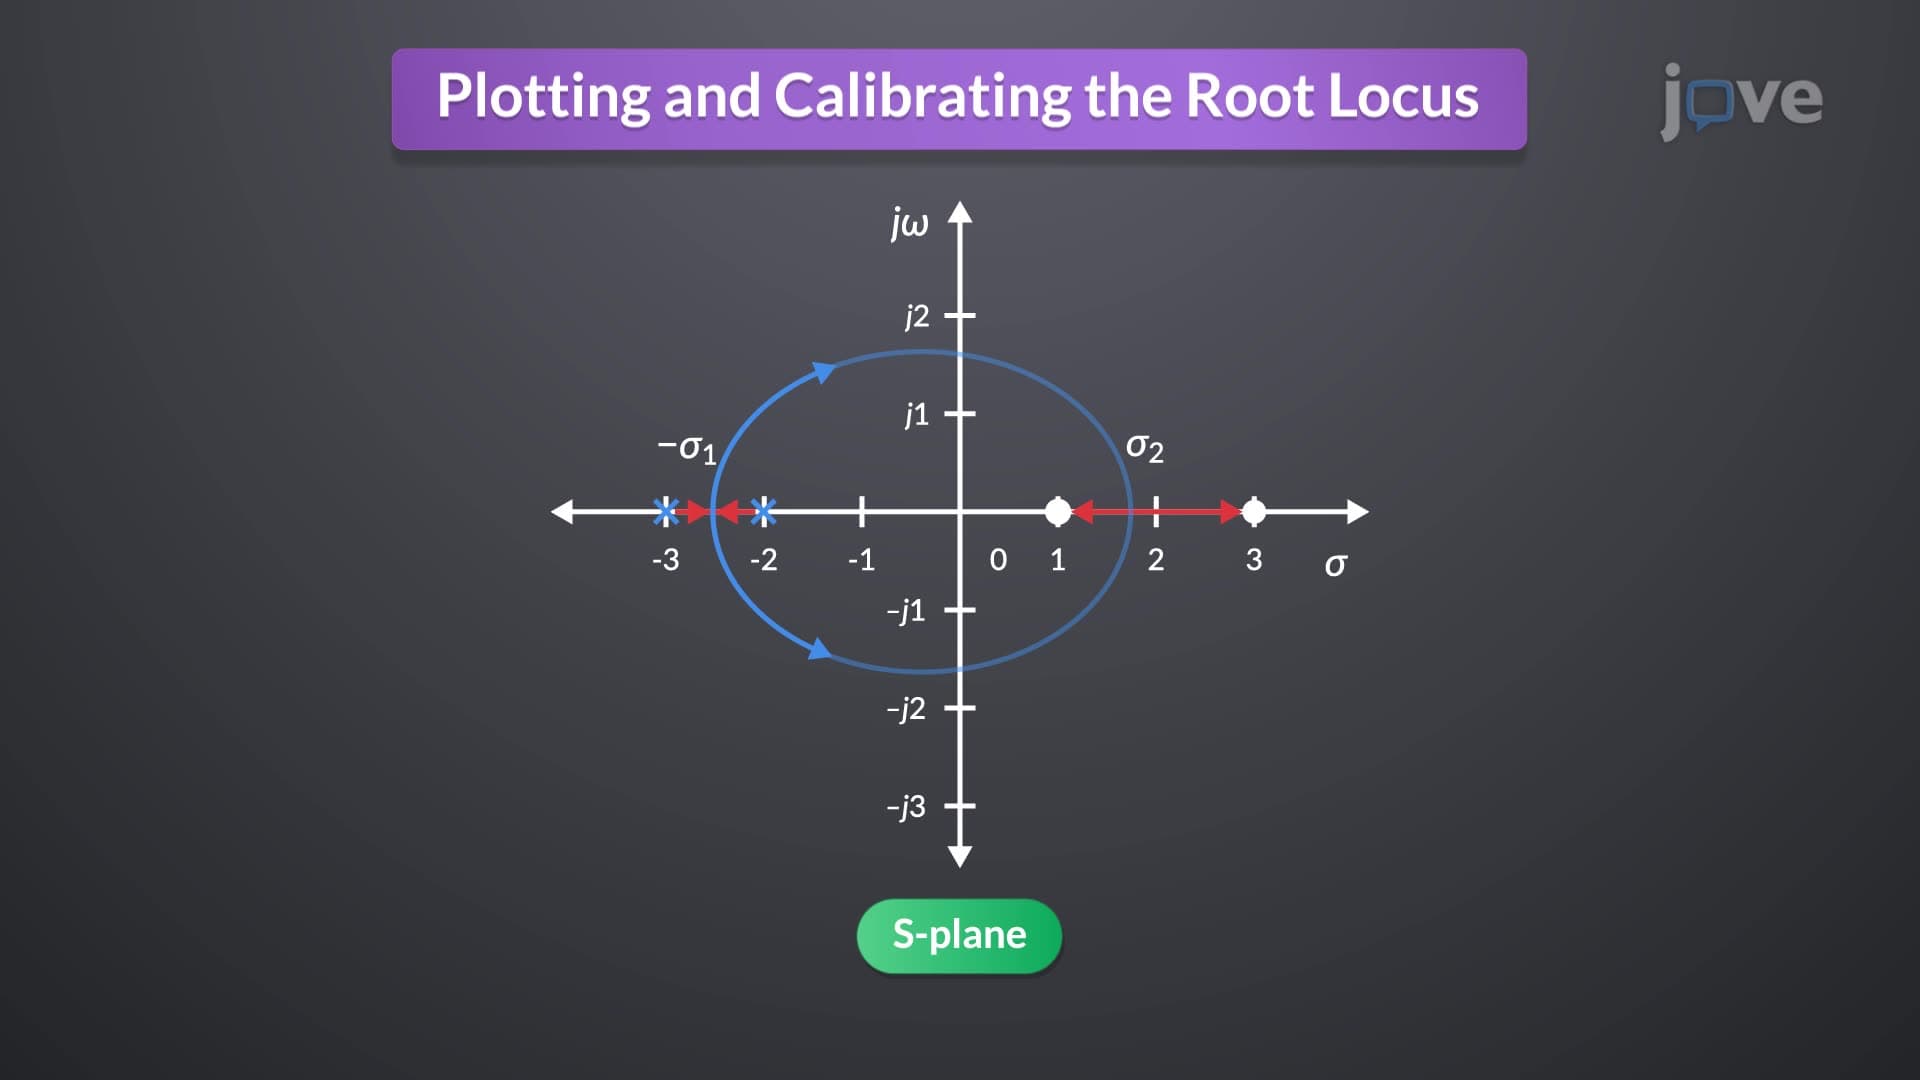
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...