Related Experiment Video
Updated: Jul 12, 2026

Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
U-NEXT: A User-Centered New Prototype for Walking Excavator Simulator

Abstract:
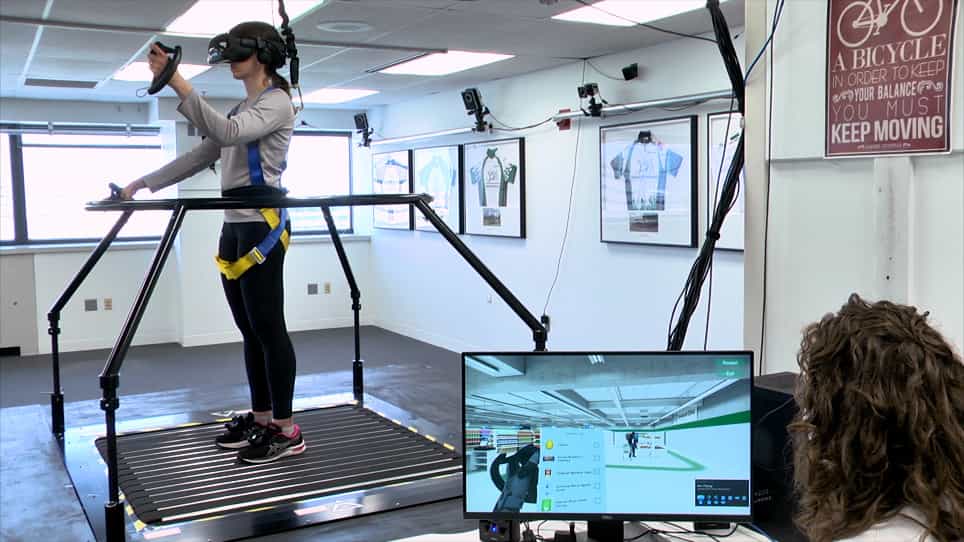
The walking excavator is a highly complex construction machine, characterized by challenges in control, instruction, and operational safety. In this work, we implemented a virtual reality (VR) walking excavator simulator that integrates real hardware components with kinematic physics simulation. Using the simulator, we conducted two user studies. The first involved 45 participants and examined the effects of user perspectives on performance and preference. The second involved 12 participants and investigated the influence of video passthrough of the controllers. Results show that the choice of perspective should be task-dependent. Third-person view outperformed first-person view in the undercarriage task in which complex leg movements are needed. It supported better planning and allowed complete body visualization. However, it did not reduce motion sickness and was less preferred than first-person view for training. From the second user study, passthrough significantly improved controller learning compared to animated controllers, with participants making fewer errors when using the passthrough design. Based on these findings, we provide design recommendations for user perspectives and controller representation in VR-based training simulators.
Related Concept Videos
 01:16
Hydraulic Jump: Problem Solving
 01:24
Concepts and Prototypes
The brain organizes this information using concepts, which are mental categories grouping linguistic data,...