Related Experiment Video
Updated: Apr 14, 2026

Evaluating the Effect of Roadside Parking on a Dual-Direction Urban Street
Published on: January 20, 2023
High-performance collision avoidance parallel parking strategy of the autonomous vehicle
Guofeng Wang1, Xu Zhao1, Chenming Li1
1Shandong University of Science and Technology, Qingdao 266590, China.

Abstract:
A parallel parking strategy of the uncertain autonomous vehicle is presented. In the actual driving environment, due to the influence of unpredictable factors such as uneven road surface and climate change, there is uncertainty in the process of parallel parking of the autonomous vehicle. The uncertainty which may change with time is bounded, yet the bound is unknown. In order to achieve accurate parallel parking and collision avoidance of the autonomous vehicle, the uncertainty analysis is added into the autonomous vehicle system. Firstly, the dynamic model of the uncertain autonomous vehicle is determined based on the hierarchical constraint approach, and the analytical form of the dynamic model is obtained. Then, a self-regulating leakage type adaptive robust control based on the Udwadia-Kalaba method is proposed. Finally, the applicability and superiority of the parking strategy are demonstrated by comparing with other control methods.

Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:20
Parallel Processing
 01:17
Rolling Resistance: Problem Solving
 01:15
Elastic Collisions: Case Study
 01:12
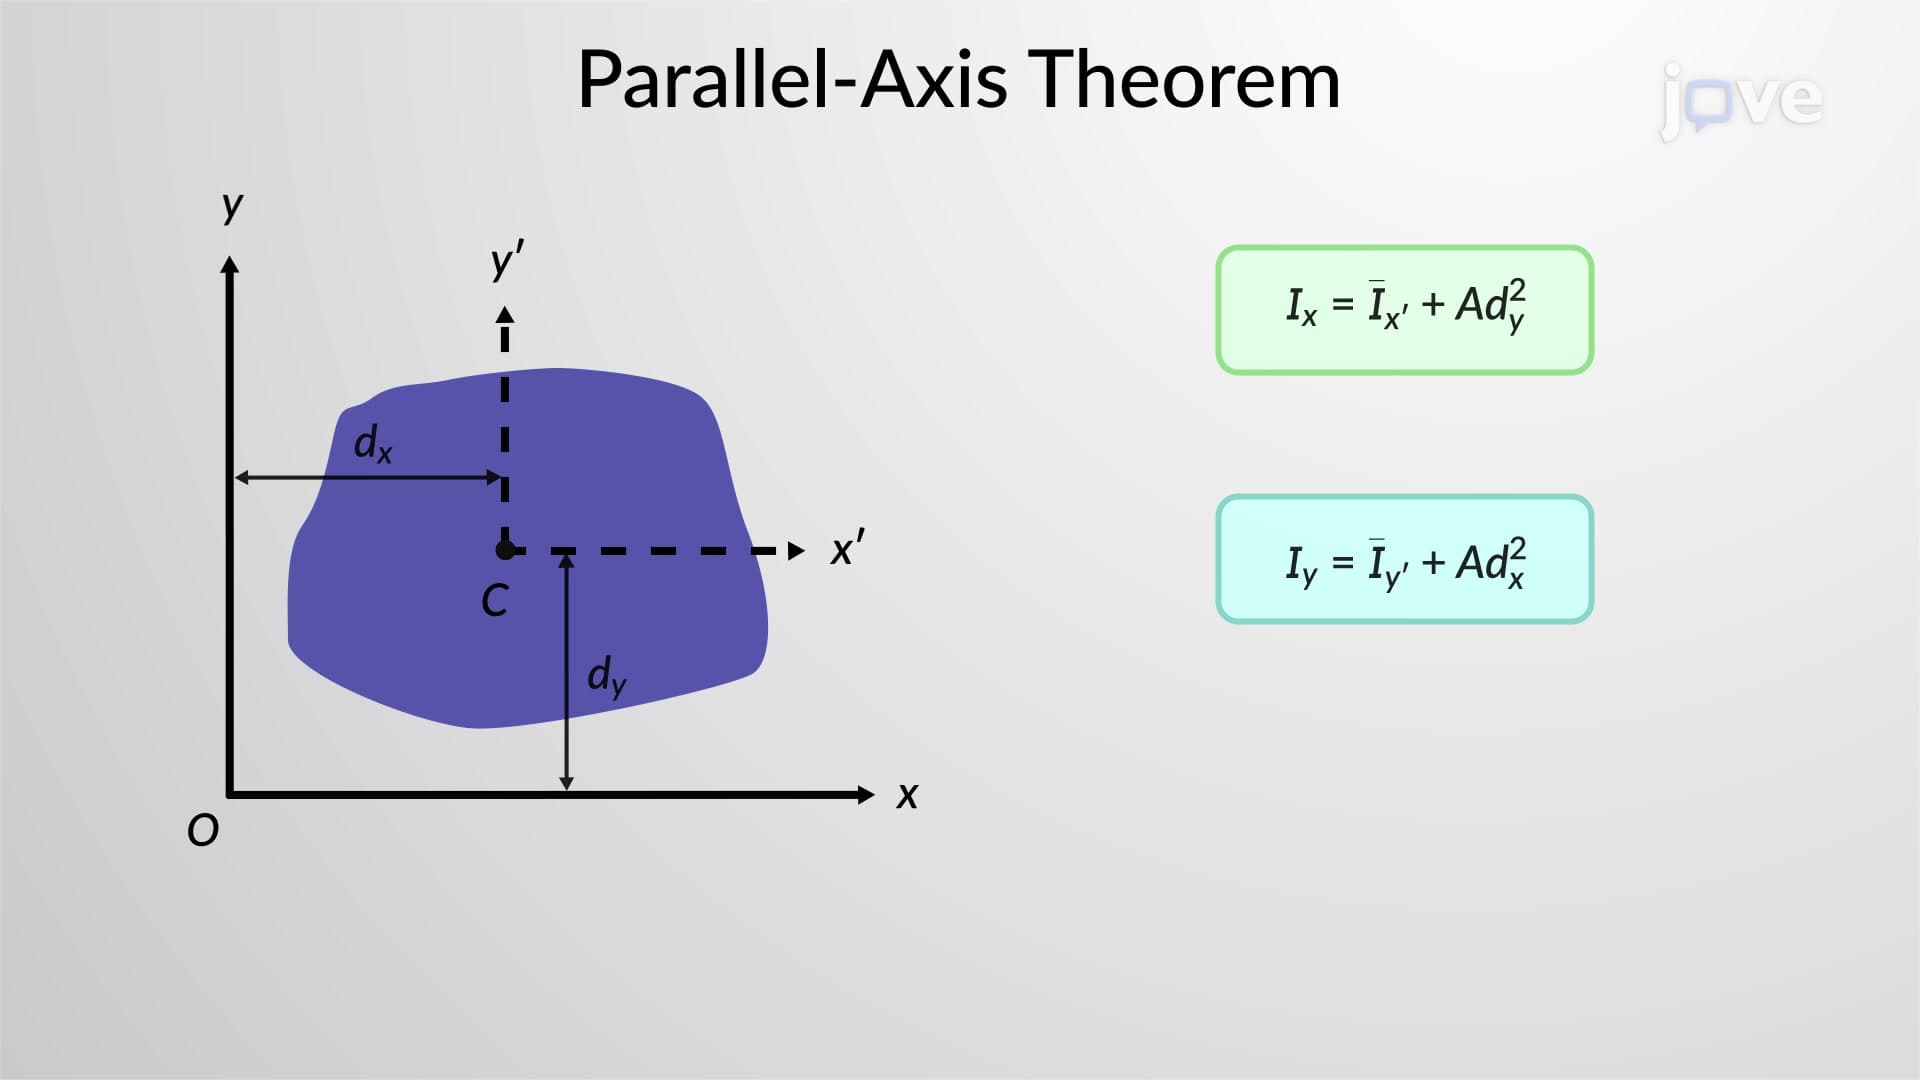
Parallel-Axis Theorem for an Area
For a flywheel approximated as a solid disc, consider an infinitesimal differential element with an arbitrary distance...
 01:05
Collisions in Multiple Dimensions: Introduction