Related Experiment Video
Updated: Apr 25, 2026
06:04

Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
1.1K
Corrigendum to "Enhanced imitation learning of robust nonlinear model predictive control via temporal convolutional
Xiaoyu Ge1, Saskia Putri2, Faegheh Moazeni2
1Electrical and Computer Engineering, Lehigh University, USA.
ISA Transactions
|April 23, 2026

Abstract
No abstract available in PubMed .


Related Concept Videos
 01:17
Open and closed-loop control systems
1.9K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.9K
 01:26
Feedback control systems
793
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
793
 01:21
Transfer Function in Control Systems
2.0K
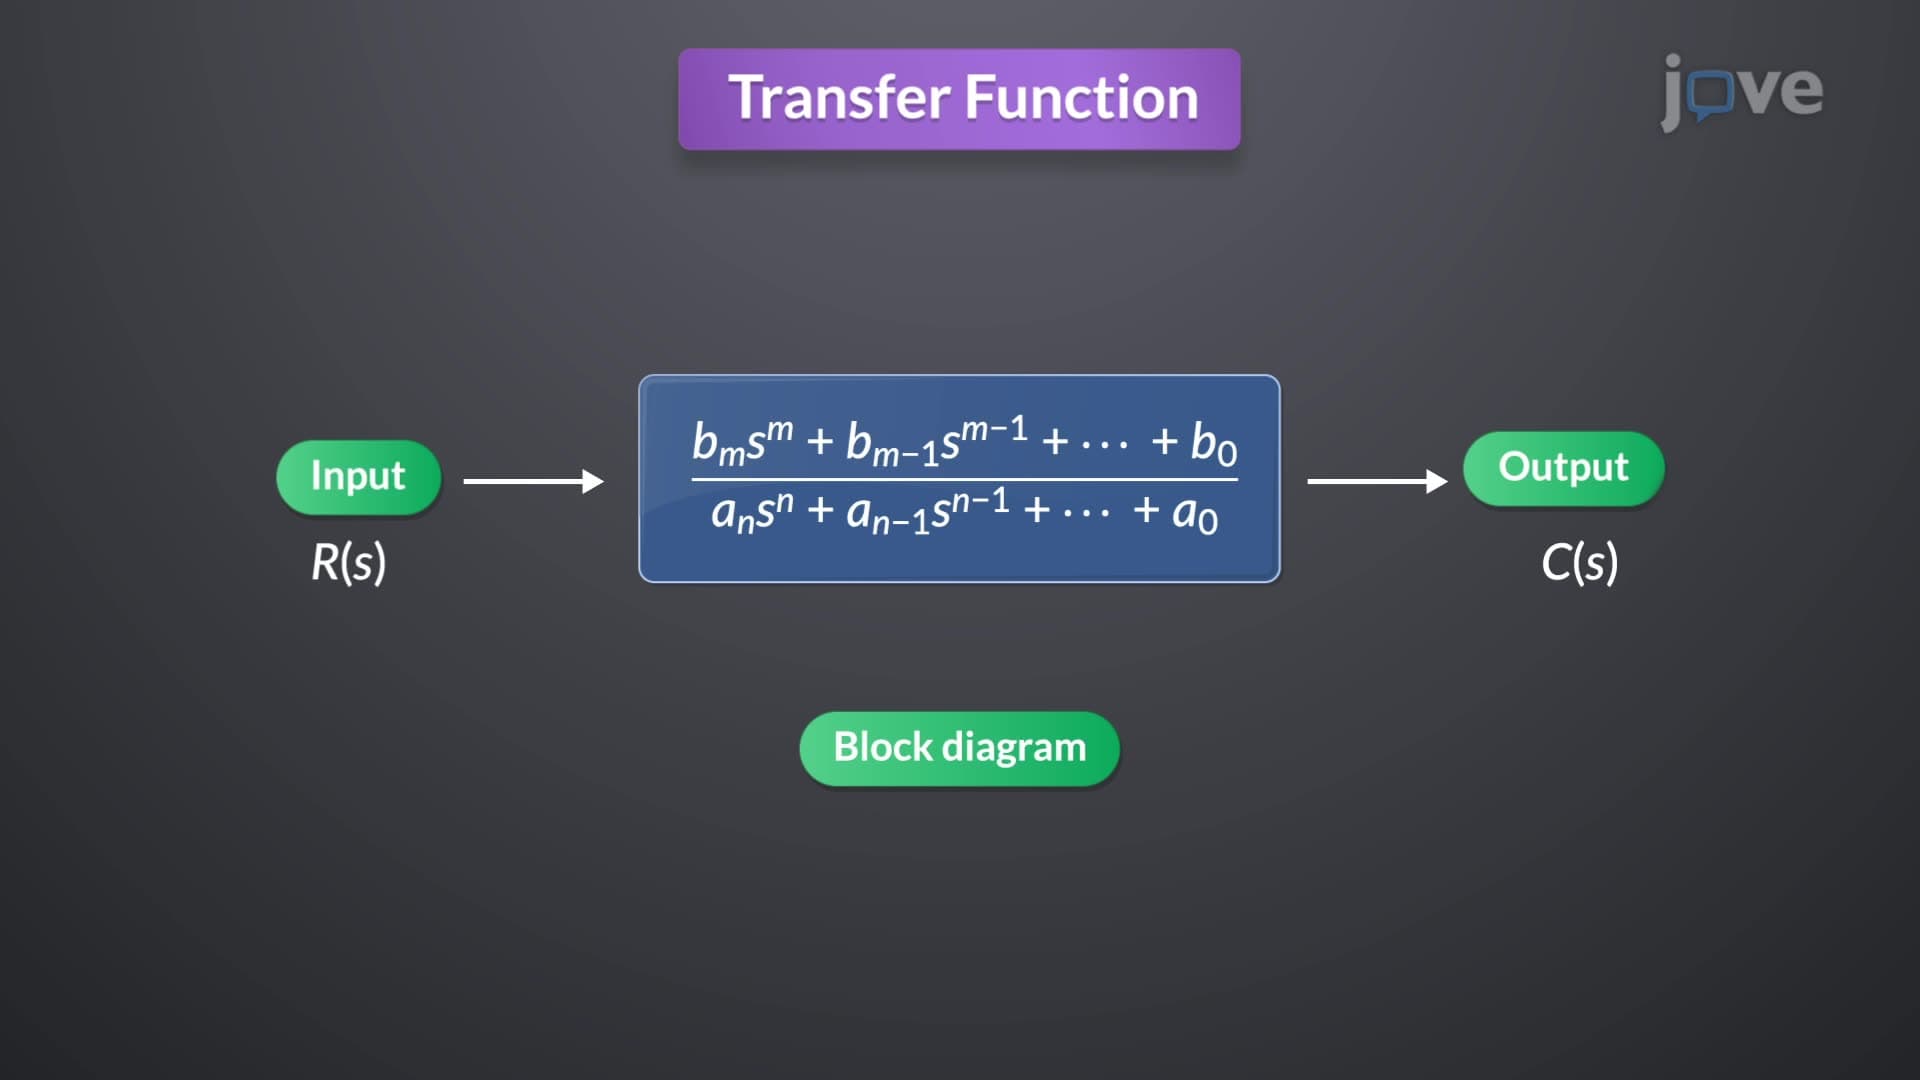
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
2.0K
 01:23
Transfer Function to State Space
980
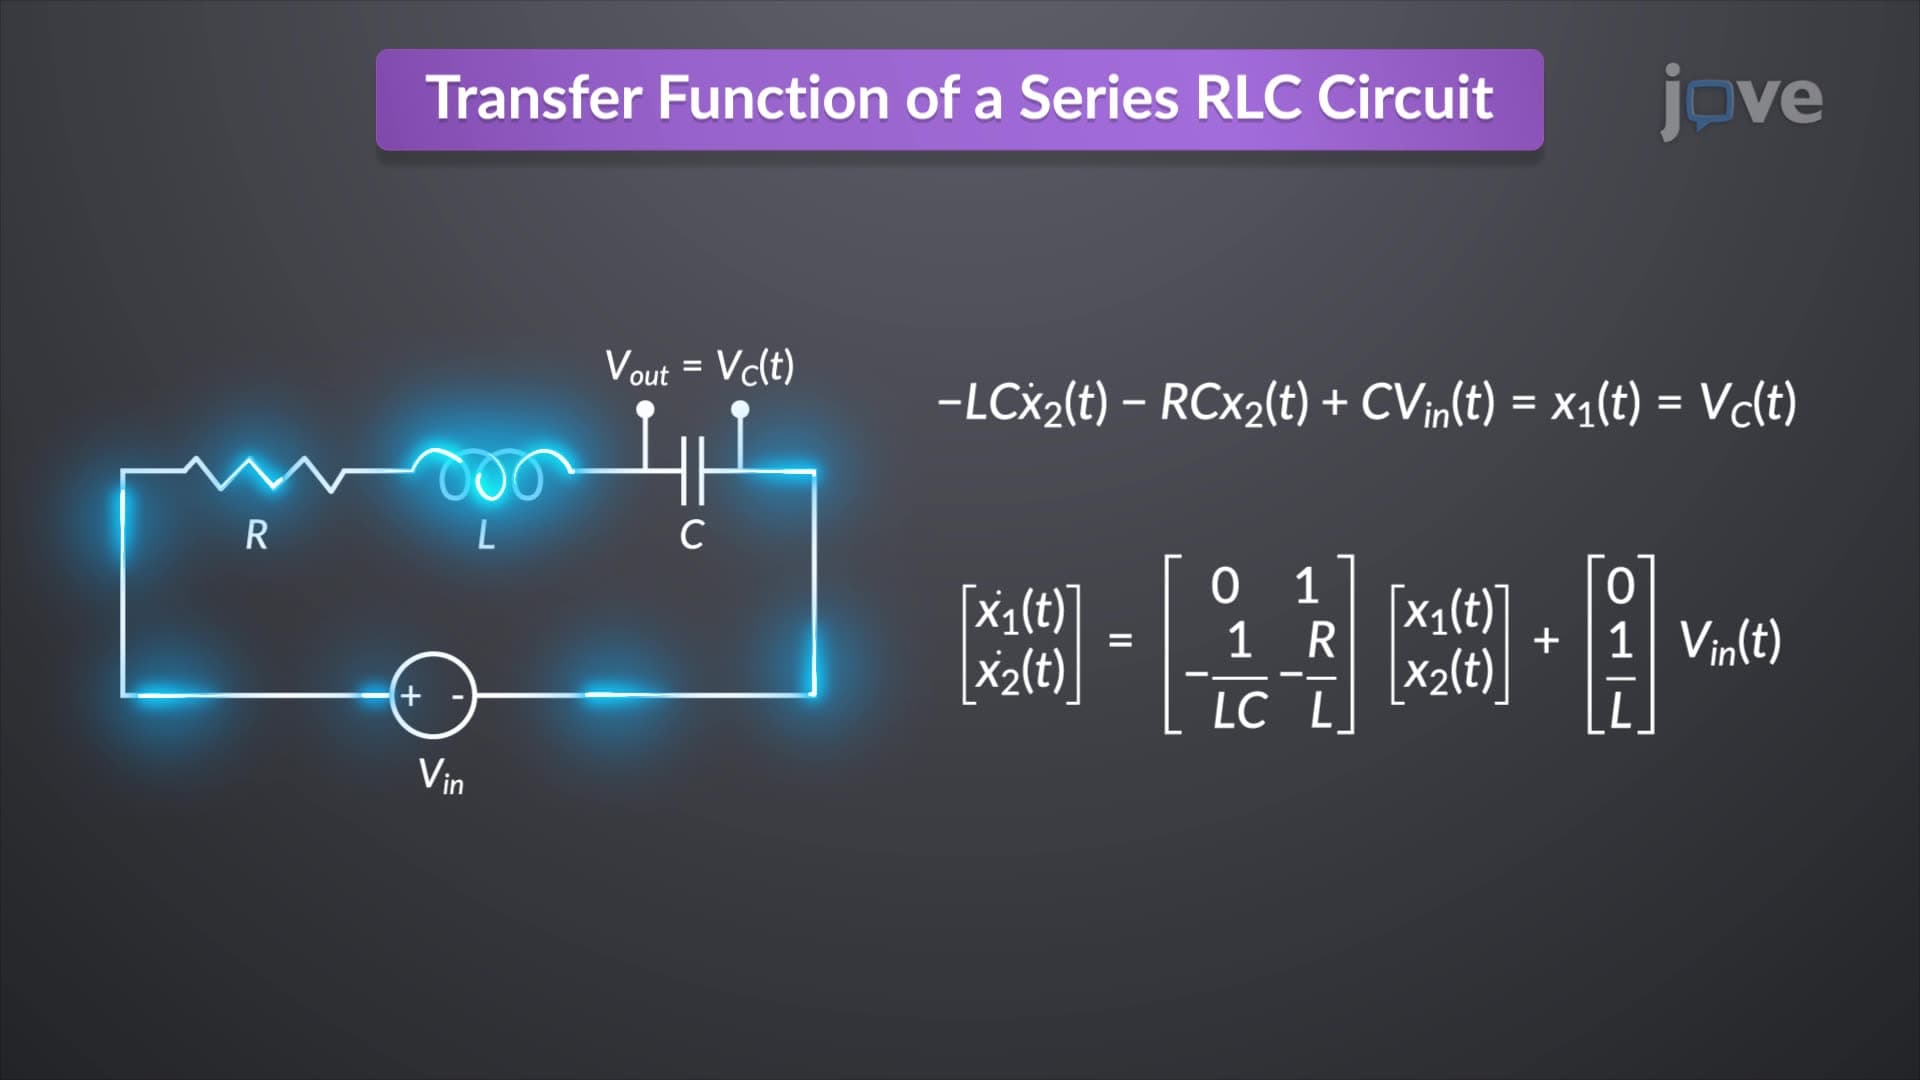
State-space representation is a powerful tool for simulating physical systems on digital computers, necessitating the conversion of the transfer function into state-space form. Consider an nth-order linear differential equation with constant coefficients, like those encountered in an RLC circuit. The state variables are selected as the output and its n−1 derivatives. Differentiating these variables and substituting them back into the original equation produces the state equations.
In an...
In an...
980
 01:24
Fast Decoupled and DC Powerflow
951
The fast decoupled power flow method addresses contingencies in power system operations, such as generator outages or transmission line failures. This method provides quick power flow solutions, essential for real-time system adjustments. Fast decoupled power flow algorithms simplify the Jacobian matrix by neglecting certain elements, leading to two sets of decoupled equations:
951
 01:21
State Space to Transfer Function
684
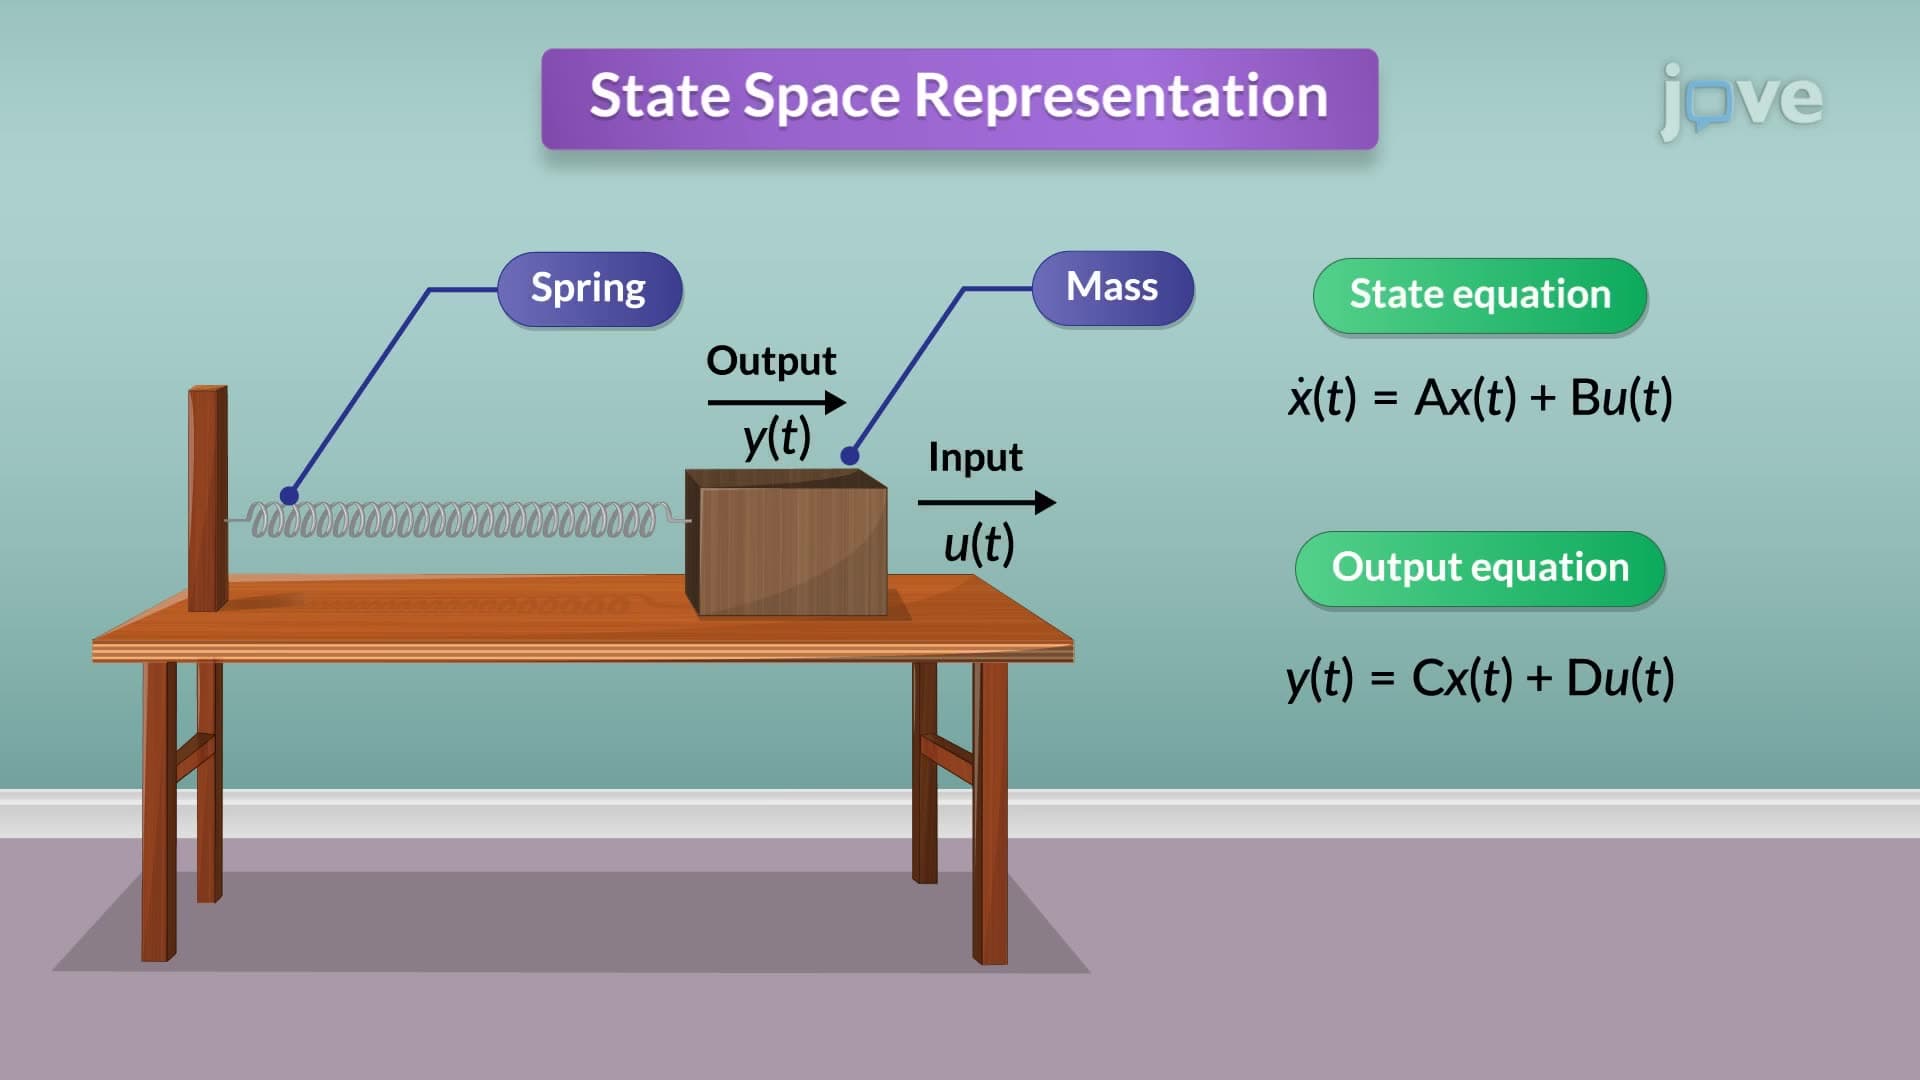
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
684