Related Experiment Video
Updated: Apr 28, 2026


Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
Multi-Gait In-Pipe Locomotion via Programmable Friction Reorientation
1Biomedical and Intelligent Robotics Laboratory, Department of Mechanical Engineering, Kyung Hee University, 1732 Deogyeong-daero, Yongin 17104, Republic of Korea.

Abstract:
In-pipe robots must navigate narrow, curved passages where rigid mechanisms often require bulky steering units. Soft crawlers offer better compliance but typically rely on multiple actuators or reconfigurable contacts to achieve multi-directional motion. Drawing inspiration from biological soft crawlers that exploit directional friction and coordinated anchor-slip patterns, this study focuses on locomotion principles observed in caterpillars, water boatmen, and whirligig beetles. Based on these bioinspired concepts, we present a tendon-driven soft in-pipe robot that combines continuum bending-twisting deformation with modular anisotropic friction pads (AFPs), enabling three locomotion modes using only two motors. AFP inclination, curvature, and ridge geometry were optimized through friction tests, constant-curvature modeling, and finite element analysis to enhance directional adhesion on flat and curved surfaces. A deformation-based locomotion framework was developed to couple tendon actuation with friction orientation, achieving longitudinal crawling, transverse translation, in-place rotation, and smooth transitions via programmed twisting. Driving experiments demonstrated repeatable anchor-slip locomotion with average speeds of 28.6 mm/s, 15.7 mm/s, and 11.5°/s for the three modes. Pipe tests in straight, curved, and T-junction sections further validated stable contact and reliable gait transitions. These findings highlight the potential of friction-programmed continuum robots as compact, bioinspired platforms for advanced in-pipe inspection and diagnostic tasks.
More Related Videos

Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:26
Kinetic Friction
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion....
 01:05
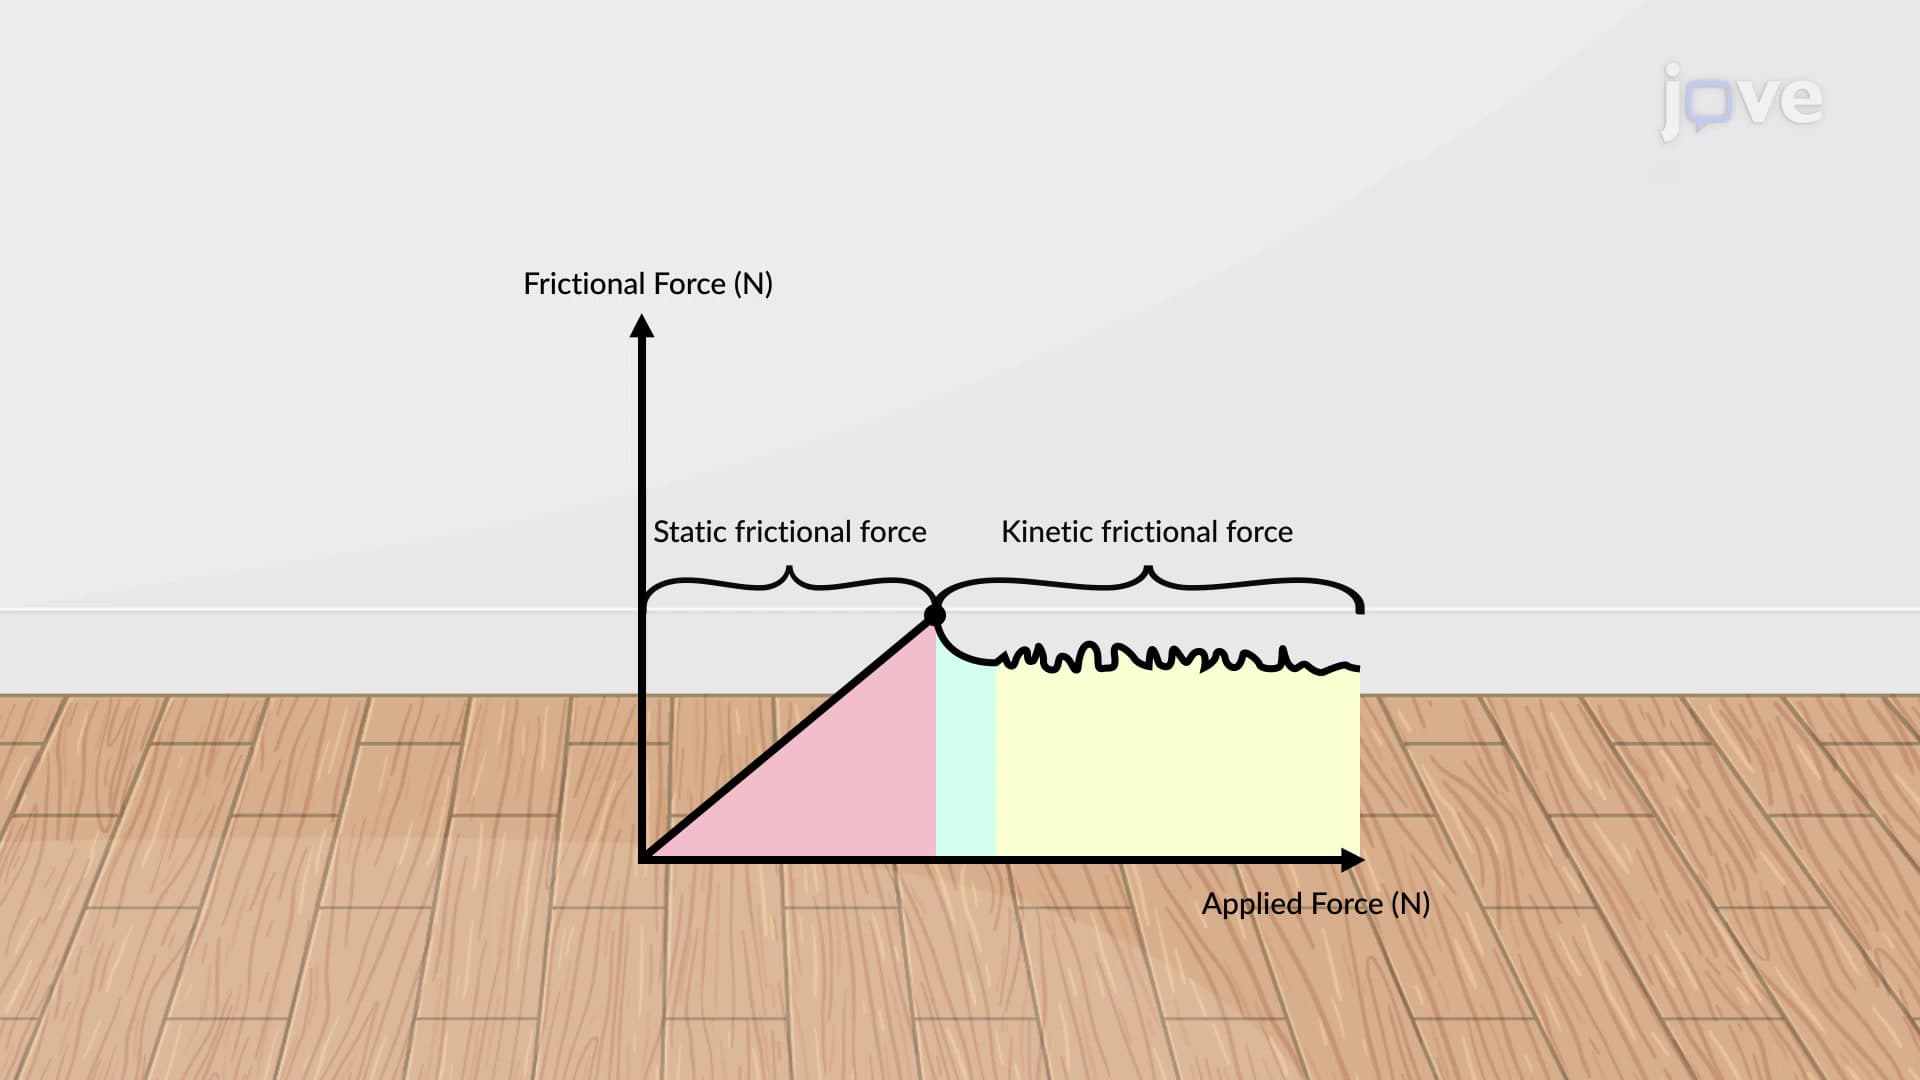
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down due to...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...