Related Experiment Video
Updated: May 1, 2026


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Twirlbot: Tumbleweed-inspired rolling robot
Chi Chen1, Zhuo Wang1, Yuchen Wang2
1Department of Materials Science and Engineering, University of California, Los Angeles, Los Angeles, CA 90095, USA.

Abstract:
Omnidirectional locomotion offers superior adaptability and maneuverability over uni-/bidirectional movement, with spherical structures being ideal due to their zero turning radius and geometric stability on complex terrains. However, existing spherical robots rely on embedded control components and onboard power sources, inevitably increasing design complexity, weight, and cost. Herein, we developed a tumbleweed-inspired rolling robot (Twirlbot) to achieve the hollow spherical architecture by weaving photoactive/passive bilayer strips. The Twirlbot demonstrated autonomous rolling under constant light, enabling multiple functionalities, including omnidirectional locomotion, slope climbing, trampling resistance, cargo transport, self-correction, wind resistance, and adaptation to diverse terrains and environments. These features endowed the Twirlbot with great potential for real-world applications, such as self-sustained seed-sowing, daylight-driven commuting, and autonomous underwater wiring. Notably, the structural design was generalizable to other systems, including commercial materials, enabling substantial cost reduction (less than one-tenth that of existing autonomous untethered robots) and thereby presenting a promising route toward next-generation untethered, self-sustained robotic systems.
Related Concept Videos
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down due to...
 01:17
Rolling Resistance: Problem Solving
 01:09
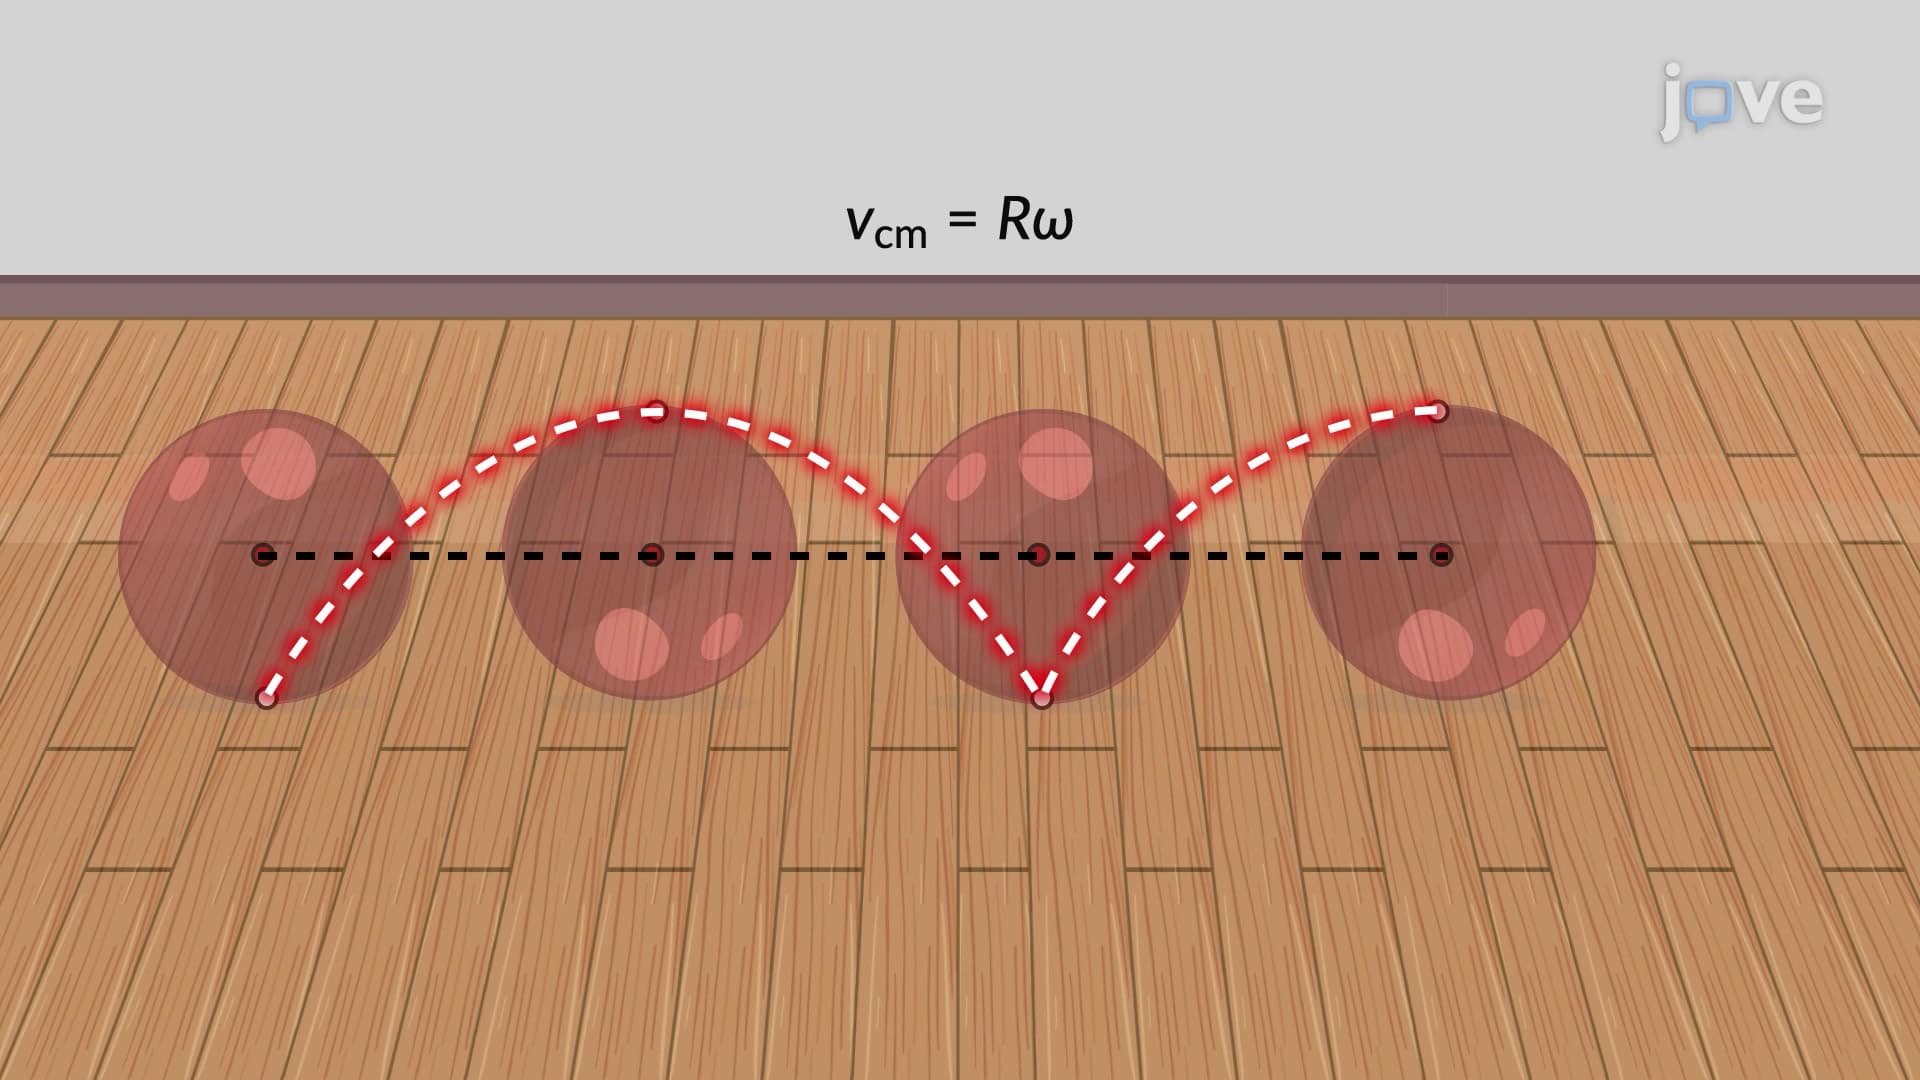
Rolling Without Slipping
 01:15
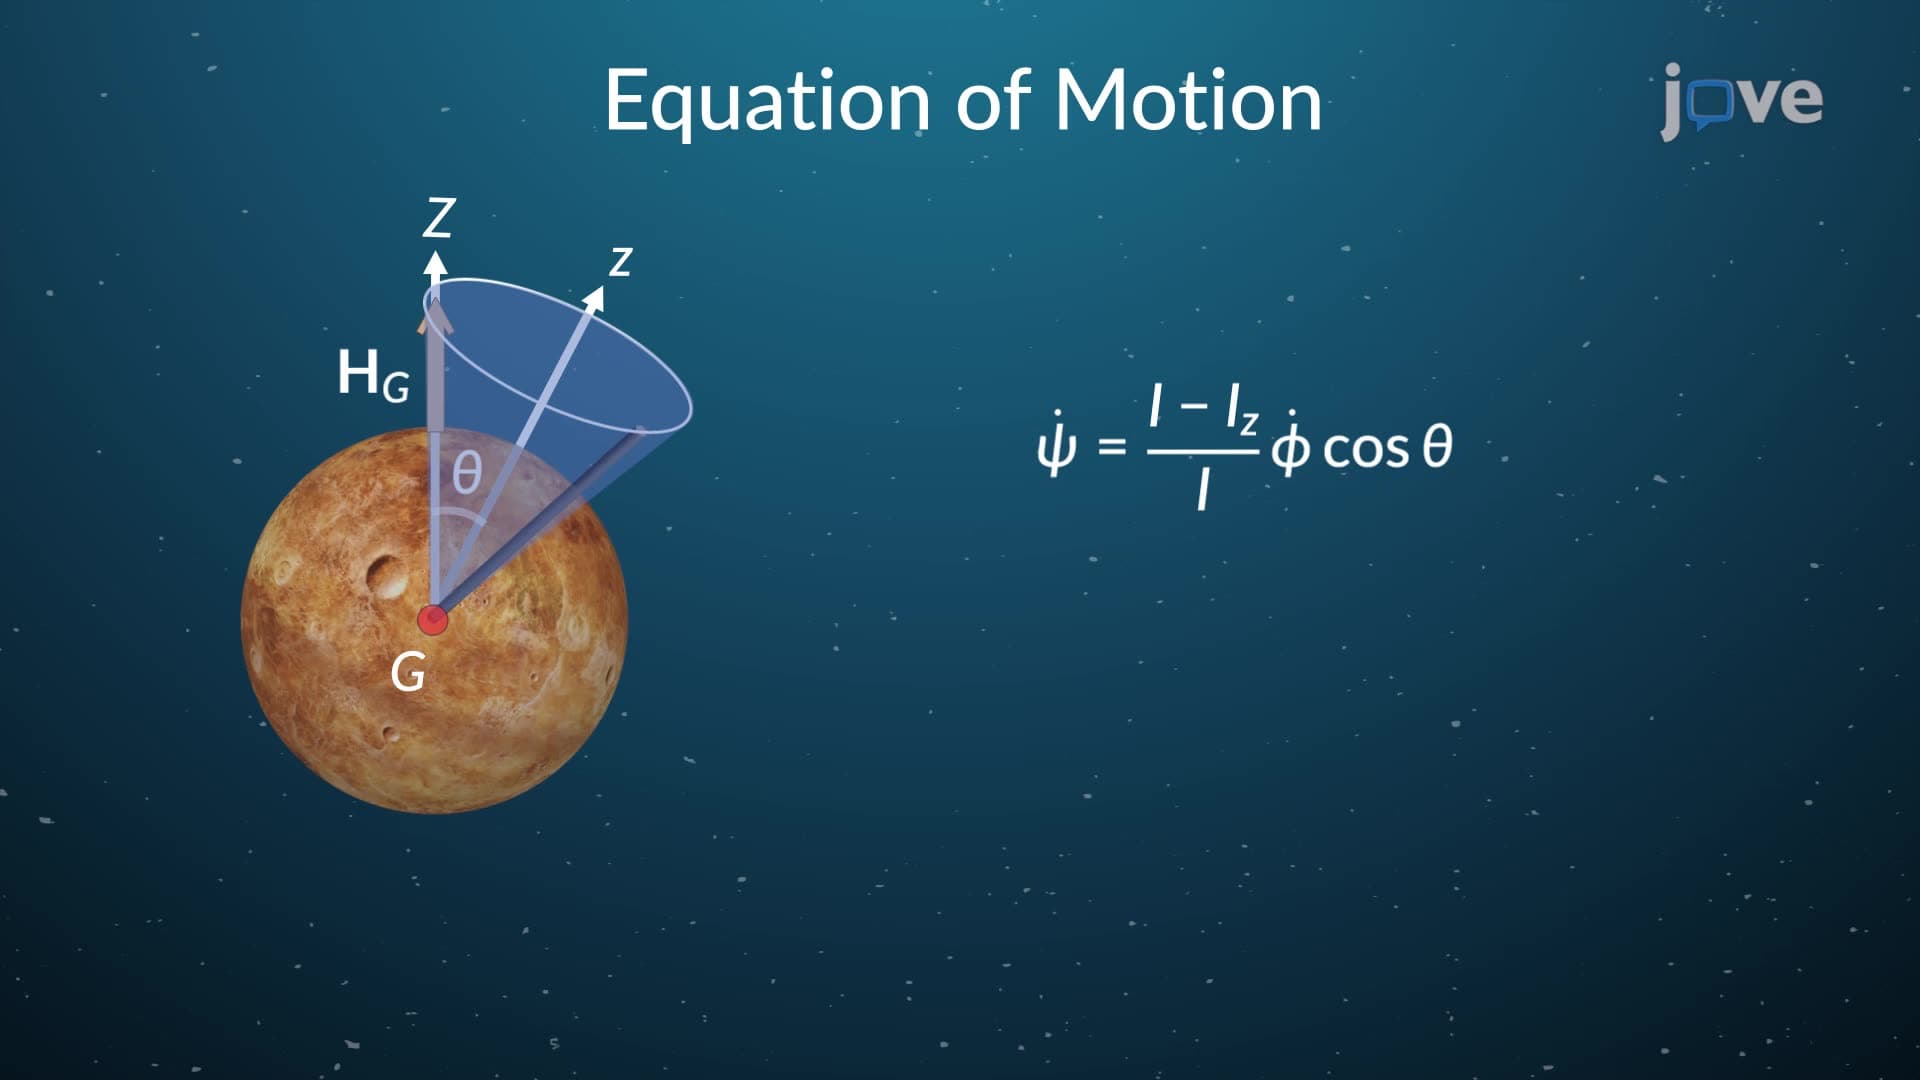
Torque Free Motion
 01:23
Pivot Bearings
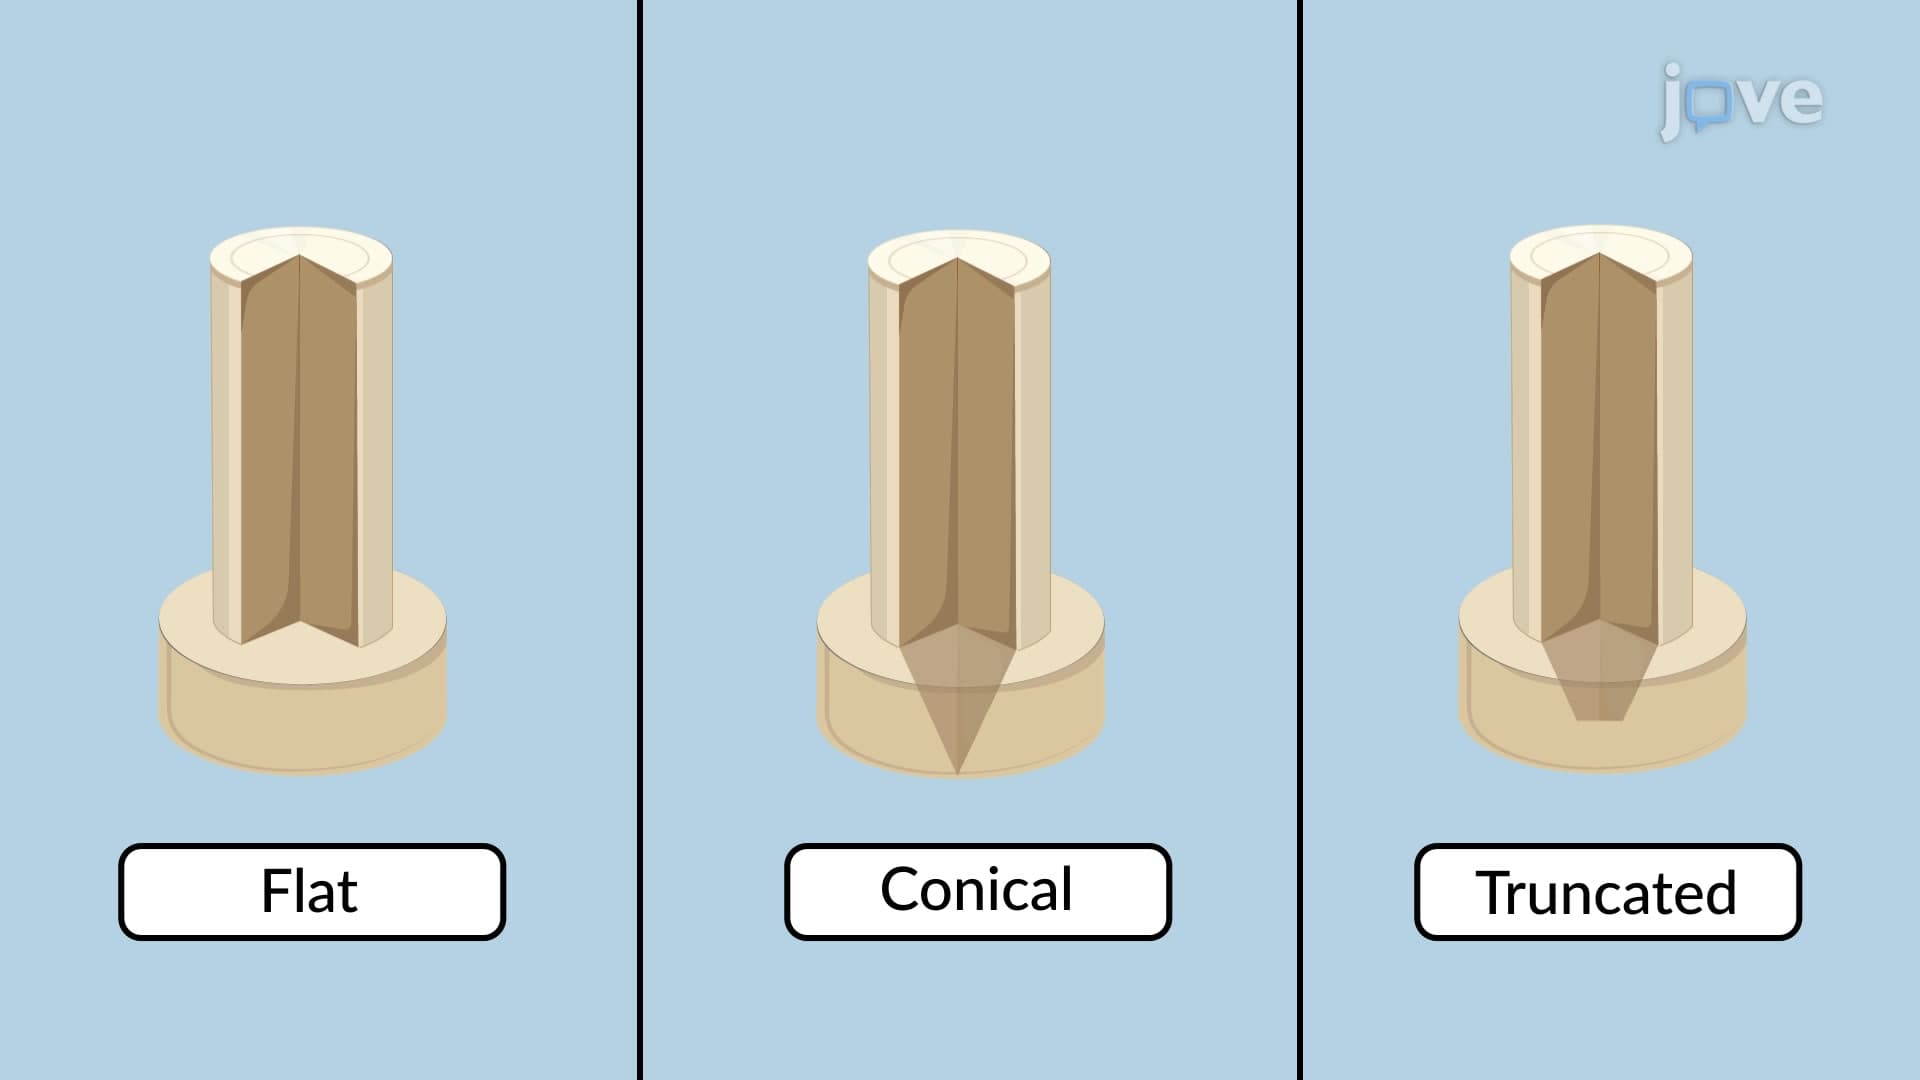
A pivot bearing is a specialized type of bearing designed to support axial loads on a rotating shaft. The bearing surface, or the pivot, is positioned at the end of a shaft to support the axial thrust. The pivot may...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...