Related Experiment Video
Updated: May 1, 2026


Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
A Minimal Solution to the Perspective-3-Point Problem for the Camera With Unknown Focal Length and Two

Abstract:
This paper presents a minimal solution to the absolute camera pose based on Perspective-3-Point problem for the camera with two degrees-of-freedom rotation and unknown focal length (P3P$+f$+f). First, according to the imaging equation from the control points to the corresponding image points, the minimal problem is converted into solving a system of four nonlinear algebraic equations in four unknowns. Then, using the classical resultant elimination method, the problem is cast into solving a six-degree polynomial equation in a single variable. Meanwhile, we propose an algorithm that may obtain directly the six-degree polynomial equation. We show that when three control points are in general position, the upper bound of the number of solutions to our P3P$+f$+f problem is 6. We also show the conditions in which the upper bounds of the solutions are two, four and infinite. Finally, we give some examples to validate our results and the accuracy, robustness and efficiency of our P3P$+f$+f solver are evaluated by testing on synthetic and real data.
More Related Videos
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:23
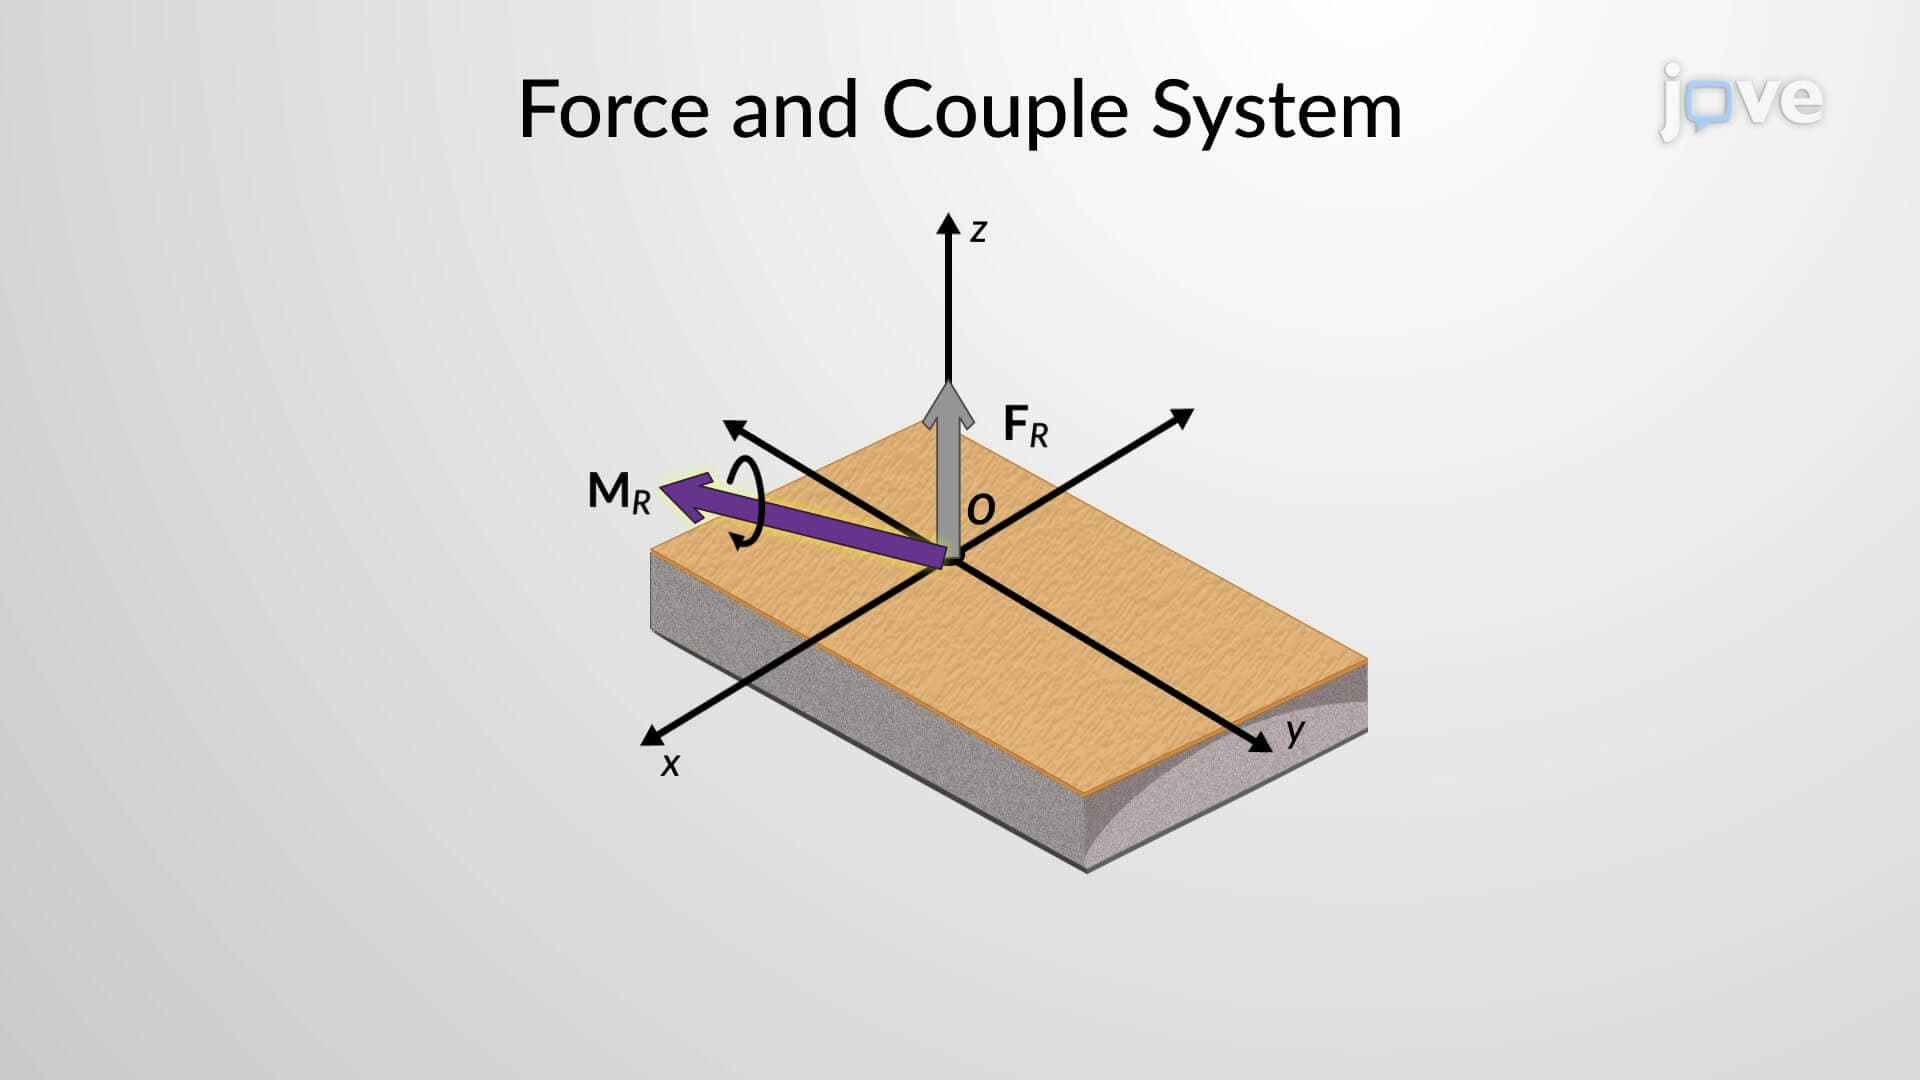
Simplification of a Force and Couple System: II
 01:30
Three-Dimensional Force System
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...