Related Experiment Video
Updated: May 2, 2026
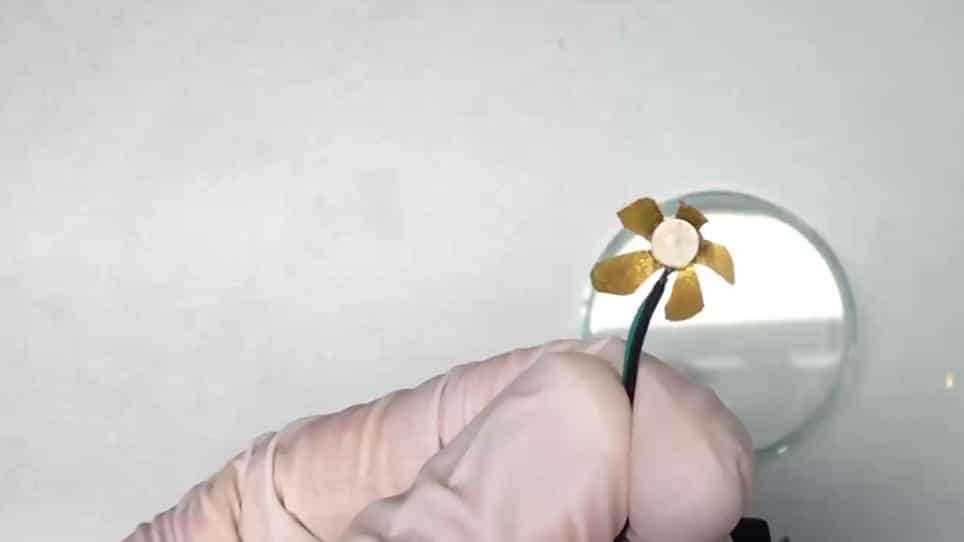

Fabrication of Carbon-Based Ionic Electromechanically Active Soft Actuators
Published on: April 25, 2020
An Anionic Framework-Enabled Ion-Anchoring Strategy for Frequency-Tolerant Electrochemical Actuation
Zhi-Xiang Guo1, Sha-Sha Wang1, Yan Li1
1Center for Molecular Systems & Organic Devices (CMSOD), State Key Laboratory of Flexible Electronics (LoFE) & Institute of Advanced Materials (IAM), Nanjing University of Posts & Telecommunications, Nanjing 210023, China.

Abstract:
Artificial muscles, owing to their lightweight nature, mechanical compliance and the ability to emulate biological muscle actuation, demonstrate immense potential in the field of bionic intelligent robotics. However, existing ionic electrochemical actuators generally exhibit pronounced frequency dependence and unstable actuation outputs under variable-frequency operation, which severely limit their ability to simulate scenarios requiring stable performance across varying frequencies. Herein, we report a zinc tetraphenylporphyrin (Zn-TPP)/1-ethyl-3-methylimidazolium tetrafluoroborate (EMImBF4) electrolyte membrane, in which the anionic TPP2- framework effectively anchors EMIm+ cations. This effect restricts cation migration under applied electric fields and thereby stabilizes the charge distribution within the electrolyte membrane. Benefiting from this mechanism, the actuator achieves an outstanding 99.97% displacement retention over a broad frequency range of 0.1-5 Hz at 3 V. In contrast, a conventional EMImBF4/PVDF-HFP-based electrochemical actuator exhibits a displacement retention of only 25% at 5 Hz. By comparing devices with three different TPP2--containing electrolyte membranes, we confirm a positive correlation between the electrostatic potential of TPP2- and actuator displacement retention. A higher electrostatic potential enables stable operation over a broader frequency range, whereas a lower electrostatic potential reduces stability but yields larger bending displacement, thereby allowing a tunable balance between stability and displacement amplitude to meet diverse application needs. In addition, the actuator maintains stable performance over a relative humidity range of 40-70%, ensuring reliable operation in biofluid-like environments. Notably, the actuator mimics the contraction behavior of the human Achilles tendon and maintains stable, repeatable responses under varied rhythmic conditions, highlighting its potential for next-generation soft robotics.
More Related Videos
 06:53
Author Spotlight: Magnetometric Characterization of Intermediates in the Solid-State Electrochemistry of Redox-Active Metal-Organic Frameworks
Published on: June 9, 2023
 09:55
Preparation of Janus Particles and Alternating Current Electrokinetic Measurements with a Rapidly Fabricated Indium Tin Oxide Electrode Array
Published on: June 23, 2017
Related Concept Videos
 01:17
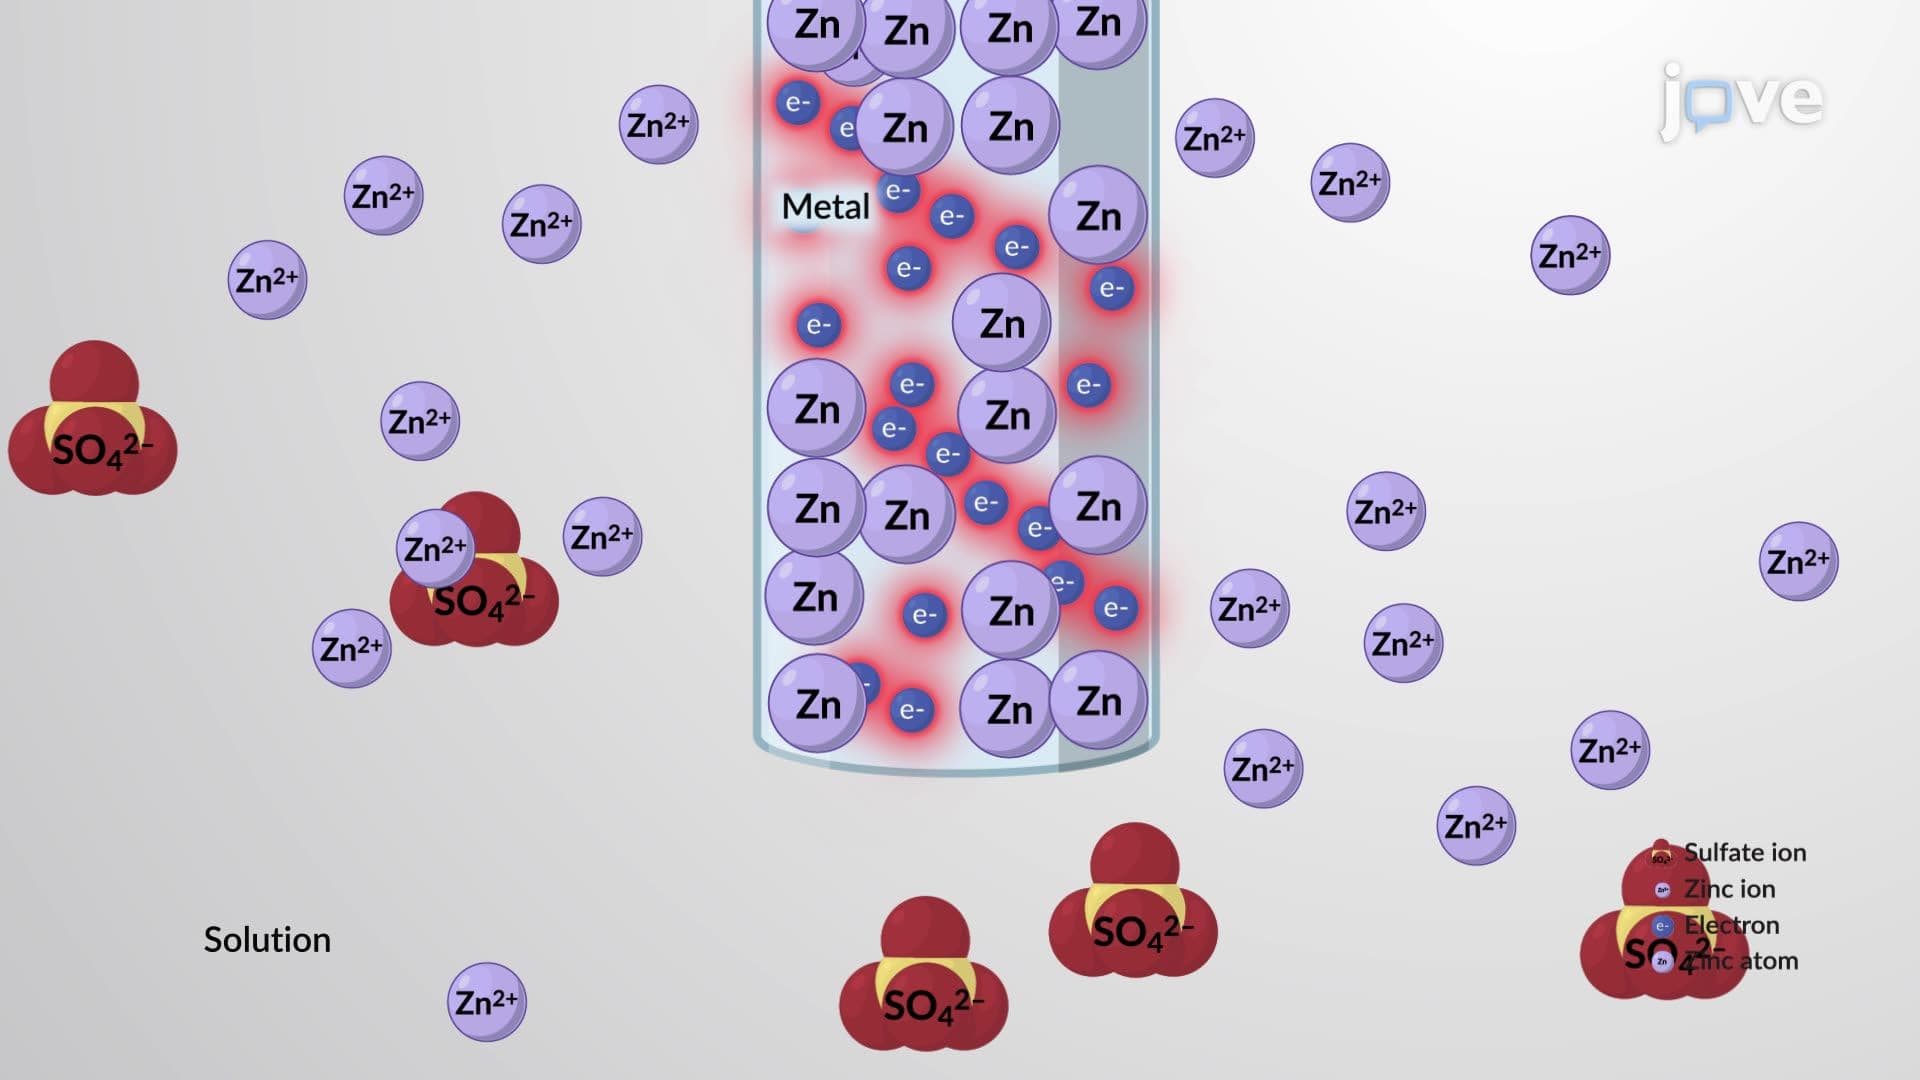
Ion Exchange
 01:24
Electrochemical Systems
 01:12
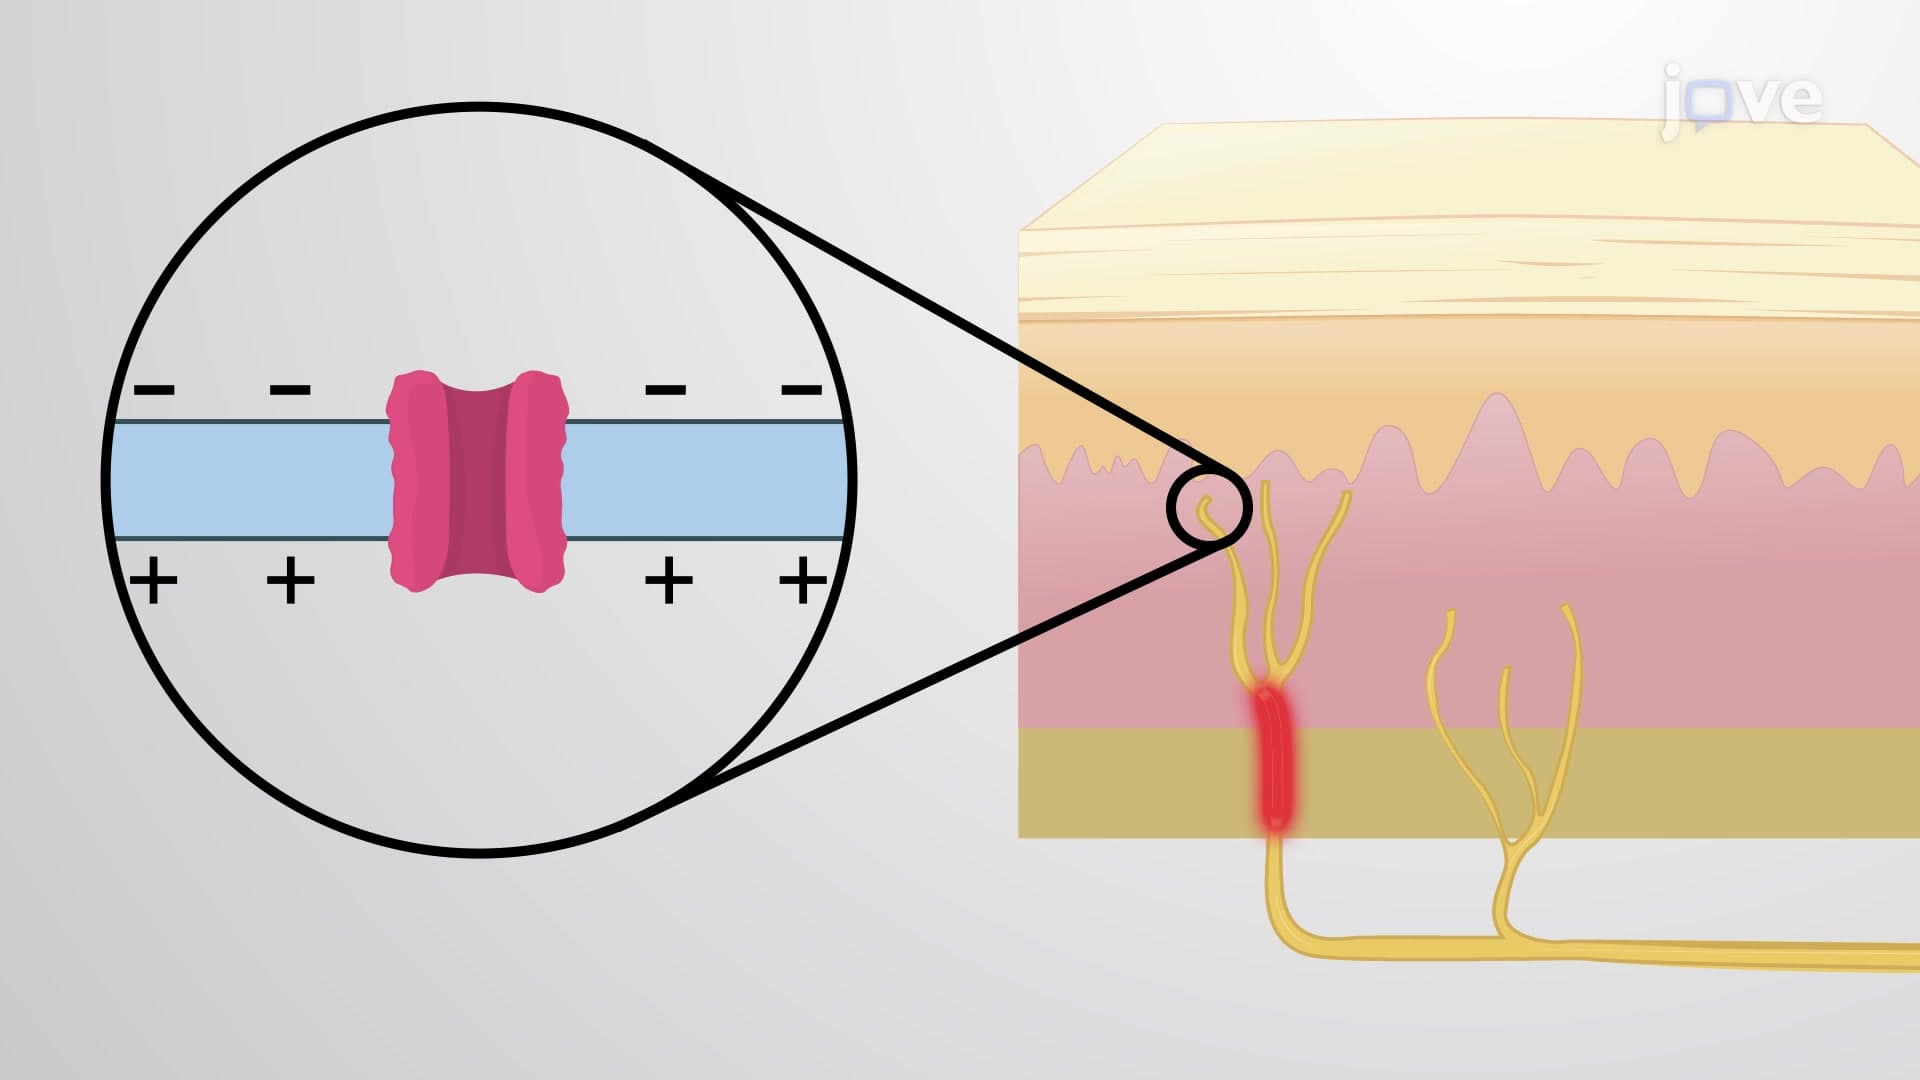
Mechanically-gated Ion Channels
01:12Mechanically-gated Ion Channels
 01:28
Electrochemical Cells
 02:48
Ionic Bonding and Electron Transfer