Related Experiment Video
Updated: May 4, 2026
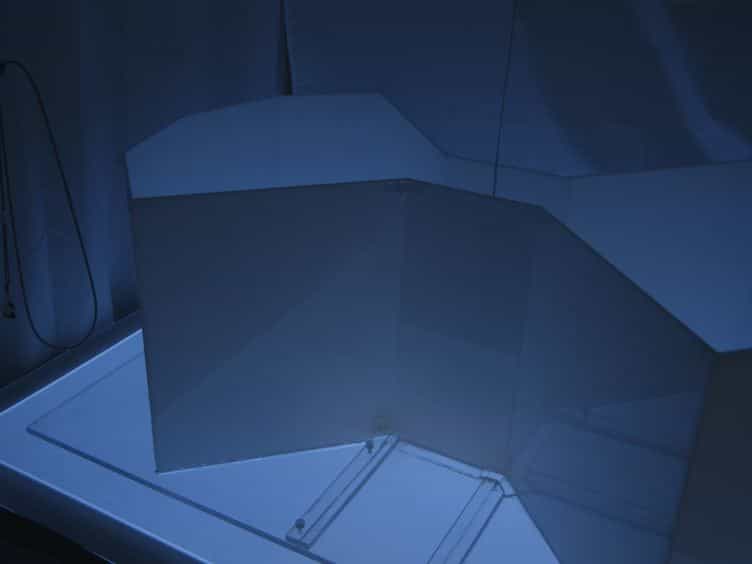

Automated Visual Cognitive Tasks for Recording Neural Activity Using a Floor Projection Maze
Published on: February 20, 2014
Curriculum reinforcement learning with measurable task representation learning
Yongyan Wen1, Siyuan Li1, Mingjian Fu2
1Harbin Institute of Technology, Harbin, 150001, Heilongjiang, China.

Abstract:
In curriculum reinforcement learning (CRL), an agent incrementally accumulates knowledge over a sequence of tasks (i.e., a curriculum), and the learning process is aimed at using the accumulated knowledge to finally solve a challenging target task. While early CRL works focus on sequencing candidate tasks, recent research explores automatic curriculum generation. Among the rich CRL literature, the interpolation-based CRL paradigm is a main body, which automatically generates intermediate tasks by interpolating between the initial task distribution and the target task distribution in task space with meaningful distance metrics (i.e., can measure the task similarity). However, in challenging navigation tasks, the non-Euclidean context (task) space invalidates this assumption. To achieve automatic curriculum generation in complex task, we propose a novel automatic curriculum generation approach based on measurable task representation learning. To better measure the similarity, we propose to transform the task space to a latent space. Through a variational autoencoder structure that encodes the reward and the state transitions, we achieve a latent task representation with a task similarity measurement property, and two close task embeddings correspond to two similar tasks in terms of rewards and state transitions. Based on the learned task representation, we further develop an automatic curriculum generation scheme, which can effectively generate new tasks more and more similar to the target task. We evaluate our method in a variety of challenging navigation tasks, and the experiment results indicate that the proposed approach surpasses state-of-the-art CRL approaches based on interpolation and generative adversarial networks.
More Related Videos

Related Concept Videos
 01:22
Purposive Learning
 01:12
Observational Learning
 01:27
Associative Learning
Classical conditioning, also known...
 01:14
Steps in the Modeling Process
Attention is the first necessary component for observational learning. It involves focusing on what the model is doing and saying. For example, if you decide to take a drawing class to enhance your skills, you need to pay close attention to the instructor's words and hand movements. The characteristics of the model significantly...
 01:26
Higher Mental Functions of Brain: Learning and Memory
 01:30
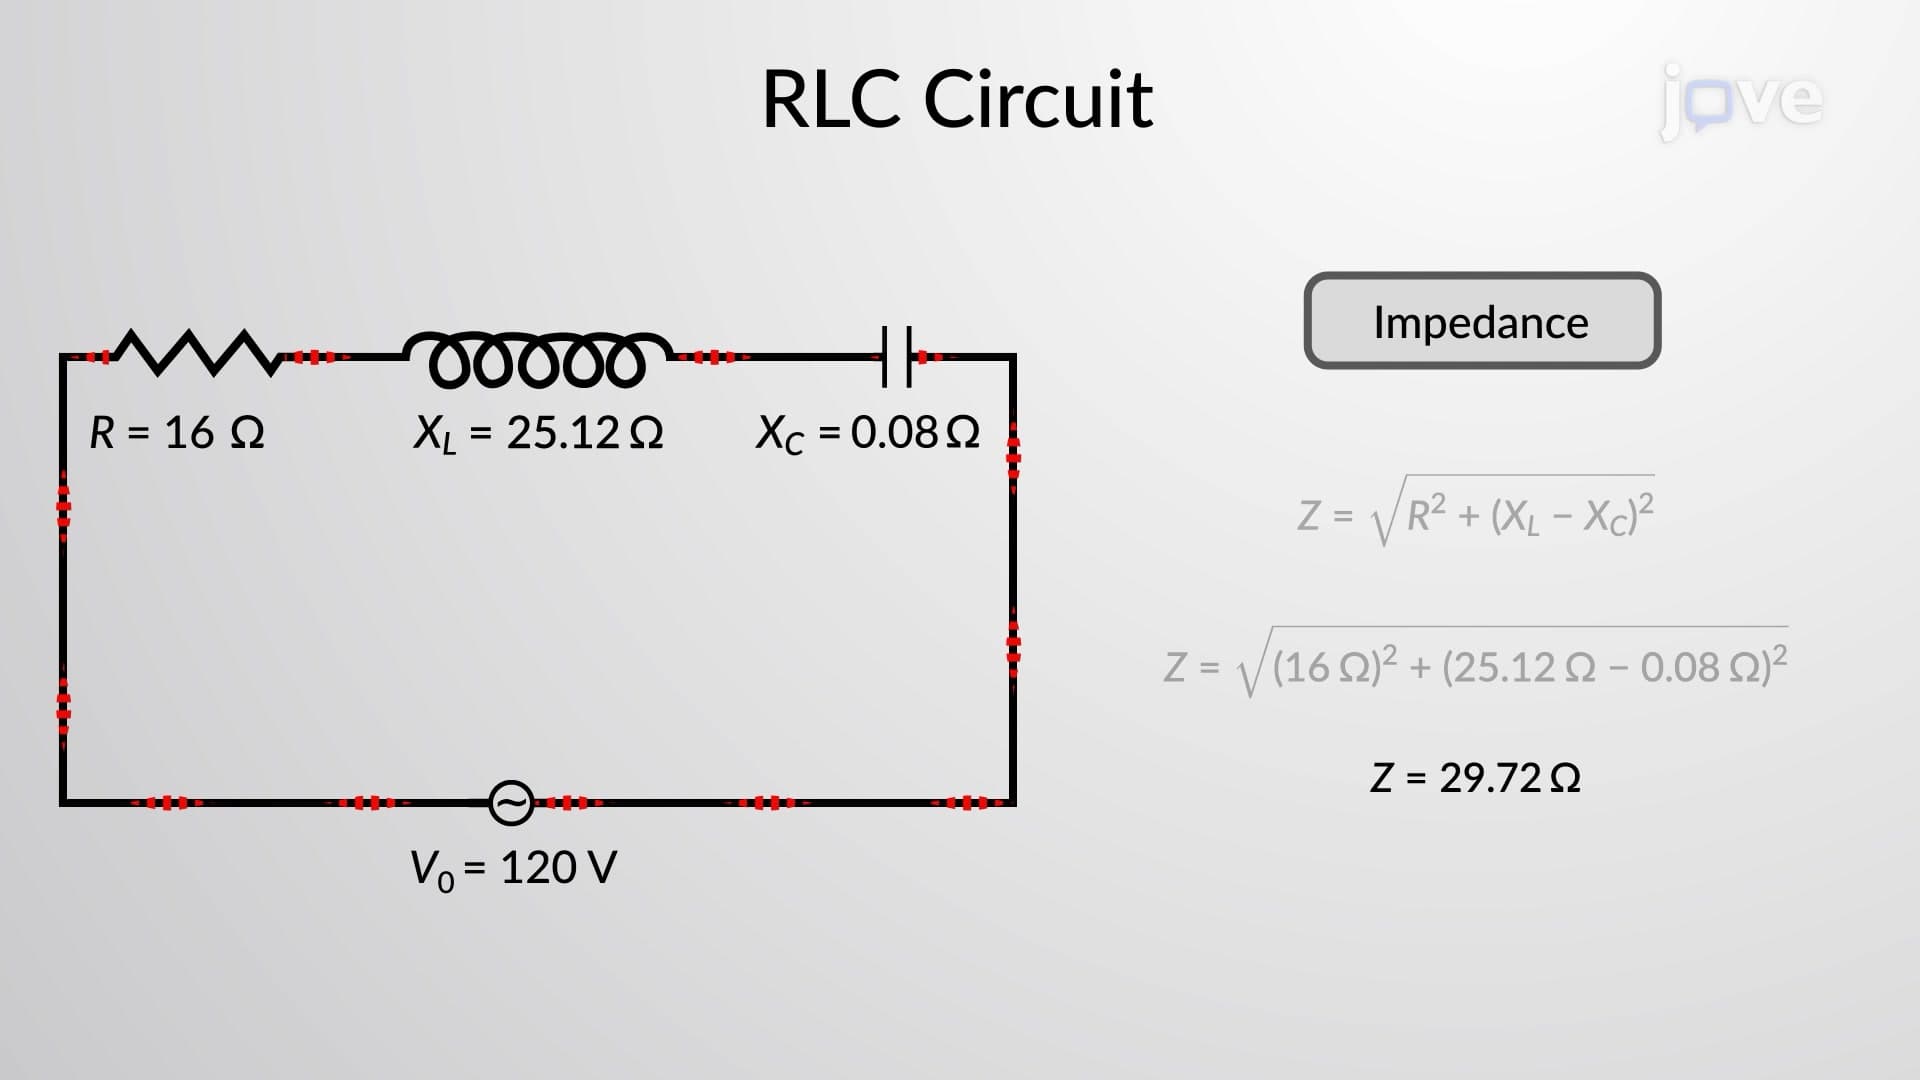
RLC Series Circuit: Problem-Solving
To solve the problem, first, determine the known and unknown quantities in the problem. Recalling the reactance equation for the inductor and capacitor and substituting the values,...