Related Experiment Video
Updated: May 13, 2026
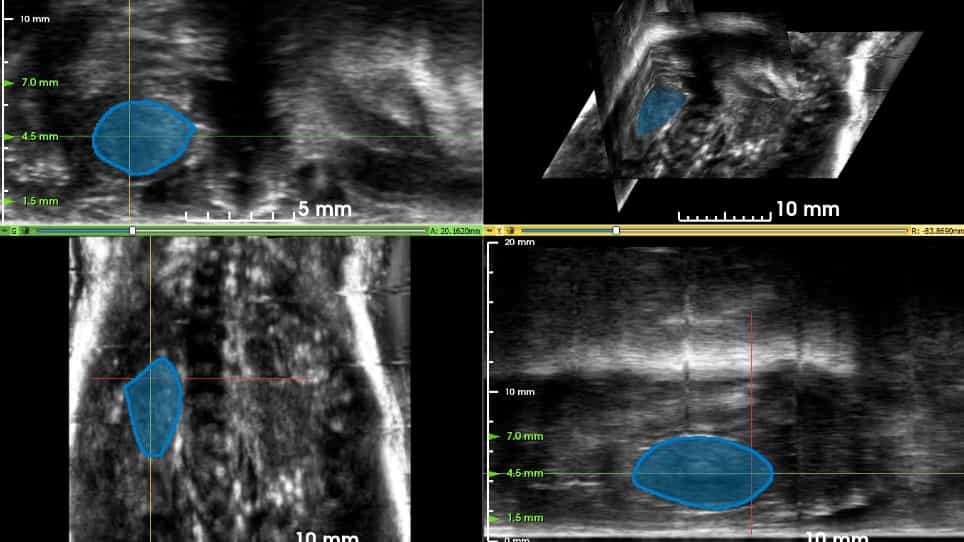

Use of 3D Robotic Ultrasound for In Vivo Analysis of Mouse Kidneys
Published on: August 12, 2021
Multi-pass Volume Reconstruction for Freehand Ultrasound: Demonstration in Simulation, Phantom, and In Vivo Kidney

Objective:
This work describes the development and validation of an algorithm to improve ultrasound volume reconstruction from noisy initial scans taken using a tracked freehand ultrasound device.
Methods:
The algorithm was first tested and refined in simulation using an approximate kidney shape model re-sliced to represent various real life scan conditions. Next, an Intel RealSense D435i camera was used to track the pose of a commercial ultrasound probe. This device was used to scan a phantom with a known volume and shape. Finally, repeated scans were taken in vivo to test the repeatability of volume measurements.
Results:
The simulation experiments were used to refine algorithm hyperparameters. The volume of the phantom was measured to within 2.5-17% (1-11.5% with automatic pass finding) of ground truth for four different scan styles, compared to traditional methods that underestimate the volume by 17.5%. In 11 human subjects, right kidney volume was measured within between 3.6-14.6% (7.7-23.3% with automatic pass finding) variation between scans.
Conclusion:
The proposed algorithm was demonstrated to produce repeatable volume measurement results in both phantom and in vivo scans.
Significance:
The proposed algorithm improves the clinical translatability and repeatability of freehand volume ultrasound systems.
Related Concept Videos
 01:28
Imaging Studies I: Kidney, Ureter, and Bladder Studies
 01:24
Imaging Studies II: Ultrasonography