Related Experiment Video
Updated: May 14, 2026
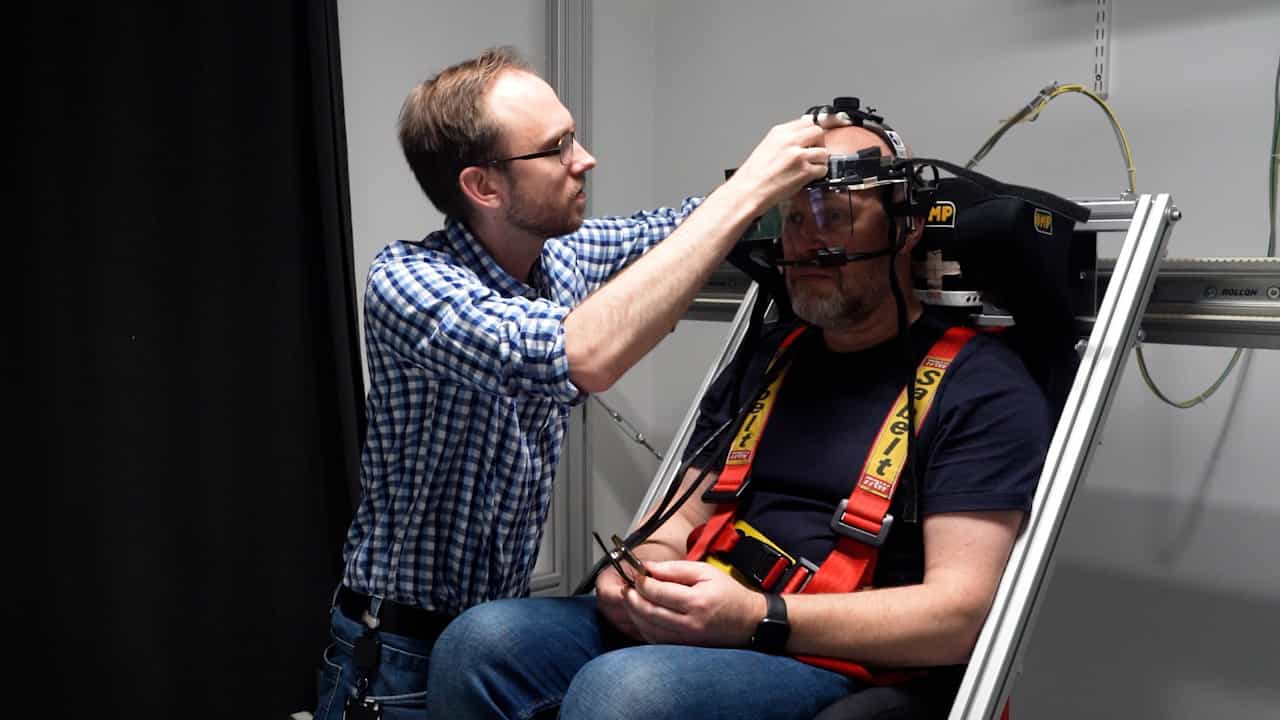

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
VisualRNet: Lightweight Camera Rotation Estimation from Low-Resolution Optical Flow via Cross-Modal Supervision
Xiong Yang1, Hao Wang2, Jiong Ni2
1School of Cyberspace Security, Changzhou College of Information Technology, Changzhou 213164, China.

Abstract:
Camera rotation estimation is a key component in video stabilization and motion analysis. In many practical scenarios, inertial measurements are unavailable or temporally unreliable, while classical geometric pipelines degrade under blur, low texture, and low illumination. This paper investigates whether substantially downsampled optical flow can retain sufficient structure for accurate frame-to-frame rotation regression. We present VisualRNet, a lightweight rotation-specific visual regression framework trained with cross-modal IMU supervision. Our design uses coordinate-aware feature encoding, depthwise separable convolutions, lightweight attention, and a compact 6D rotation head to model the spatial structure of rotational flow fields. On Deep-FVS, VisualRNet achieves a mean rotation error of 0.3151° on the test set. The VisualRNet regression head contains 7.7 K parameters, 0.002 GFLOPs, and runs at 729 FPS, while the full pipeline with the FastFlowNetv2 frontend contains 1.374 M parameters, 7.194 GFLOPs, and runs at approximately 113 FPS. A cross-camera adaptation experiment on TUM VI further indicates that the learned motion representation can be aligned to a new camera system with limited calibration data. These results support low-resolution optical flow as a practical input for visual rotation estimation and suggest particular value in stabilization-oriented and cost-sensitive applications where approximate rotational trend matters more than full scene geometry.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...