Related Experiment Video
Updated: May 14, 2026
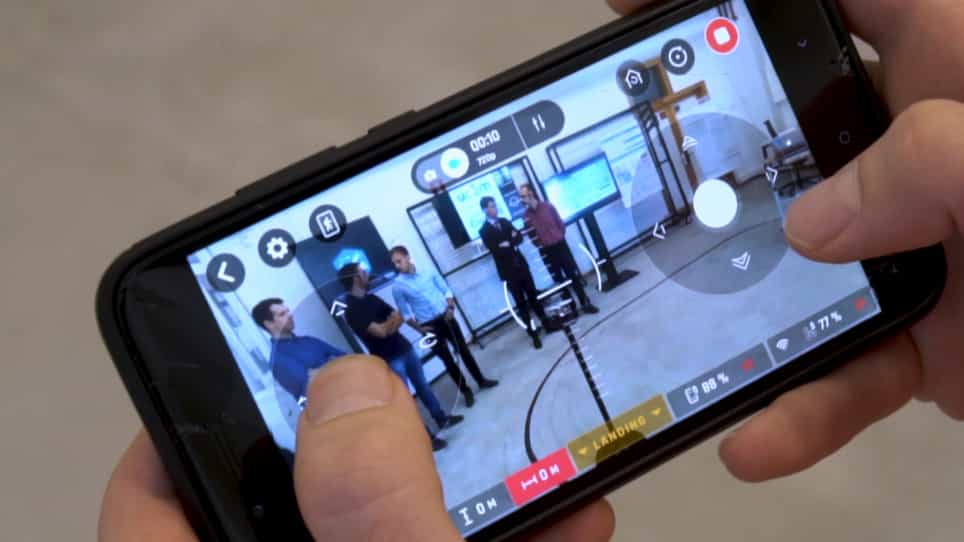

Automated Deployment of an Internet Protocol Telephony Service on Unmanned Aerial Vehicles Using Network Functions Virtualization
Published on: November 26, 2019
An Ultralight Launch-and-Recovery System for Tethered Micro Unmanned Aerial Vehicles on Small Unmanned Ground
Yiding Liu1, Zhuoqun Shen2, Jingjing Xu2
1Key Laboratory for the Physics and Chemistry of Nanodevices, School of Electronics, Peking University, Beijing 100871, China.

Abstract:
Heterogeneous unmanned ground vehicle-unmanned aerial vehicle (UGV-UAV) collaborative systems offer clear advantages for field exploration. However, when tethered unmanned aerial vehicles (TUAVs) are introduced to extend mission capability, a major compatibility gap emerges for small and highly maneuverable UGVs: existing industrial tethered ground stations are generally too heavy and bulky to be carried by such platforms. In addition, on unstructured ground, residual station tilt can significantly complicate UAV launch and recovery. To address these issues, this paper develops an ultralight vehicle-mounted tethered ground station for micro unmanned aerial vehicles (micro-UAVs) that can be integrated directly with small UGVs. Through co-design of a 2-degree-of-freedom (2-DOF) self-leveling launch platform and a passive tether-assisted recovery scheme without visual fiducials, in which a customized UAV flight-control loop is coordinated with the state transitions of the ground tether-management system, the proposed system achieves practical tether-assisted recovery. Experiments show that the complete platform weighs only 4.1 kg and that the self-leveling mechanism compensates for ground inclinations over a total range of 24 degrees. Repeated passive-landing tests further demonstrate the feasibility of the proposed recovery scheme and its tolerance to moderate bay tilt and terminal off-axis activation. System-level flight validation confirms practical tether-assisted recovery without visual fiducials. In addition, we conduct a simplified exploratory simulation of tether-based ground-anchor localization under the proposed system architecture. Overall, these results establish a lightweight and low-cost hardware design and a practically viable recovery strategy for multimodal micro air-ground robotic systems.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:21
Intrauterine Drug Delivery Systems