Related Experiment Video
Updated: May 15, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Experimental real-time implementation of backstepping control for a PMSG wind turbine on dSPACE platform
Adil El Kassoumi1, Btissam Majout2, Mohamed Lamhamdi1
1Department of Radiation-Matter and Instrumentation, Faculty of Sciences and Technology Settat, Hassan First University, Settat, 26000, Morocco.

Abstract:
Wind energy conversion systems (WECS) exhibit highly nonlinear behavior due to the stochastic nature of wind speed variations. In such conditions, the main objective is to maximize the extracted power while ensuring stable system operation. This paper presents a nonlinear control strategy for a grid-connected WECS based on a permanent magnet synchronous generator (PMSG). A backstepping control strategy (BSC) is applied to regulate both the machine-side converter (MSC) and the grid-side converter (GSC). The proposed controller aims to improve wind energy extraction under variable wind conditions while ensuring smooth operation of the PMSG with satisfactory static and dynamic performance. The effectiveness of the proposed approach is first evaluated through simulation studies conducted in the MATLAB/Simulink environment. The results obtained show improvement in effectiveness in terms of reference tracking, response time, overshoot elimination, accuracy, and mitigation of power ripple. Additionally, the feasibility of the proposed BSC is experimentally verified through real-time implementation on a dSPACE DS1104 board.

Related Concept Videos
 01:24
Wind Turbine Machine Models
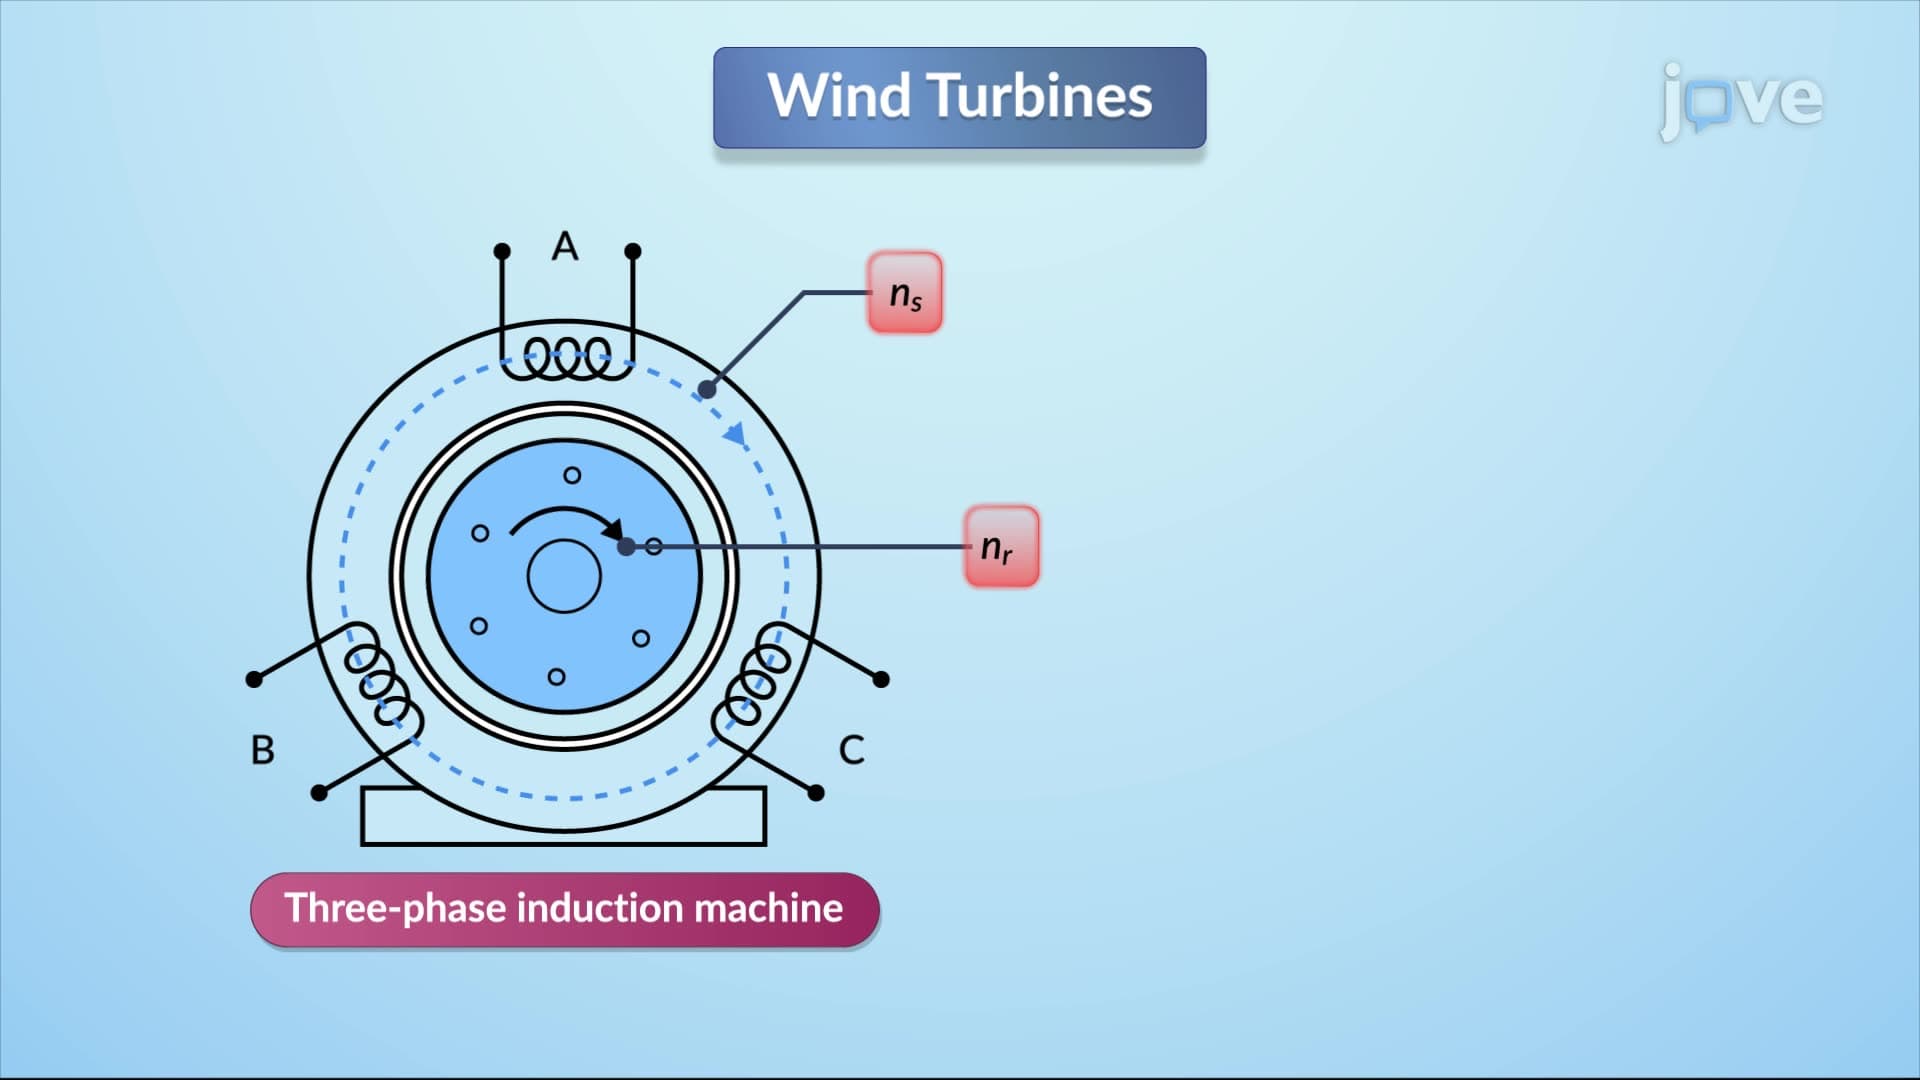
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Turbine-Governor Control
 01:19
PID Controller
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...