Related Experiment Video
Updated: May 17, 2026


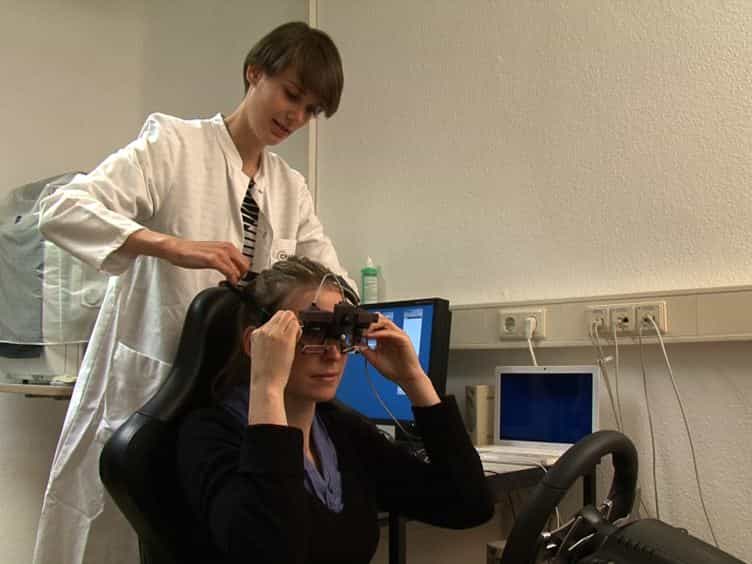
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Driving style characteristics and user discomfort in urban automated driving: Insights from a context-based comfort
M Hentschel1, C Hollander2, P Roßner1
1Ergonomics and Innovation, Chemnitz University of Technology, Chemnitz, Germany.

Abstract:
The perception of driving comfort resulting from differing automated driving styles has been broadly researched for both highways and rural roads, where high but steady speeds and smooth traffic flow dominate. Consequently, driving styles have been optimized for these conditions. In contrast, urban areas, where traffic and environmental complexity is much higher, challenge the design of comfortable and trustworthy driving styles. Less research has been done on urban driving situations which require almost constant adjustment of driving dynamics to cope with e.g., traffic light approaches, crossing traffic and obstacle avoidance. To address this gap, we conducted a study in a Type C fixed-base driving simulator with N = 60 participants to examine how different driving styles (dynamic vs. defensive) influence the perceived driving experience in urban situations. Psychological discomfort was continuously recorded using a handset control, complemented by standardized questionnaires (trust, comfort, acceptance, perceived safety, and behavior understanding) and post-experimental interviews on comfort aspects of the driving style. Results indicate that discomfort primarily arises from perceived uncertainty about whether and how the automated vehicle handles upcoming situations. The defensive driving style, characterized by anticipatory actions, led to lower discomfort in these situations. In contrast, the dynamic style caused increased discomfort as well as overall lower trust and acceptance ratings. Interestingly, during acceleration maneuvers, the dynamic style showed less discomfort compared to the defensive style. Our data suggest that automated vehicles should adapt driving styles contextually - favoring defensive strategies in uncertain situations (e.g., traffic light approaches) while incorporating dynamic elements where a swift response aligns with user expectations (e.g., acceleration after stops).
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:28
Automatic Processing and Automatic Social Behavior
 01:20
Frustration and Conflict: Approach-Approach, Approach-Avoidance
One common type of conflict is the Approach–Approach Conflict. In this case, a person faces two desirable options,...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:26
Causes of Similarity-Dissimilarity Effect