Related Experiment Video
Updated: May 21, 2026

Temporal Ordering of Dynamic Expression Data from Detailed Spatial Expression Maps
Published on: February 9, 2017
Deep Continuous-Time State-Space Models for Marked Event Sequences
Yuxin Chang1, Alex Boyd2, Cao Xiao2
1University of California, Irvine.

Abstract:
Marked temporal point processes (MTPPs) model sequences of events occurring at irregular time intervals, with wide-ranging applications in fields such as healthcare, finance and social networks. We propose the state-space point process (S2P2) model, a novel and performant model that leverages techniques derived for modern deep state-space models (SSMs) to overcome limitations of existing MTPP models, while simultaneously imbuing strong inductive biases for continuous-time event sequences that other discrete sequence models (i.e., RNNs, transformers) do not capture. Inspired by the classical linear Hawkes processes, we propose an architecture that interleaves stochastic jump differential equations with nonlinearities to create a highly expressive intensity-based MTPP model, without the need for restrictive parametric assumptions for the intensity. Our approach enables efficient training and inference with a parallel scan, bringing linear complexity and sublinear scaling while retaining expressivity to MTPPs. Empirically, S2P2 achieves state-of-the-art predictive likelihoods across eight real-world datasets, delivering an average improvement of 33% over the best existing approaches.
Related Concept Videos
 01:27
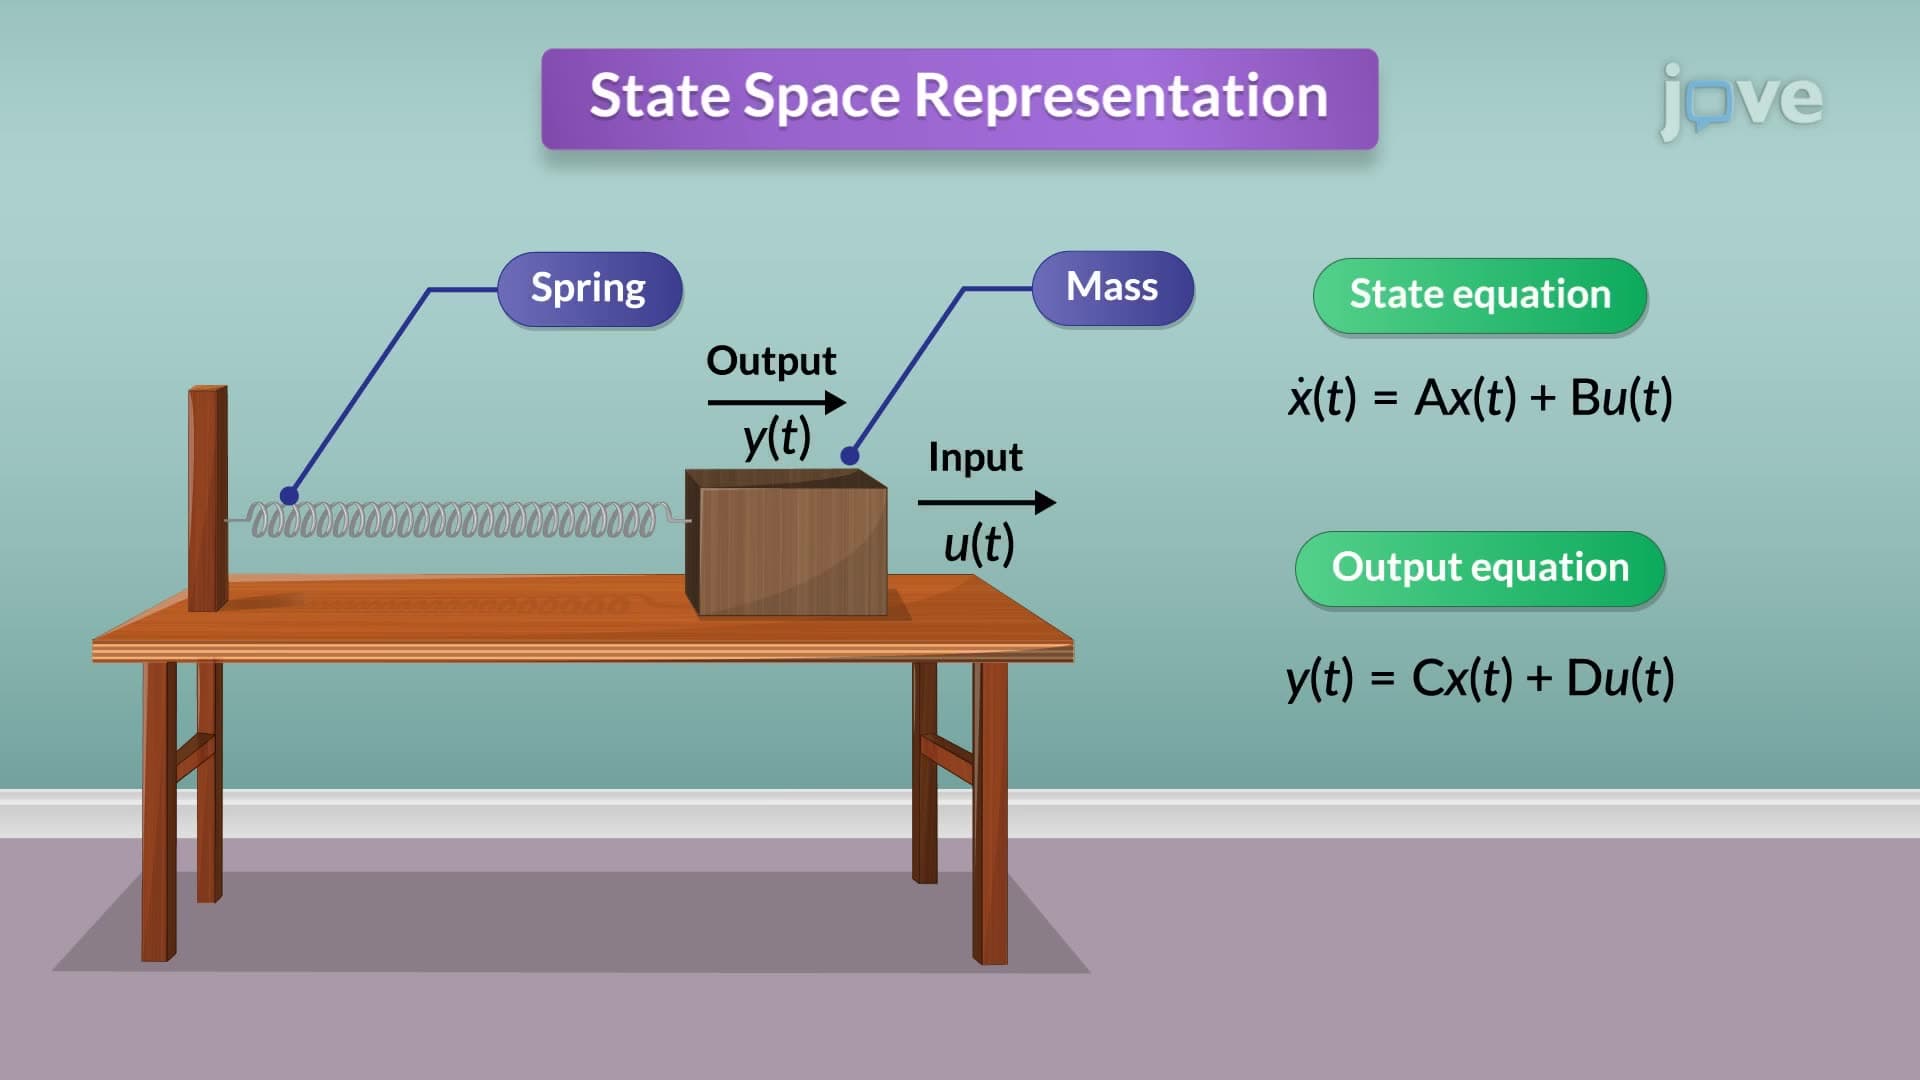
State Space Representation
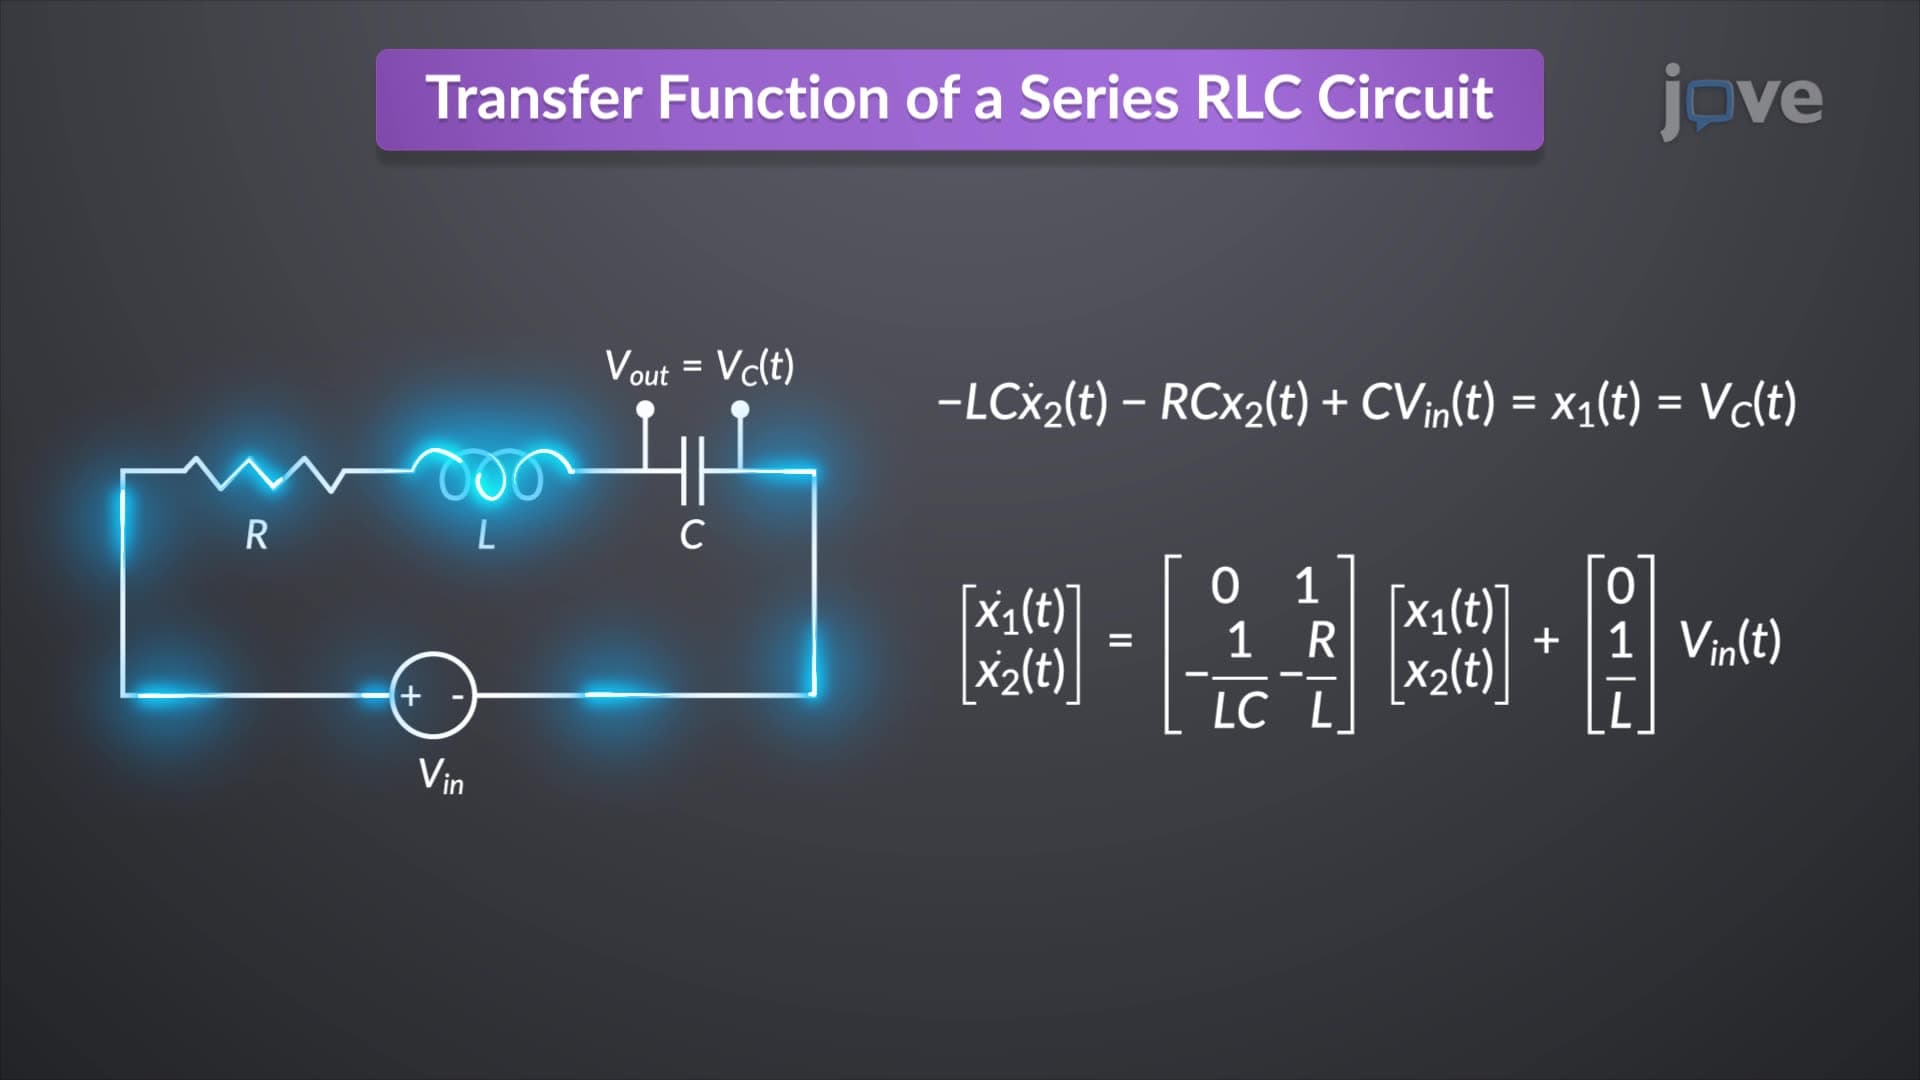
Consider an RLC circuit, a...
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:16
Basic Discrete Time Signals
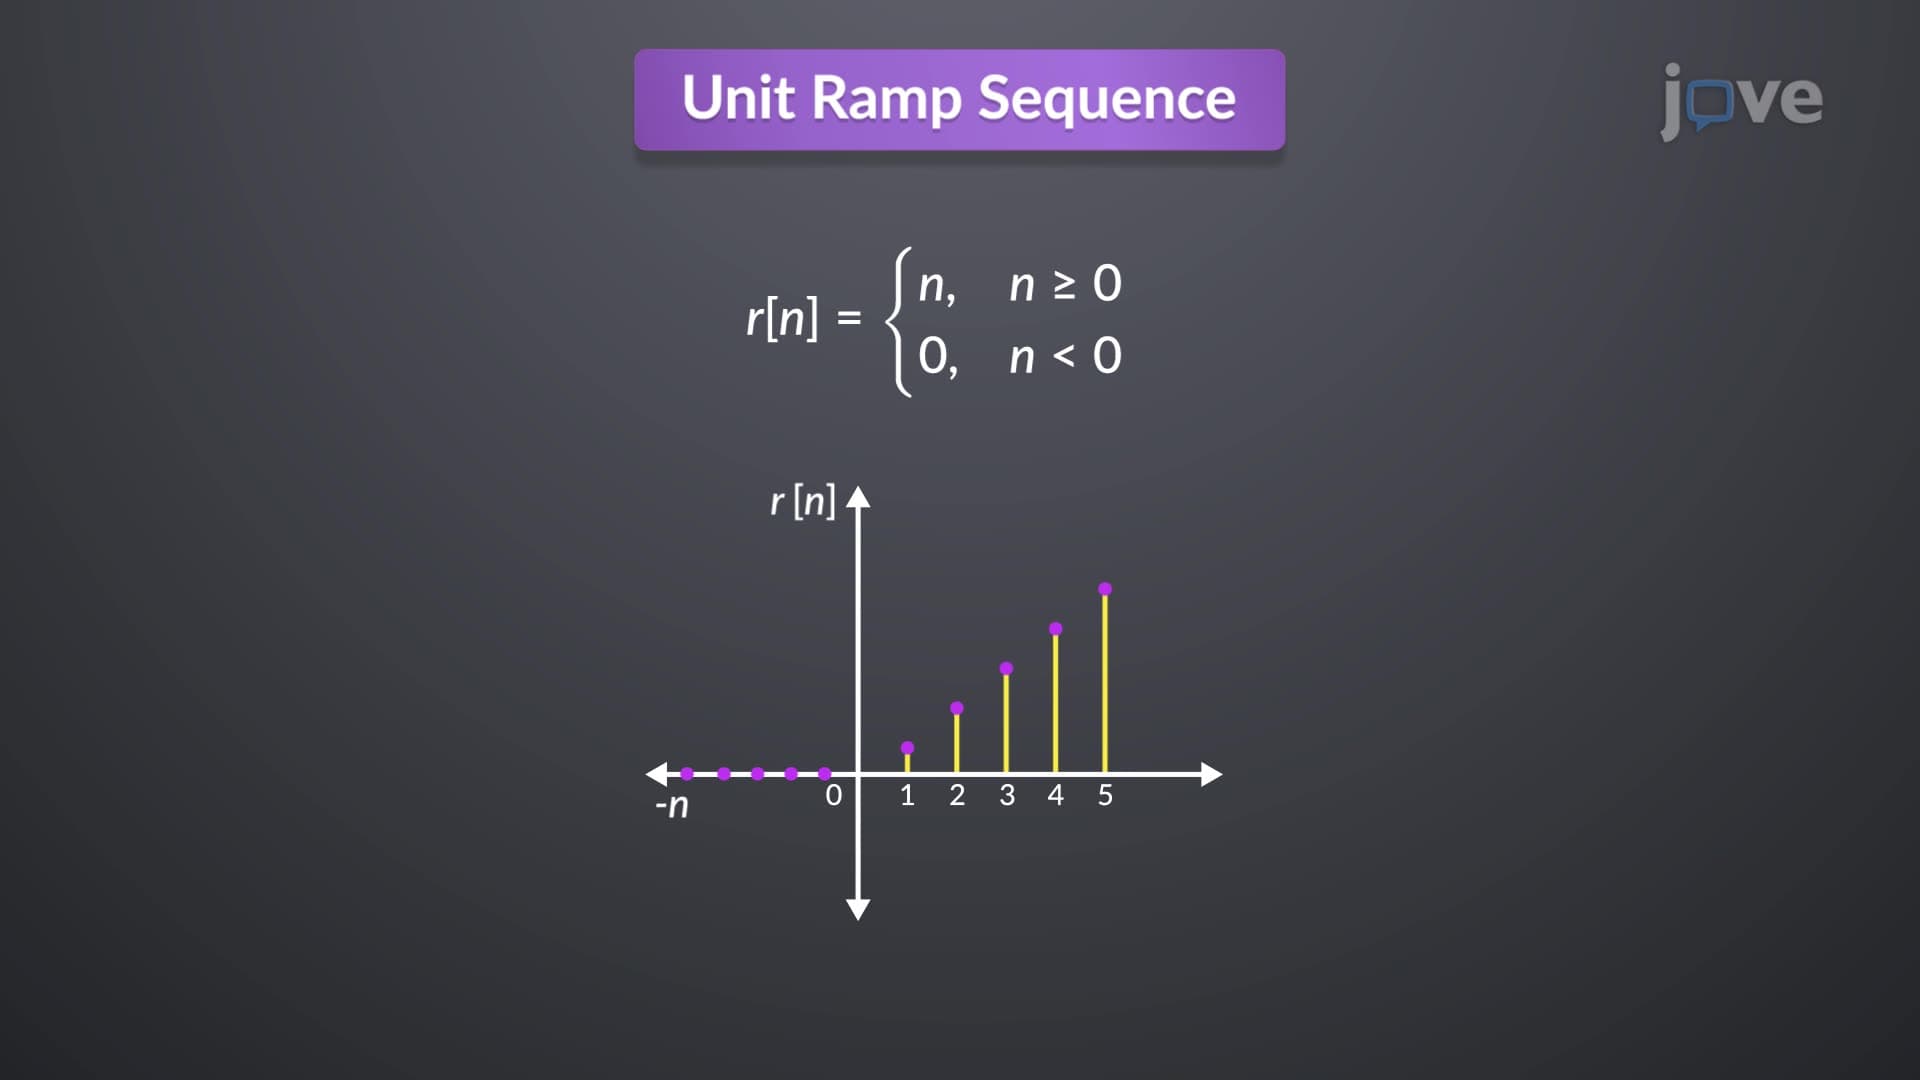
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:23
Transfer Function to State Space
In an RLC...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...