Related Experiment Video
Updated: May 23, 2026


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
A Gait Deviation Correction Method for Stable Walking With a Wearable Self-Balancing Exoskeleton Robot: A Technical

Abstract:
The study reveals that neglecting the yaw-direction rotational friction moment of the support foot in a self-balancing lower-limb exoskeleton (SBLLER) causes gait trajectory deviation. However, conventional momentum compensation strategies are unsuitable for such waistless exoskeletons designed for motor dysfunction patients. Therefore, this paper proposes a multi-level stable walking control method to reduce the yaw axis deviation and ensure the stability of the gait during the walking of the human-exoskeleton system. Firstly, a car-table based model predictive control (MPC) method is used to generate a basically stable gait trajectory; secondly, the angular momentum controllers are designed as a supplement to MPC to improve the stability of the human-exoskeleton system in the pitch and yaw directions; then, comparative experiments are conducted to verify the advantages and disadvantages of the multi-level stable walking control method in walking on flat ground and carrying users with different body feature parameters. The proposed method was tested in an exploration experiment on four healthy subjects and one stroke patient using the AutoLEE-G3 SBLLER. The results showed that the method was feasible and effective for reducing yaw axis deviations during locomotion, improving the stability of the system, and achieving robust stable walking under the specific dynamic load conditions evaluated in this technical case report.
More Related Videos
 06:00
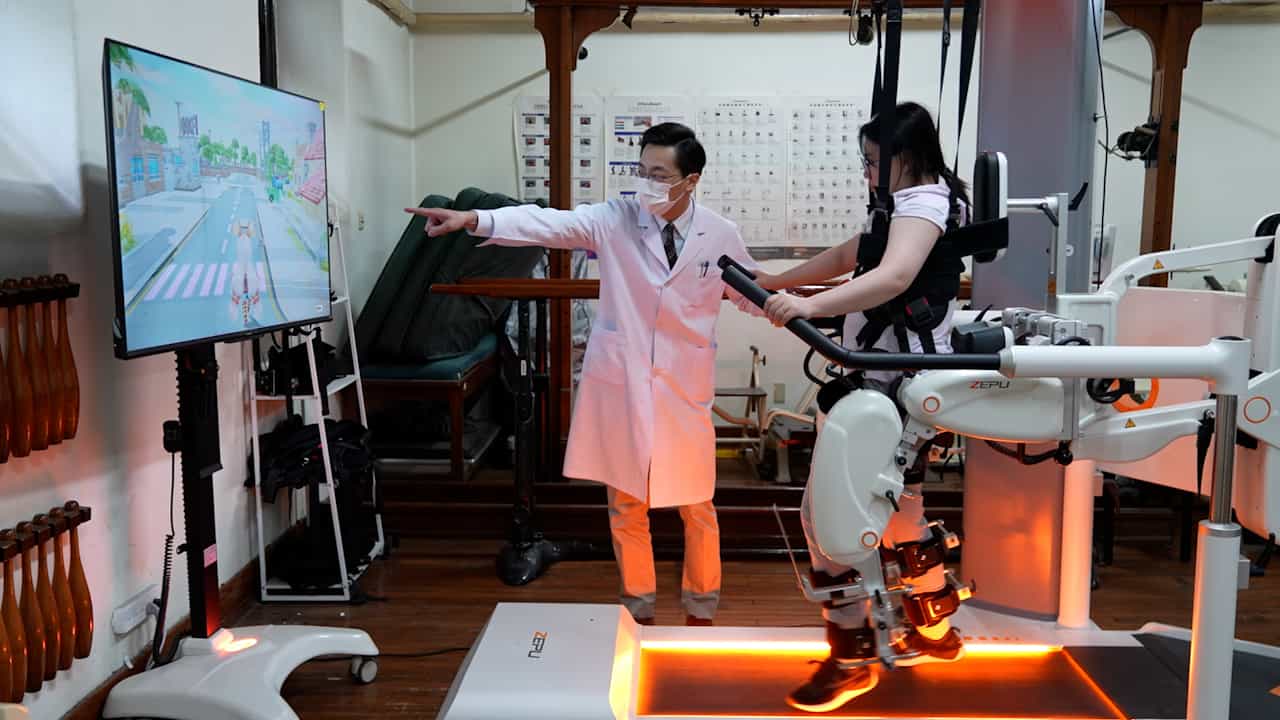
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016