Related Experiment Videos
Open-source Electronic Mass-Spring-Damper emulator with nonlinear dynamics for education and control research
Ernesto V Gonzalez-Solis1, David I Rosas-Almeida1
1Facultad de Ingeniería, Universidad Autónoma de Baja California, Mexicali, Mexico.

Abstract:
This work presents an open-source Electronic Mass-Spring-Damper (EMSD) emulator designed to reproduce the dynamic behavior of a second-order mechanical system in continuous-time and real-time operation. The proposed hardware emulates both linear dynamics and nonlinear effects commonly encountered in practical systems, such as dry friction and asymmetric dead-zone nonlinearities. The emulator is realized using analog processing blocks that solve the associated nonlinear differential equation, avoiding numerical discretization and digital computation. Equivalent physical parameters such as mass, damping, stiffness, and nonlinear characteristics are adjusted through user-accessible front panel controls, enabling intuitive interaction and rapid reconfiguration. The EMSD emulator provides analog input and output signals, allowing straightforward integration with external controllers, data acquisition systems, and hardware-in-the-loop (HIL) applications. Complete design files, build instructions, and documentation are provided to support reproducibility. The proposed platform offers a compact, low-cost, and transparent solution for hands-on education and experimental research in system dynamics and control, bridging the gap between numerical simulations and physical mechanical prototypes.
Related Concept Videos
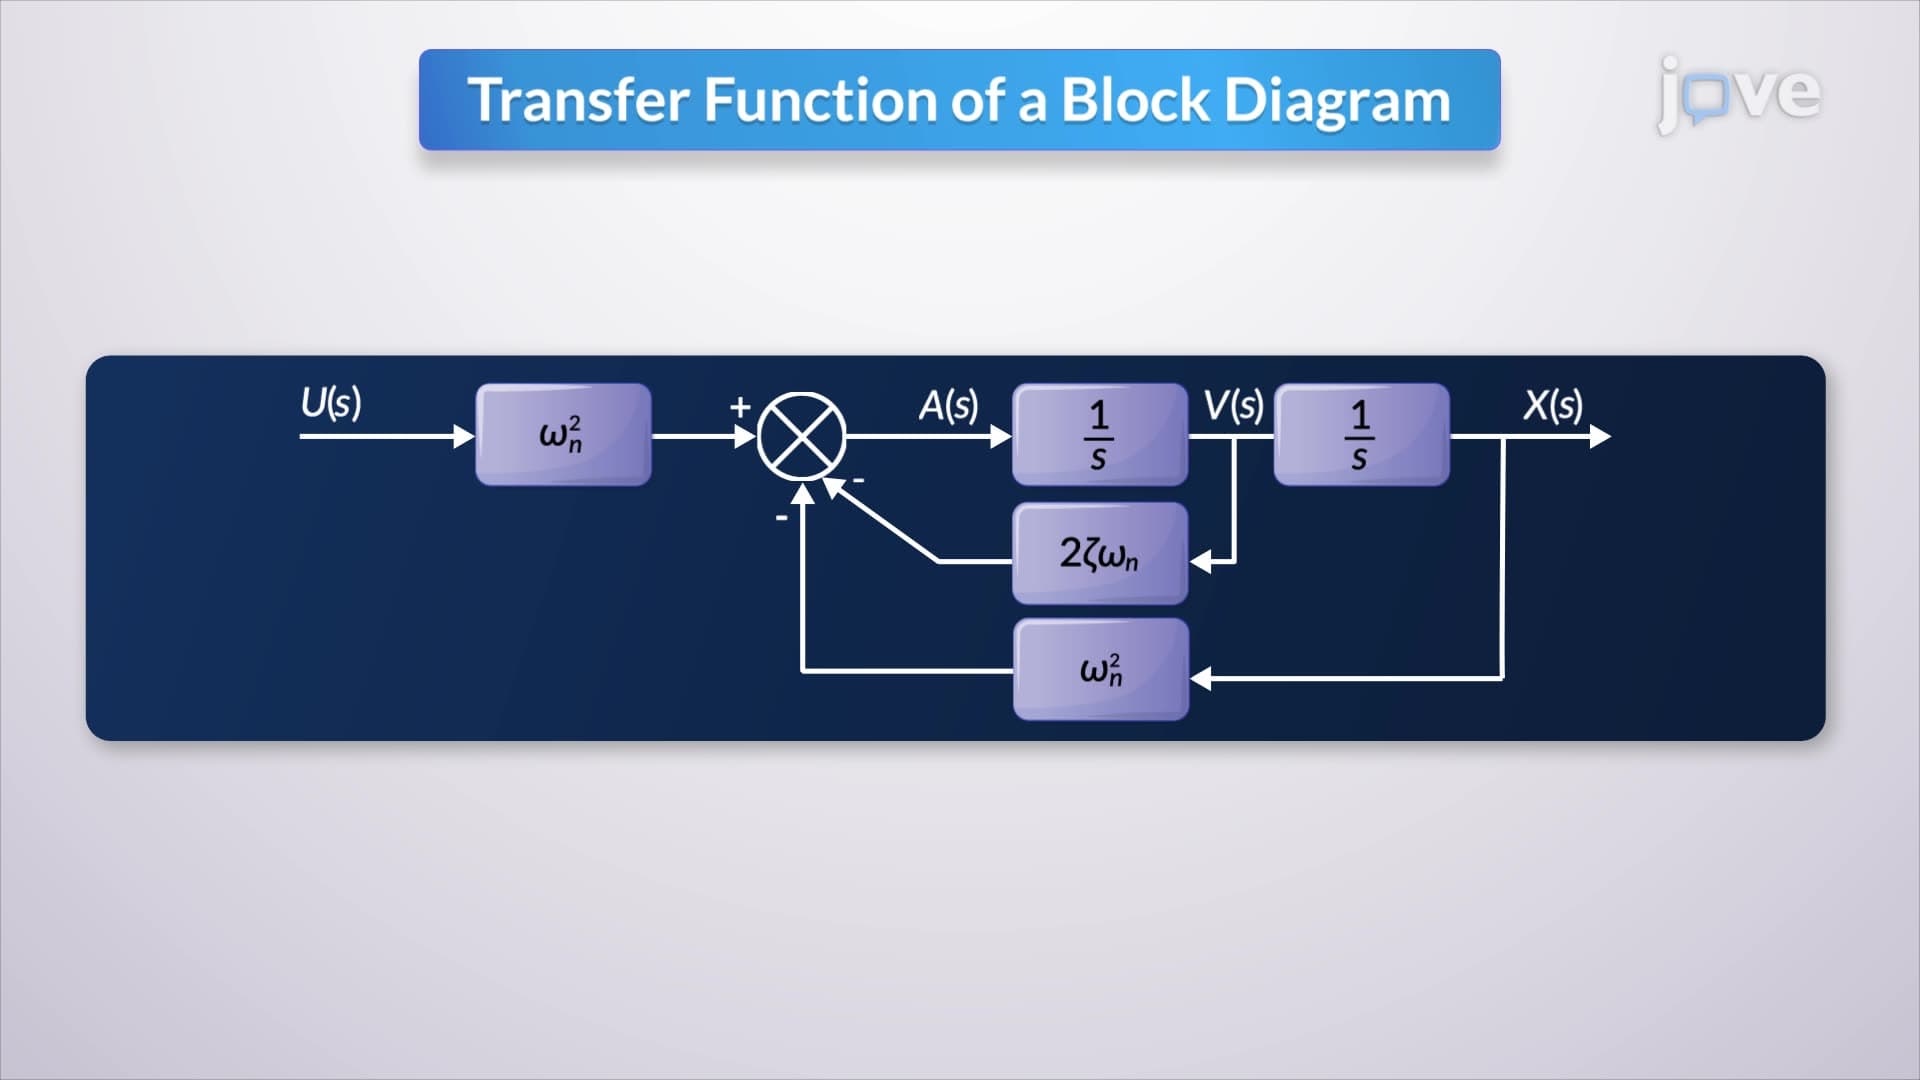 01:20
Relation between Mathematical Equations and Block Diagrams
 01:22
Mechanical Systems
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
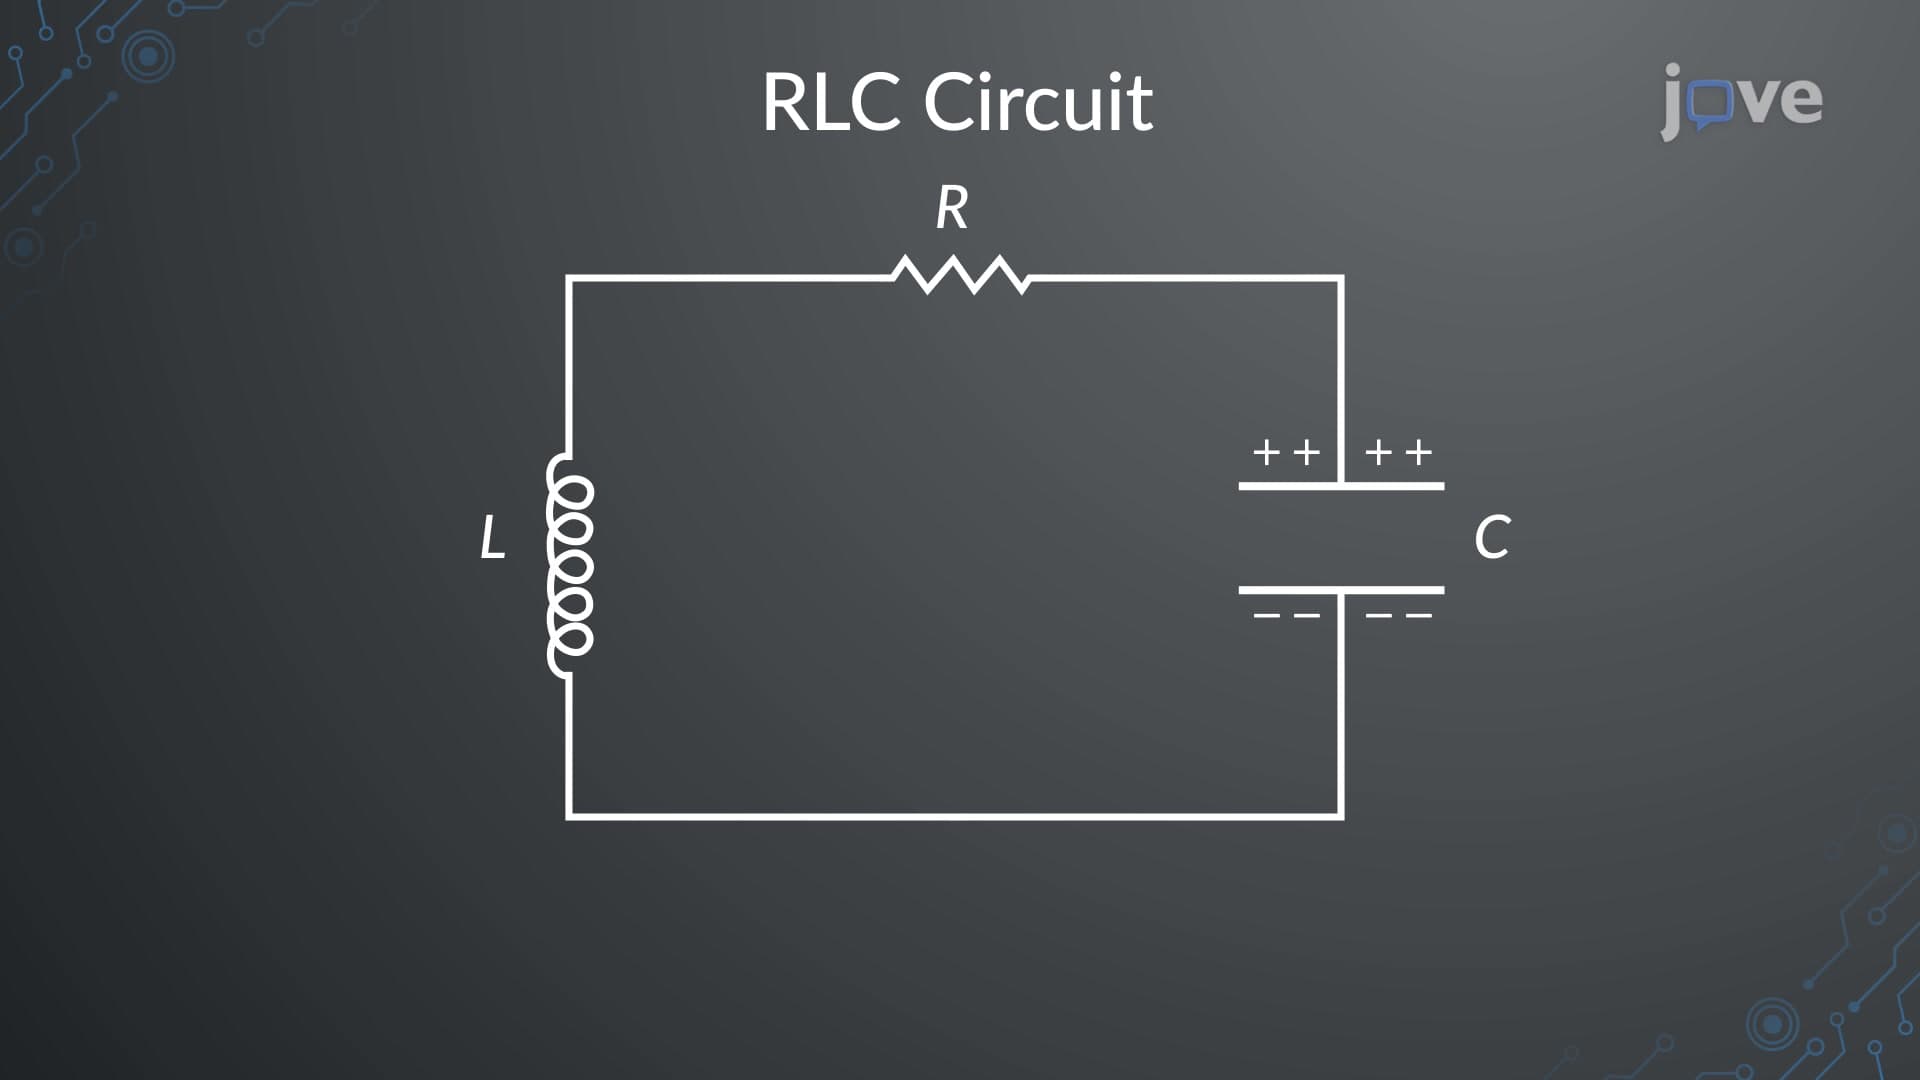 01:30
RLC Series Circuits