Related Experiment Video
Updated: May 28, 2026

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Monocular Visual Pose Estimation Method Based on Spherical Cooperative Target
Yanyu Ding1,2, Chaoran Zhang1,2, Yongbin Zhang3
1School of Mechanical Engineering, Tianjin University of Science and Technology, Tianjin 300457, China.

Abstract:
In close-range monocular visual measurement and cooperative target pose estimation, conventional planar targets are constrained by viewpoint changes and are prone to perspective distortion. Although spherical targets provide omnidirectional observability, their PnP-based pose estimation may still suffer from large errors under limited fields of view and sparse feature observations. To address this issue, this paper proposes an integrated visual measurement framework covering both high-precision spherical target construction and robust pose estimation. First, a composite marker layout based on adaptively scaled latitude-longitude topology is designed. To suppress cumulative distortion caused by long-sequence multi-view rigid registration, a center-to-pole point-cloud stitching strategy is developed, and multiple observations are fused using geometric-consistency weighting to accurately reconstruct the feature-point coordinate system of the target. Second, a joint optimization method is proposed by combining feature-point reprojection error with a contour center consistency constraint. Specifically, the theoretical contour center is predicted from the analytical projection model of the sphere and constrained to agree with the observed contour center fitted from the image. In addition, an SQPnP-based sequential reinitialization mechanism is introduced to improve robustness under sparse-point observations. Simulation results demonstrate that the proposed method achieves higher accuracy and robustness under continuous pose changes, sparse feature points, and different noise levels, compared with EPnP, EPnP+LM, LM, and SQPnP, while real-image experiments further demonstrate its practical feasibility.
Related Concept Videos
 01:23
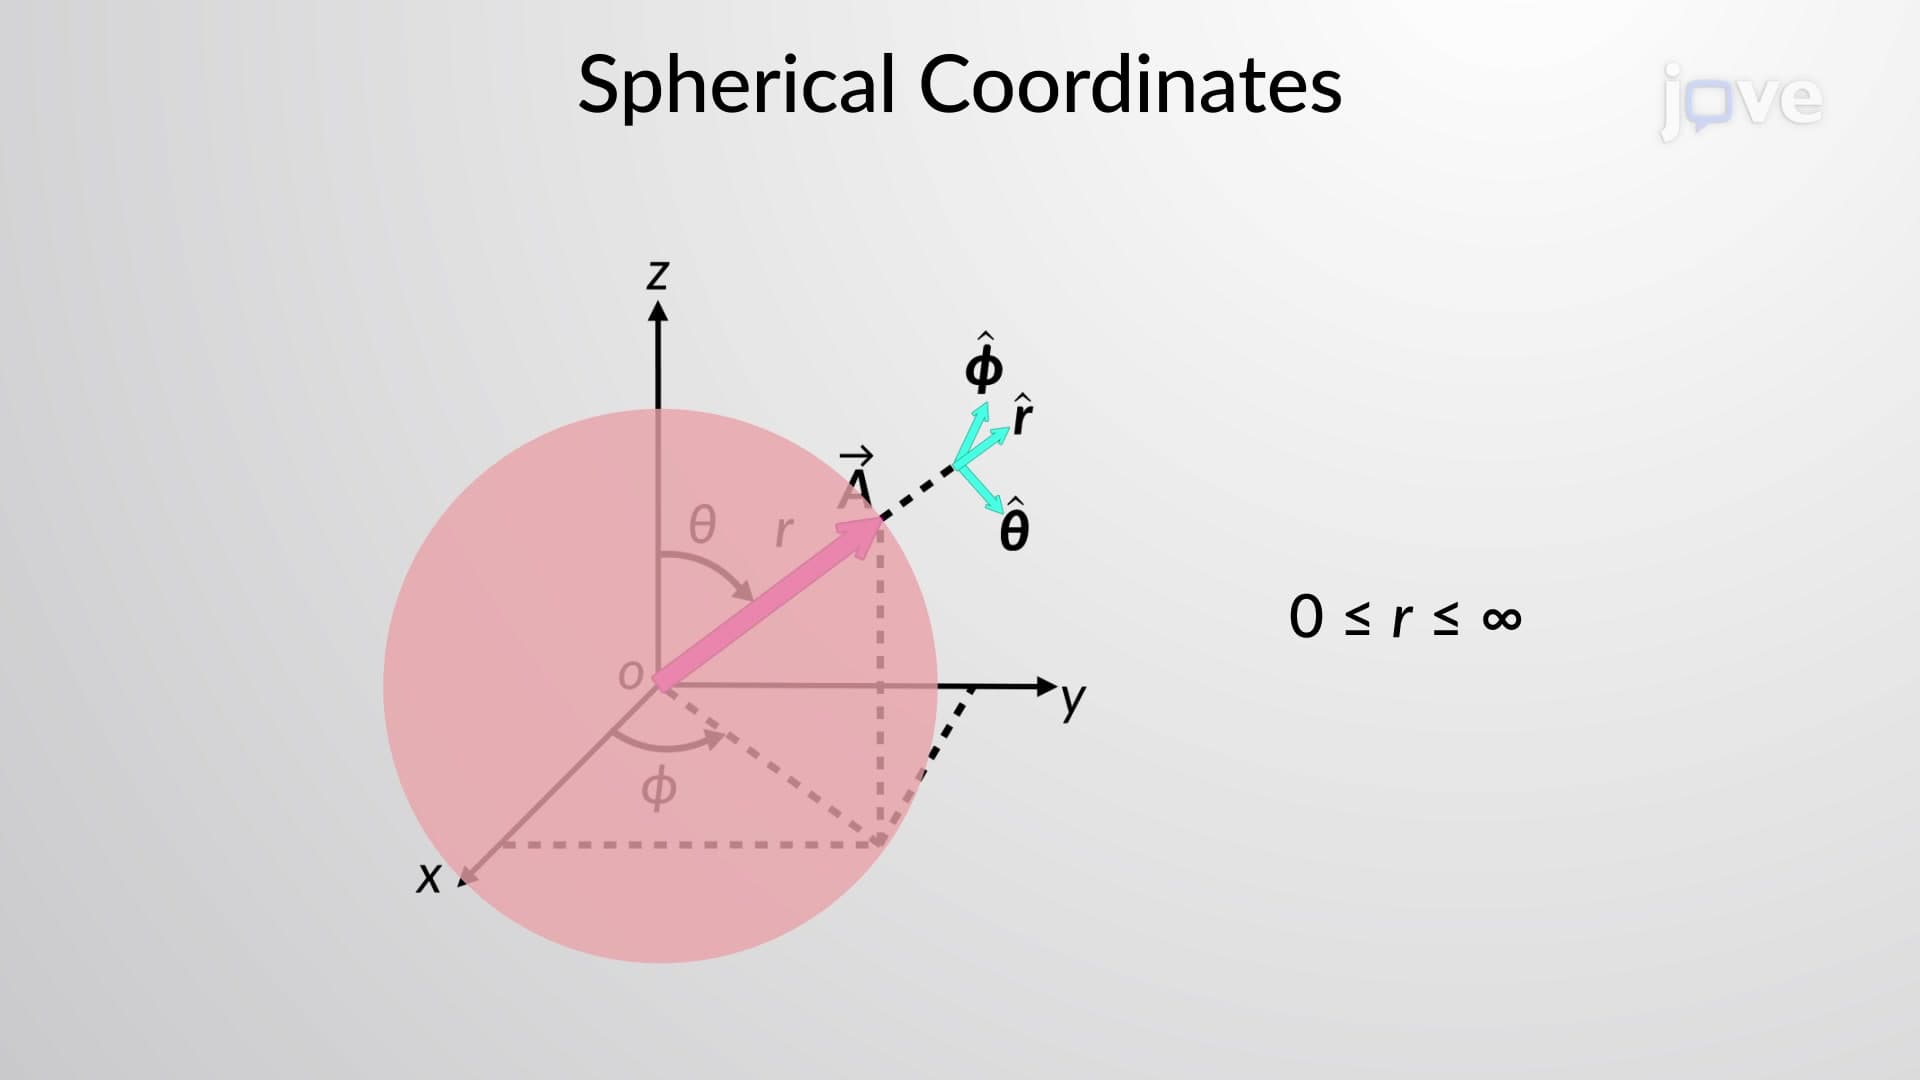
Spherical Coordinates
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...