Related Experiment Video
Updated: May 31, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Double-leg exoskeleton for rehabilitation: Design, optimization, and implementation
Hasan Eleashy1, Hashem A Bukhary2, Khalid M Alhomayani2
1Mechanical Engineering Department, Faculty of Engineering & Technology, Future University in Egypt, Cairo, Egypt.

Abstract:
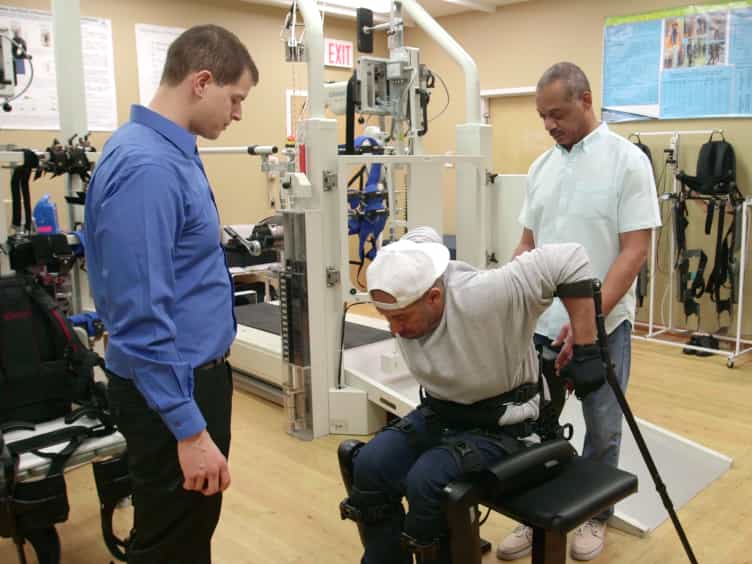
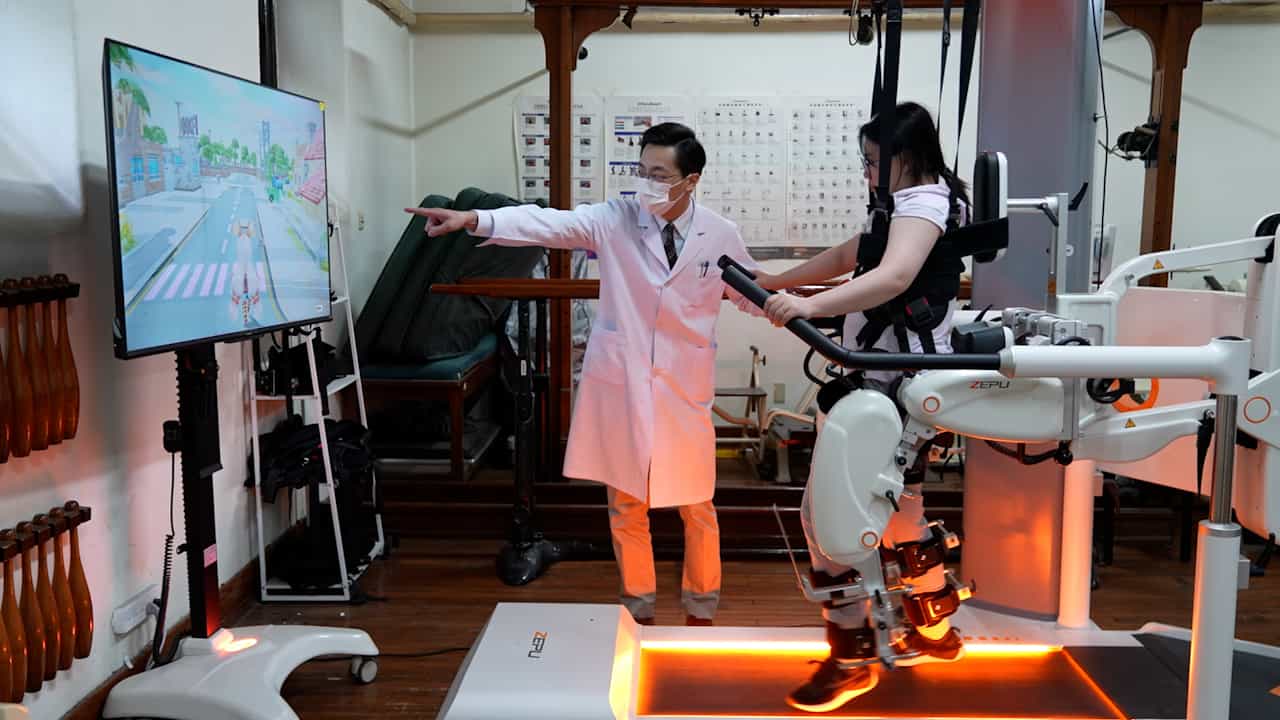
Rehabilitation exoskeletons is still an important issue to improve walking functionality and speed up treatment for patient to restore their lives faster. This paper introduces a controlled lightweight exoskeleton for lower limb rehabilitation with a friendly user interface. A model for the proposed exoskeleton design is initially developed using SolidWorks. Secondly, an optimization study is presented to minimize the total mass. Simulink model is established for the proposed exoskeleton to simulate the gait cycle. Then, a prototype is implemented using light weight material. An integrated control system based on active actuators at both hip and knee joints is presented. A simple user interface is designed to control the movements of hip and knee joints. Finally, an experimental test is performed to validate simulated data of human gait cycle for torque and angle profiles of hip and knee joints.