Related Experiment Video
Updated: Jun 6, 2026
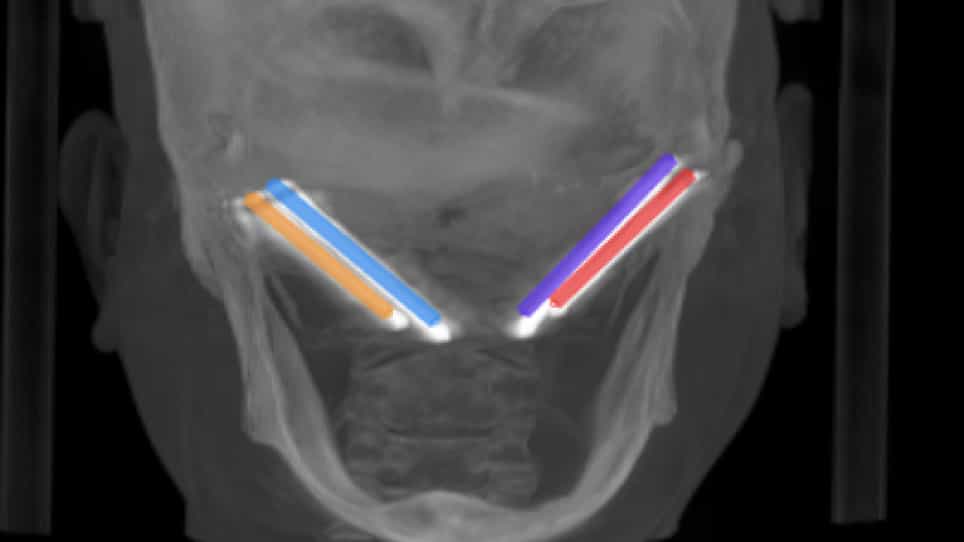

Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
Accuracy assessment of a fully autonomous robotic system for zygomatic implant placement: An in vitro study
Nhan Van Vo1, Khang Gia Tran Vo2
1Nhan Tam Dental Clinic, 807 3/2 Street, Dien Hong Ward, Ho Chi Minh City, Vietnam; Hong Bang International University, 215 Dien Bien Phu Street, Gia Dinh Ward, Ho Chi Minh City, Vietnam.

Objectives:
This study aimed to evaluate the accuracy of zygomatic implant (ZI) placement using a fully autonomous robotic system and to compare accuracy between implant sides (right versus left) and between implant position in the first premolar region (#14 and #24) and the first molar region (#16 and #26).
Methods:
An in vitro study was conducted to evaluate the accuracy of ZI placement using a fully autonomous robotic system (Yakebot; Beijing YaKebot Technology Co., Ltd., Beijing, China). Ten edentulous maxillary resin models, all fabricated from the same patient's data, were used in this study. Each model received four ZIs at positions #14, #16, #24, and #26, for a total of 40 ZIs. Cracks occurred at eight sites during ZI placement; consequently, only 32 ZIs were included in the final analysis.
Results:
Most ZIs showed deviations <1.5 mm at the neck (90.6%) and apex (68.8%), and <1.5° in angulation (68.8%). Regarding apex depth deviation, 62.5% of ZIs demonstrated deviations ranging from 0.0 to <1.5 mm. The mean neck, apex, angular, and apex depth deviations were 0.87 ± 0.49 mm, 1.26 ± 0.42 mm, 1.22 ± 0.50°, and 0.06 ± 0.65 mm, respectively. Angular deviation and apex depth deviation differed significantly between implant positions (p < 0.05).
Conclusions:
This in vitro investigation indicates that the fully autonomous robotic system can achieve high accuracy in ZI placement, as reflected by the mean neck, apex, angular, and apex depth deviations.