Related Experiment Video
Updated: Jun 6, 2026
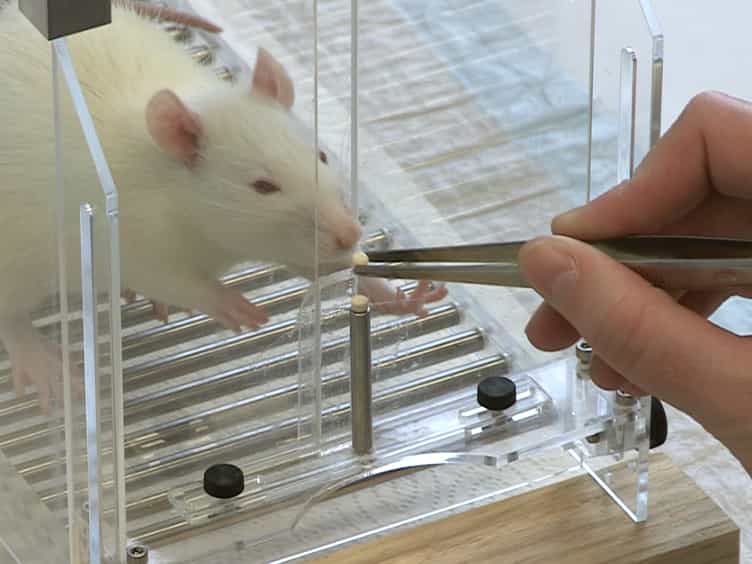

Acquisition of a High-precision Skilled Forelimb Reaching Task in Rats
Published on: June 22, 2015
A paradigm for skilled forelimb reaching by head-restrained mice
Annabel Chang1,2, Adithya Madduri3, Janet Berrios Wallace2
1Eaton-Peabody Laboratories, Massachusetts Eye and Ear, Boston, MA, USA.

Abstract:
Forelimb reaching tasks are widely used in neuroscience across species. In mice, pellet reaching is especially useful because it requires fine motor control. However, few automated pellet-delivery systems are well suited for head-restrained reaching, where pellet position must be highly consistent. Here we present a complete pipeline for head-restrained, or head-fixed, forelimb reaching in mice. The pipeline includes a simple customizable pellet-presentation rig, an effective training protocol, and analysis code to detect reaches and classify their outcomes. To demonstrate pipeline utility, we quantified interruption of an ongoing reach. The temporal requirement for initiating cancellation was dependent on the phase of the reach, lengthening significantly as the reach neared completion. These results show that the pipeline can resolve fine phase-dependent features of skilled behavior and provide a practical framework for studying motor control in head-restrained mice.