Related Experiment Video
Updated: Jun 7, 2026
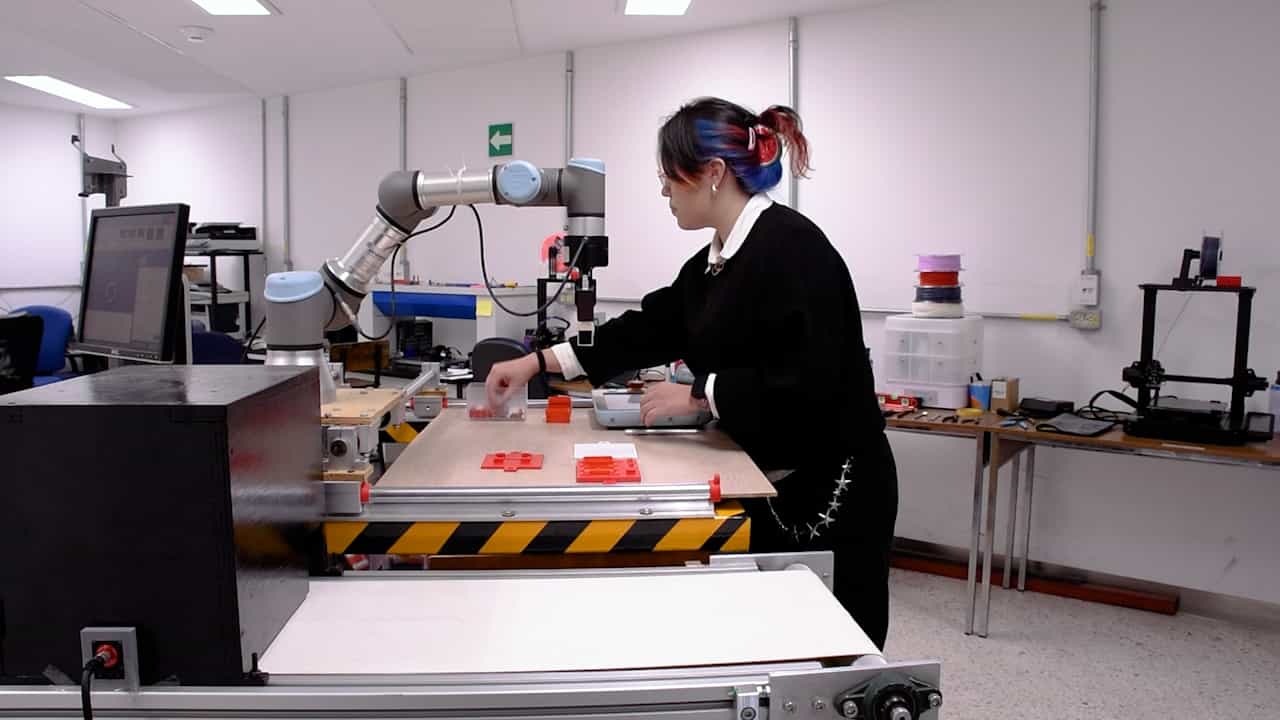

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Human-automation interaction shapes safety performance across automation levels in safety-critical scenarios
Detong Qin1, Jiajie Shen2, Zijian He2
1State Key Laboratory of Intelligent Vehicle Safety Technology, Chongqing 401122, China; School of Vehicle and Mobility, Tsinghua University, Beijing 100084, China.

Abstract:
Automated driving is widely expected to improve road safety, yet its realized safety performance in safety-critical scenarios remains uncertain because outcomes depend not only on system capability, but also on how drivers perceive risk, intervene, and interact with automation. This study establishes a unified driver-in-the-loop experimental framework for evaluating safety performance under human-automation interaction across multiple automation levels. Using high-fidelity driving simulator experiments covering representative safety-critical scenarios and SAE Levels 2-4, we collected a large-scale dataset of driver-automation interactions and safety outcomes. The results show that realized safety in safety-critical events is jointly shaped by automation capability and driver intervention behavior. As automation capability increased, driver intervention became less frequent and generally later, while overall safety performance improved. At the same time, a different cross-level regularity emerged among cases involving driver intervention: under the present experimental conditions, the collision risk conditional on intervention remained at a relatively stable non-zero level (approximately 26%), and both the intervention-onset risk state and the controllability boundary showed broadly similar patterns across levels. These findings indicate that automation level mainly changes whether and when drivers intervene, while the risk state at intervention onset and the overall effectiveness pattern of intervention remain broadly stable across levels. Model-based validation further showed that collision risk is primarily associated with the driver's risk state at intervention onset and response latency. Overall, this study identifies a cross-level regularity in driver-automation interaction during safety-critical events and provides a driver-centered basis for understanding takeover limits and intervention-conditioned collision risk, with implications for the human-centered evaluation and design of safer automated driving systems.
Related Concept Videos
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The direction...
 01:10
Control Systems
At the heart...
 01:25
Distribution Reliability and Automation
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 02:16
Stereotype Content Model
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...