Related Experiment Video
Updated: Jun 11, 2026
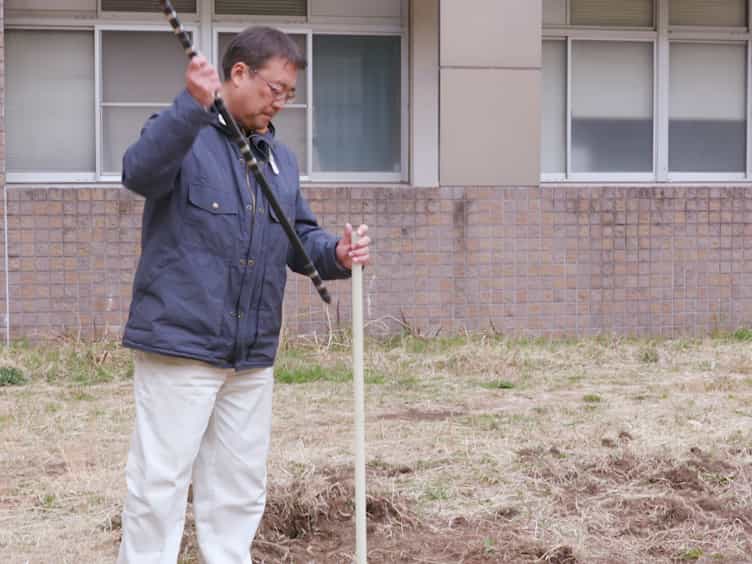

Tracking Infiltration Front Depth Using Time-lapse Multi-offset Gathers Collected with Array Antenna Ground Penetrating Radar
Published on: May 1, 2018
GM-APD LiDAR target detection method based on trigger probability interval difference

Abstract:
To address weak echo submergence in GM-APD LiDAR under strong background light, a detection method based on trigger probability gradient statistics is proposed. Based on Poisson statistics, an interval difference operator is constructed to transform non-uniform noise into a zero-mean stationary process. A 30% overlapping stepping gating strategy is incorporated to enhance transient responses and compensate for dead-time attenuation. Results show that at a signal-to-background ratio of 0.1, the method achieves a 93.5% detection probability with a false-alarm rate below 1%. Field tests at 1060 m yield a localization error within 0.6 m, confirming its sub-meter precision.
Related Concept Videos
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:19
Gas Chromatography: Types of Detectors-II