Related Experiment Video
Updated: Jun 12, 2026
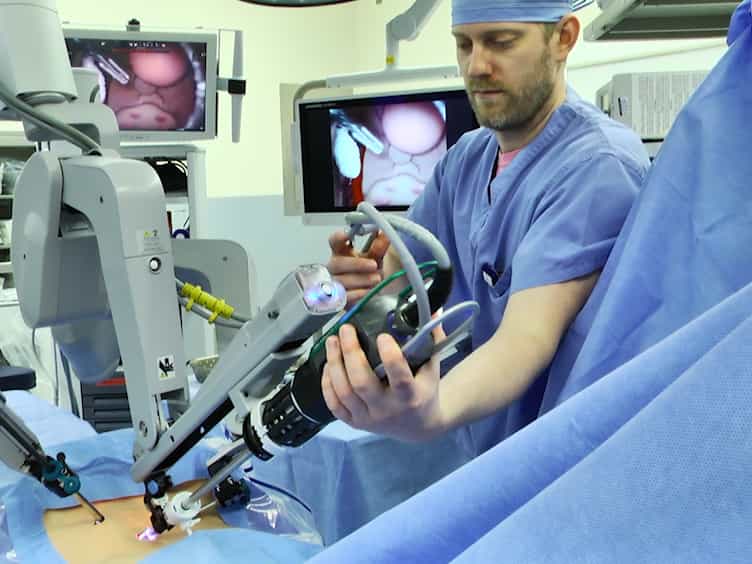

Emergency Undocking in Robotic Surgery: A Simulation Curriculum
Published on: May 20, 2018
Evaluating robotic surgery skills decay and maintenance of proficiency in a high-fidelity simulated environment
Ricardo E Nunez-Rocha1, Samy Castillo-Flores1, Andres A Abreu1
1Department of Surgery, The University of Texas Southwestern Medical Center, 5323 Harry Hines Boulevard, Dallas, TX, 75390, USA.

Introduction:
Skill retention and decay are critical in robotic surgical simulation training. While performance decay has been studied in virtual reality platforms, its effects in high-fidelity biotissue drills remain underexplored. We evaluated both the impact of training breaks and the benefits of continued practice beyond proficiency among general surgery residents performing simulated robotic bowel anastomoses.
Methods:
This retrospective study analyzed 132 h of robotic simulation from 45 residents who reached proficiency (OSATS ≥ 28) on a high-fidelity bowel anastomosis drill. Two cohorts were included: a skill decay group (n = 30) who returned ≥ 1 month after achieving proficiency, and a continued training group (n = 15) who completed ≥ 3 additional sessions post-proficiency. OSATS scores and task times were compared between initial and follow-up sessions. Skill decay was defined as a ≥ 2-point OSATS drop or ≥ 6-min time increase. Statistical tests included paired comparisons, ROC analysis, and multivariable logistic regression.
Results:
In the skill decay group, the median interval was 91 days (IQR 63-134). Task time increased from 30.5 to 34.5 min (p = 0.03), while OSATS declined from 30 to 28 (p = 0.001). By 6 months, OSATS scores dropped 17.6% and time worsened 19.3%. ROC curves identified 84 days (AUC 0.76) for technical decay and 188 days (AUC 0.89) for efficiency loss. Higher baseline OSATS predicted decline (OR 2.72; p = 0.02). In the continued training group, OSATS improved from 29.5 to 34 (p < 0.001), and task time decreased from 30.5 to 25.5 min (p = 0.01).
Conclusion:
Robotic simulation performance deteriorates within 3-6 months of inactivity. Conversely, continued deliberate practice beyond proficiency yields measurable gains. Structured refreshers near the 3-month mark and extended practice should be integrated into robotic curricula to sustain readiness.