Related Experiment Video
Updated: Jun 12, 2026
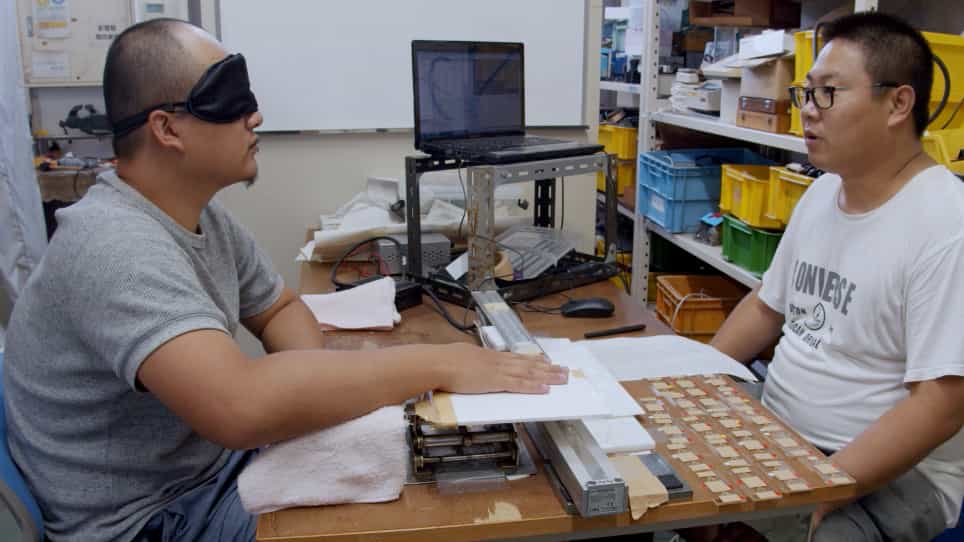

Tactile Semiautomatic Passive-Finger Angle Stimulator (TSPAS)
Published on: July 30, 2020
Tactile sensing artificial finger skin: equivalent multi-round dense sampling training strategy for network

Abstract:
Optical fiber-based tactile sensing using fiber Bragg grating (FBG) arrays features compact structure, high robustness, and intrinsic immunity to electromagnetic interference, which makes it suitable for artificial finger skin in robotic systems. In practice, data-driven demodulation models usually rely on multi-round dense calibration to obtain sufficient training diversity, increasing calibration time and experimental workload. This work presents an equivalent multi-round dense sampling training strategy (EMRDS-TS) for FBG-based tactile sensing. The strategy reconstructs training diversity from single-round sparse measurements by combining a physically constrained deterministic trend model with a conditional generative adversarial network. The trend model describes the monotonic and quadratic wavelength response of the embedded FBG array with respect to pressing position and applied force. The generative module models residual variations related to channel nonuniformity and structural factors. Based on the reconstructed dataset, a coordinate attention-based haptic perception demodulation network (CA-HPDNet) is trained for simultaneous position and force estimation. Experimental results on Sample 1 show that EMRDS-TS achieves performance comparable to eight-to-twelve-round dense sampling. For position prediction over 0-30 mm, the mean absolute error (MAE) of 0.4228 mm and the R2 of 0.9790 are obtained. For force demodulation over 0-9.81 N, the MAE is 0.2265 N with the R2 of 0.9749. To further evaluate the proposed strategy, a second sample with an identical structural configuration was investigated. Comparable demodulation accuracy was obtained, and the equivalent multi-round dense sampling effect was consistently reproduced.
Related Concept Videos
 01:23
Design Example
 01:33
Somatosensation