Related Experiment Video
Updated: Jun 16, 2026
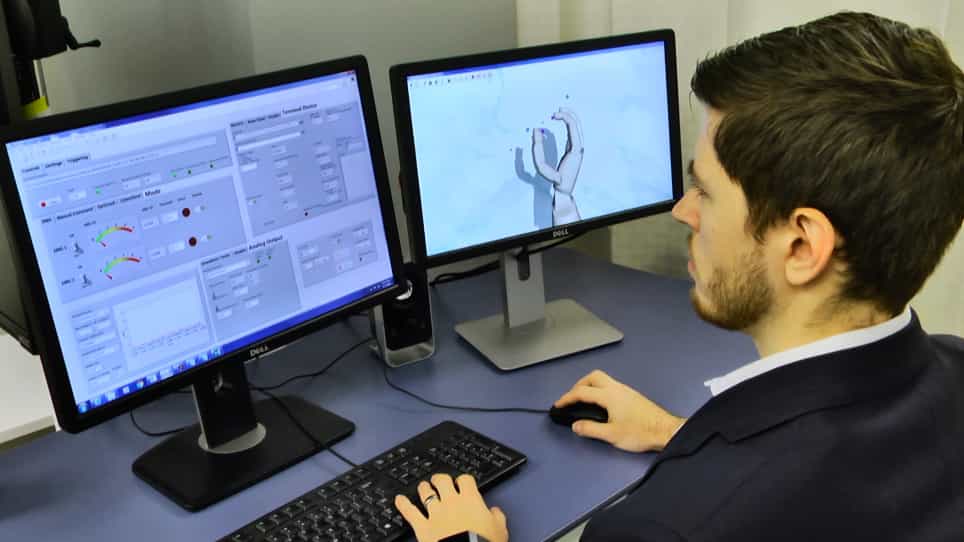

Characterization of the Sense of Agency over the Actions of Neural-machine Interface-operated Prostheses
Published on: January 7, 2019
Qualia as control-theoretic constructs for autonomous agents: event phase space as an action-oriented semantic safety
1Research Computing Center, Lomonosov Moscow State University, Moscow, Russia.

Abstract:
Autonomous systems face a fundamental complexity barrier in open-world environments: decomposing scenes into discrete entities and searching over combinatorial action spaces leads to prohibitive computational costs, yet biological agents navigate equivalent environments in real time through holistic situational assessments - states that the phenomenological tradition terms qualia. This paper argues the gap is architectural and introduces three contributions. First, we propose that qualia are operationally indicated by assessment structures characterized by geometric coherence on a manifold, multimodality, joint encoding of state and rate, action-readiness, and intrinsic predictive content, when instantiated in an AI entity satisfying explicit subsistence and non-identity conditions. Second, we introduce the event phase space: a differentiable manifold of substantially reduced dimensionality compared to World Models, endowed with learned dynamics in which safe modes correspond to stable attractors and safety boundaries to separatrices, thereby replacing combinatorial search with gradient navigation at O(n) complexity. Third, the theoretical model is transferred to a standard industry benchmark through validation in CARLA Parked Vehicle Occlusion scenarios (1,000 episodes per controller, 5 seeds), where an alarm function derived purely from the learned vector field achieves AUC = 0.812 and reduces the collision rate by 29.6% in stress scenarios (p = 0.0034), outperforming TTC-based pipelines by 60× while operating at 1.9 ms/decision on CPU with only 6,550 parameters - substantially fewer than comparable latent-CBF methods.

Related Concept Videos
 01:27
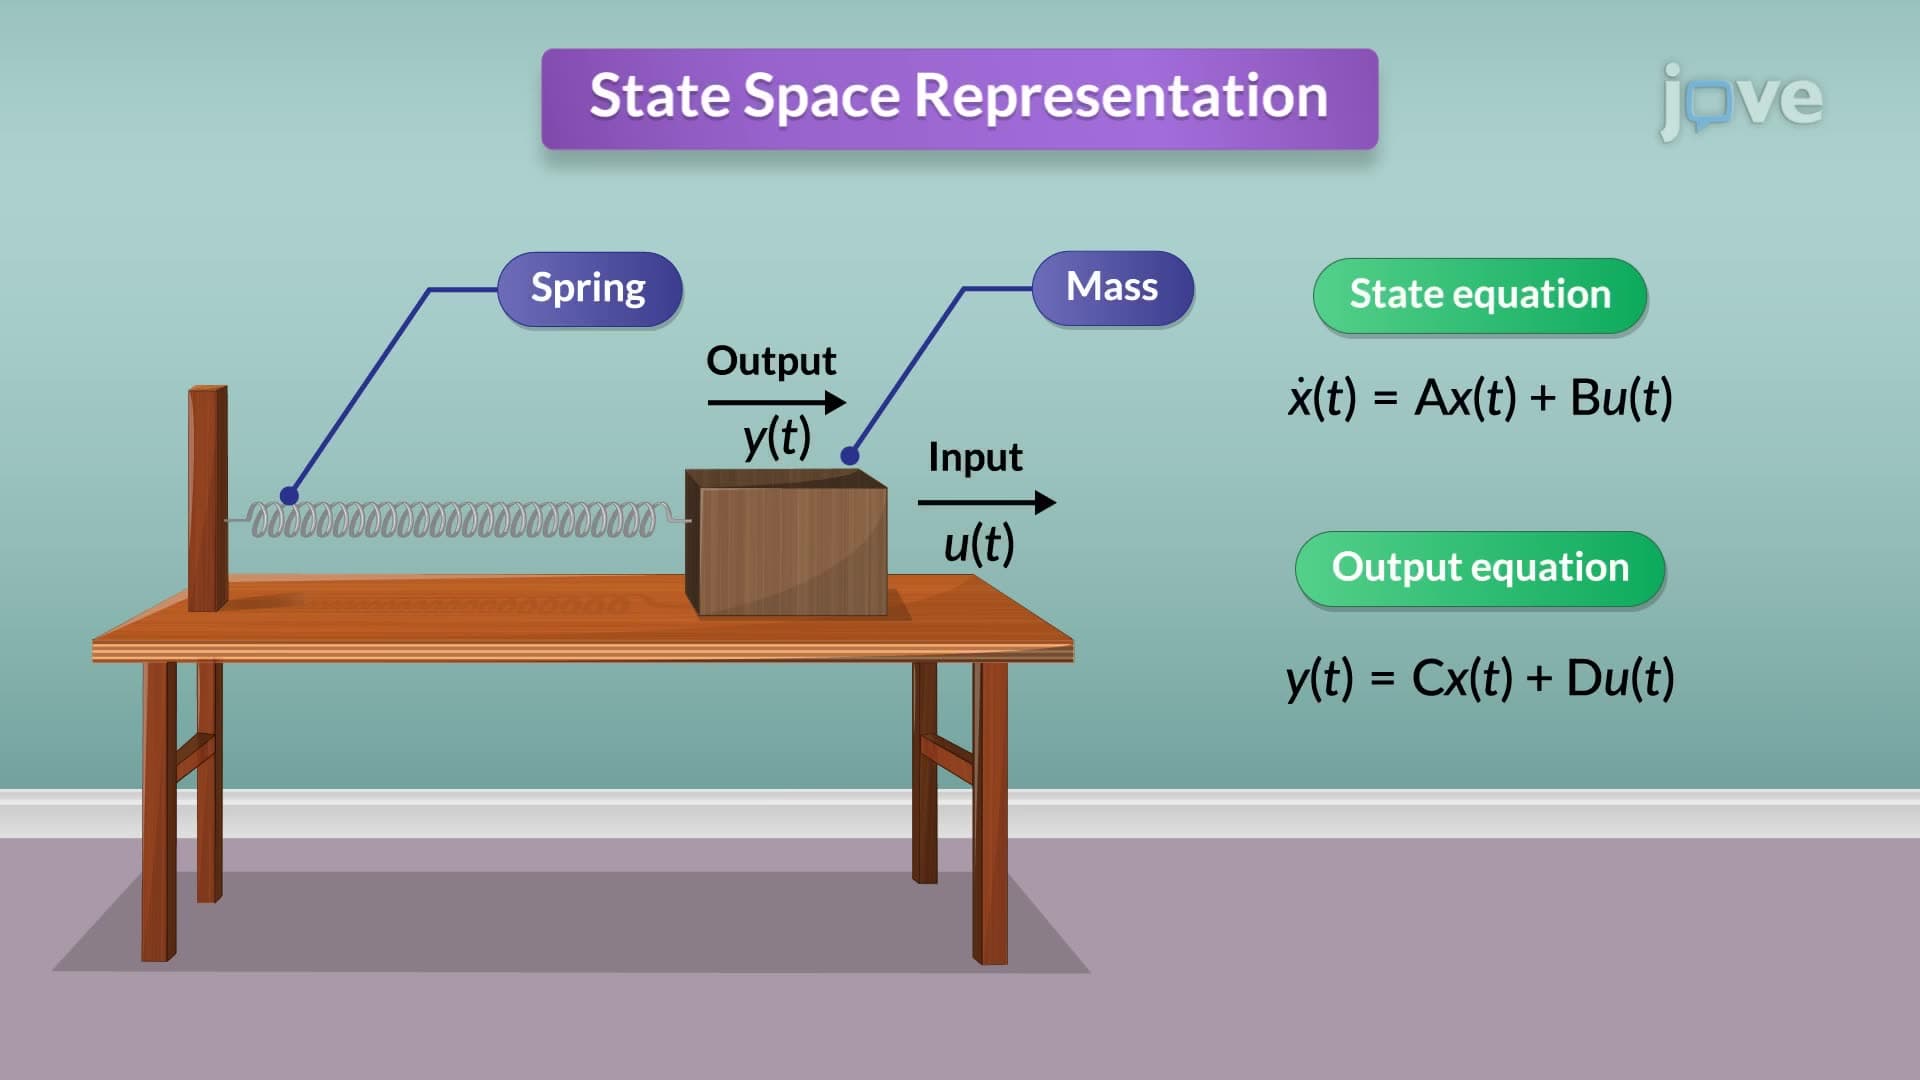
State Space Representation
Consider an RLC circuit, a...
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:28
Automatic Processing and Automatic Social Behavior
 01:29
Real-World Applications of Space Curves
 01:26
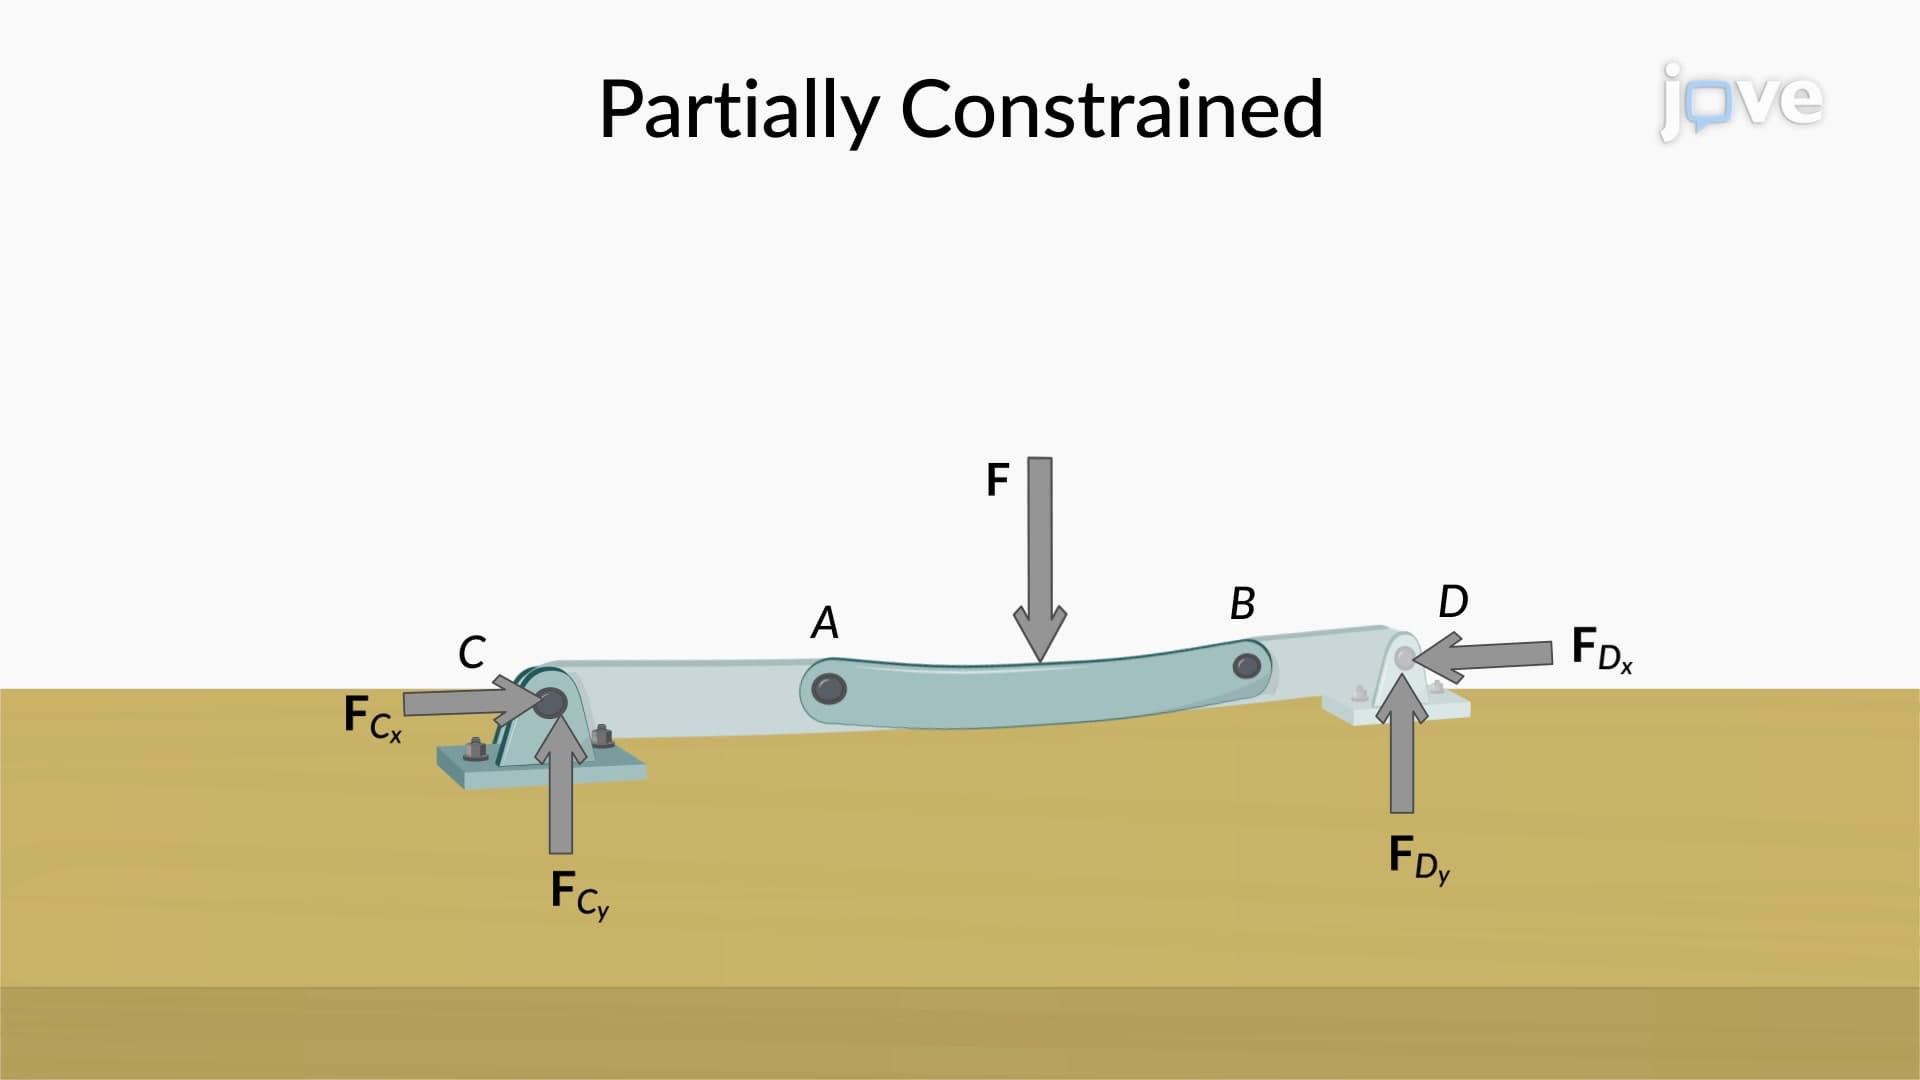
Constraints and Statical Determinacy
 01:16
Statically Indeterminate Problem Solving