Related Experiment Video
Updated: Jun 17, 2026


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Preparations reduce drivers' perceived risk when resuming control from conditionally automated vehicles
Hengyan Pan1, Amanda Stephens2, Zhiguo Zhao1
1Faculty of Transportation Engineering, Huai'an University, Huai'an, China.

Objective:
During conditionally automated driving, an unexpected vehicle control transfer increases a driver's perceived risk and negatively impacts their subsequent driving behavior. Monitoring requests (MRs) that occur before takeover requests (TORs) have been shown to enhance takeover performance. However, whether this also influences a driver's perceived risk is not clear. This study aimed to examine the effect of MRs on drivers' perceived risk, investigate whether their physiological indicators can predict perceived risk, and explore the association between perceived risk and takeover performance.
Method:
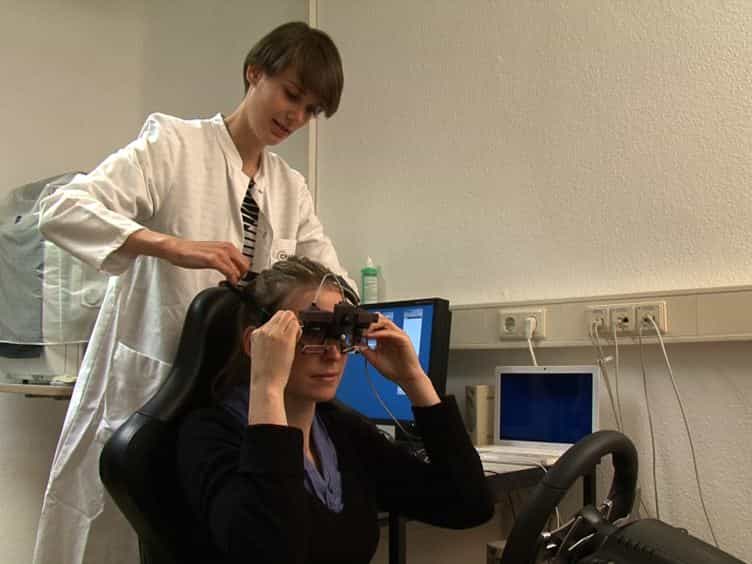
Sixty participants (mean age = 28.1, SD = 5.0; gender = 46.7% men, 53.3% women) were randomly distributed into two groups and completed a simulated automated driving experiment. One group experienced MRs, followed by TORs (MRs + TORs), while the other group experienced TORs only (TORs-only). Both groups experienced two takeover scenarios during which their perceived risk, physiological indicators (including eye-movement-related indicators, heart rate, skin conductance level, and respiration frequency) and takeover performance (including maximal braking pedal input [0-1] and maximal steering wheel velocity [rad/s]) were collected. Additionally, participants' self-reported perceived risk, on an 11-point Likert scale, regarding the takeover scenarios was also recorded. A random forest model was applied to predict perceived risk using drivers' pre- and post-TOR physiological indicators as input features.
Results:
Compared to drivers in the TORs-only group, drivers in the MRs + TORs group reported a lower perceived risk, exhibited a higher average amplitude of saccades before the TORs, along with lower indicator variations after the TORs, as well as lower maximal braking pedal input and maximal steering wheel velocity. The perceived risk prediction model showed good performance with a mean macro-precision of 0.757, a mean balanced accuracy of 0.772, and a mean macro-F1 of 0.758.
Conclusions:
This research found that MRs before TORs were associated with reduced drivers' perceived risk, and that pre- and post-TOR physiological indicators showed potential for predicting perceived risk. These findings would inform the development of driver-state detection techniques and the design of human-machine interaction strategies.
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:10
Control Systems
At the heart...