Related Experiment Video
Updated: Jun 17, 2026
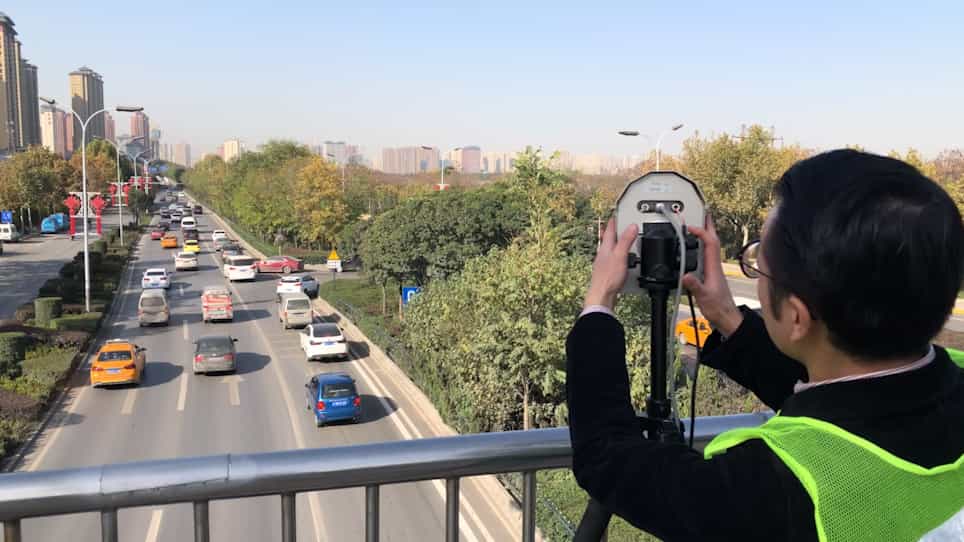

Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
Can surrogate safety measures explain crash patterns at signalized intersections? evidence from network-wide
Mehrdad Nasri1, Jingyi He1, Muhammad Monjurul Karim1
1Department of Civil and Environmental Engineering, University of Washington, Seattle, WA 98105, USA.

Introduction:
Connected-vehicle trajectories provide large-scale data for proactive, network-wide safety management, yet guidance on transforming these dense data streams into actionable indicators remains limited. This study presents a reproducible framework that extracts three surrogate safety measures (SSMs): critical deceleration rate to avoid a crash (DRAC), time-to-collision (TTC), and post-encroachment time (PET), from 54.8 million second-by-second trajectory points, mapped to 139 signalized intersections in Tucson, Arizona. Critical SSM counts were linked to five years of police-reported crashes at the same sites to quantify crash-SSM relationships.
Method:
Negative Binomial regression, Random Forest, XGBoost, and a diffusion graph neural network assessed how distributional assumptions, nonlinearities, and spatial context influence model performance. SSMs show the strongest association with low-severity crashes (no-injury and non-incapacitating), whereas severe outcomes require additional contextual and behavioral variables. In terms of collision type, rear-end and left-turn crashes are best explained by these trajectory-based surrogates, consistent with their underlying conflict mechanisms.
Results:
Results show that across every model family, DRAC is the most influential predictor. In count regressions, an additional one thousand DRAC events raises expected rear-end, left-turn, and angle crashes by 5 to 10%. DRAC ranks first in XGBoost models and pushes the coefficient of determination above 0.60 for rear-end and no-injury crashes. Permuting DRAC in the diffusion network model increases mean absolute error three- to sevenfold, whereas TTC has smaller effects and PET is negligible. Sideswipe and single-vehicle collisions are insensitive to all three surrogates, indicating the need for alternative indicators.
Conclusions:
These findings indicate that DRAC is a reliable network-wide screen for crash risk. TTC offers supplemental insight for turning and low-injury events, and PET adds little information at a one-second sampling rate.
Practical Applications:
The proposed framework demonstrates how large-scale connected-vehicle data, coupled with modern modeling techniques, can inform data-driven crash-prevention programs.