Related Experiment Video
Updated: Jun 18, 2026


A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
A physics-guided neural network framework for prediction and control of spring-mass running
Ahmet Safa Ozturk1, Ismail Uyanik2, Ömer Morgül1
1Department of Electrical and Electronics Engineering, Bilkent University, Ankara, Türkiye.

Abstract:
The spring-mass template acts as a fundamental bridge between animal locomotion and legged robotic platforms. However, controlling spring-mass dynamics involves a persistent trade-off: numerical integration offers accuracy but high computational cost, while approximate analytical solutions provide efficiency but suffer from linearization errors. To resolve this, we propose a physics-guided hybrid neural network framework for the spring-mass running template. Unlike closed-box predictors trained end-to-end, our architecture enforces flight phase physics by embedding exact analytical solutions for the tractable ballistic dynamics directly into the network structure, and learning only the non-integrable stance dynamics. This 'analytically augmented' design enhances interpretability without sacrificing accuracy. For control, we introduce a mixed-objective training strategy that combines supervised imitation with goal-conditioned learning, enabling precise trajectory tracking without the computational burden of per-step optimization. We evaluated the framework's prediction accuracy, control precision, and runtime efficiency through extensive simulations. Furthermore, we validate the robustness of the learned policies through a comprehensive basin of attraction analysis, demonstrating that the proposed networks stabilize contiguous manifolds of highly perturbed initial conditions compared to existing methods. Finally, we assessed the framework's real-world adaptability by validating our predictor against an archival experimental dataset from a physical one-legged hopper. Our results demonstrate that this hybrid approach outperforms existing analytical and data-driven methods in accuracy and robustness while maintaining the low inference times required for real-time embedded control.
Related Concept Videos
 01:17
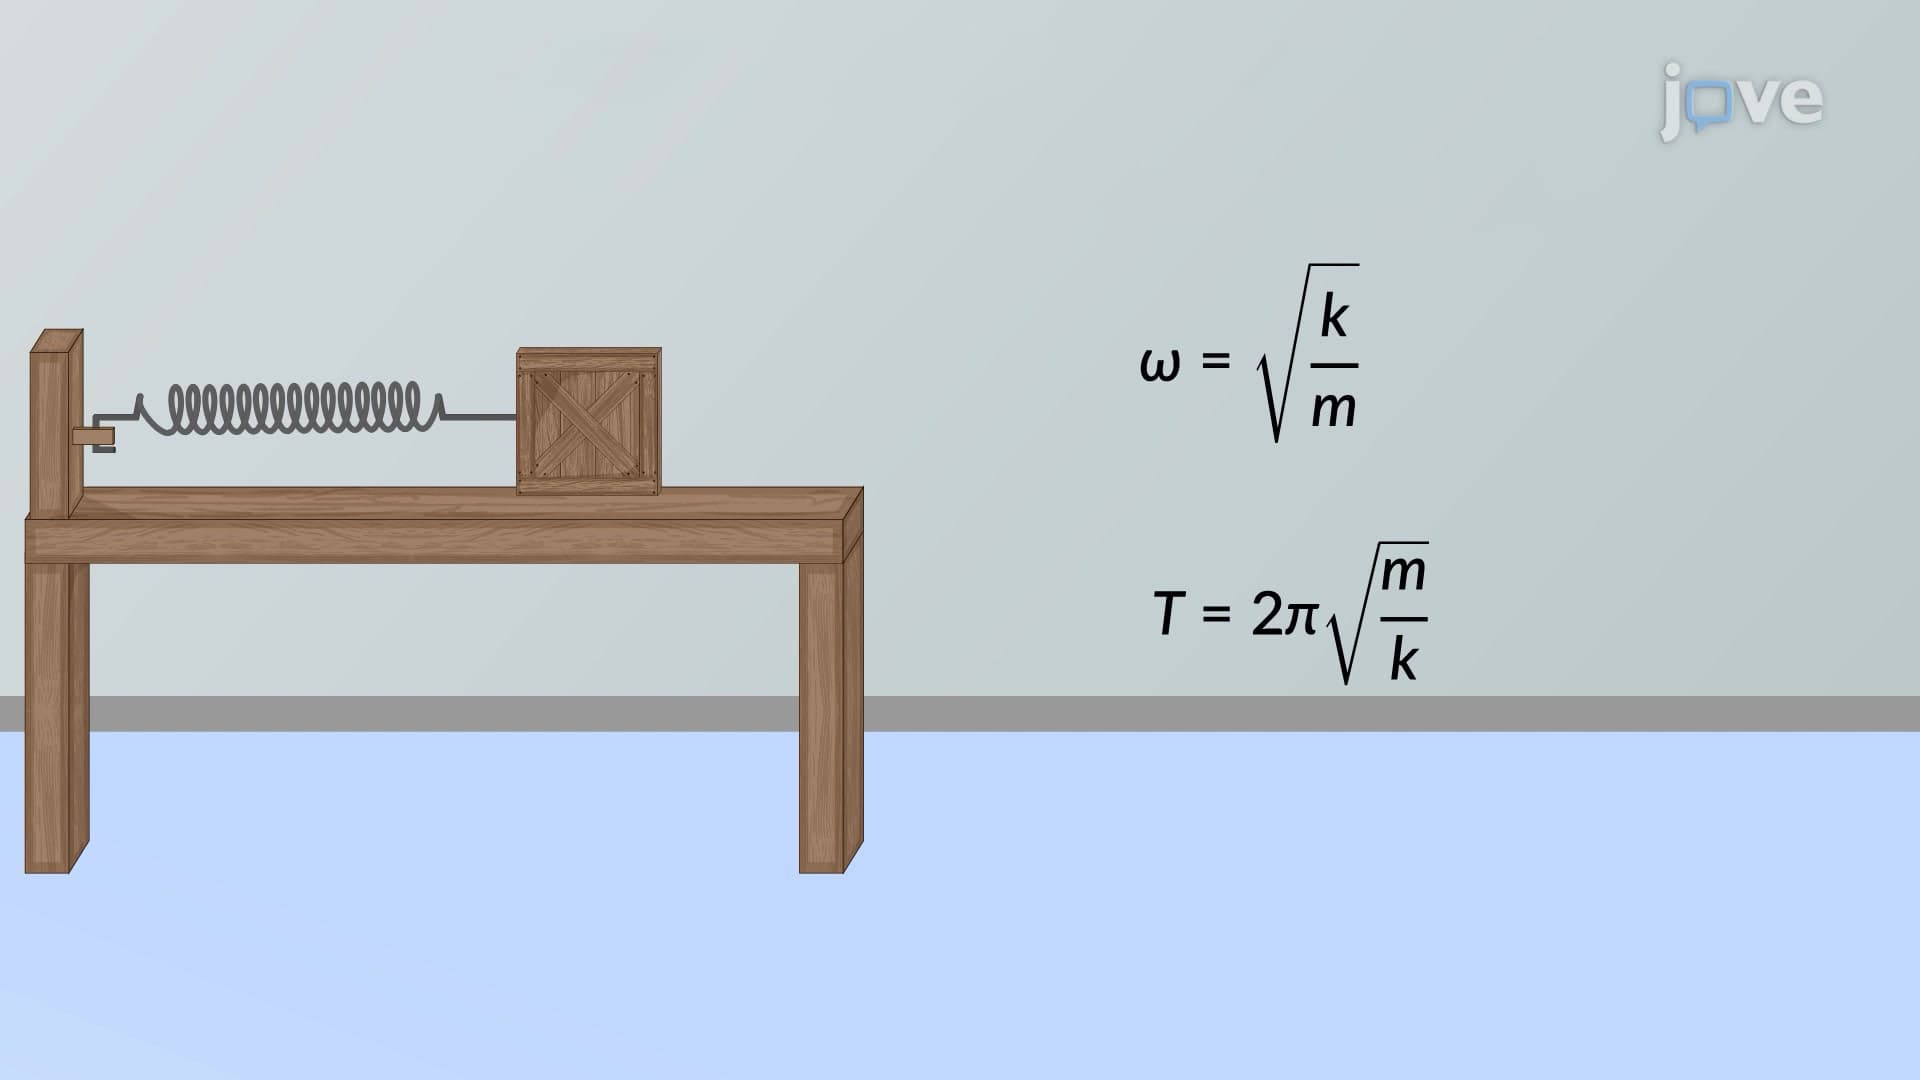
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...
 01:22
Mechanical Systems
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 00:59
Center of Mass
The knowledge of the center of mass can also help us to describe and predict the motion of objects. For example, when a ball is thrown into...
 01:30
Three-Dimensional Force System