Related Experiment Video
Updated: Jun 20, 2026

Online Virtual Reality Networked Control Laboratory Applied in Control Engineering Education
Published on: February 23, 2024
Nonlinear control design for stabilization and tracking of a rotary inverted pendulum
Arefe Shalbafian1,2, Farhad Amiri3,4
1Department of Electrical Engineering, Hamedan University of Technology, Hamedan, Iran.

Abstract:
This paper proposes a nonlinear controller framework for the tracking and stabilization control of rotary inverted pendulum (RIP) systems. These systems present significant control challenges due to their underactuation, high sensitivity, and inherent instability. Most existing studies rely on linearized models of RIP systems. However, these approaches limit the controller's performance to a small area around the equilibrium point. On the other hand, applying advanced nonlinear control techniques to the RIP underactuated system remains challenging. To overcome these limitations, the second-order sliding mode controller (SOSMC) based on a PID sliding surface is developed and applied to the RIP system. The designed procedure incorporates the nonlinear dynamic model to stabilize the pendulum in a greater region and address the challenges of underactuation. The designed control scheme enhances the system performance in stabilizing the pendulum in the vertical upright position and maintaining its balance when the horizontal arm tracks a desired trajectory. The efficacy of the designed controller is compared with three other control approaches: a standard sliding mode control (SMC), a reinforced PID-SMC, and a linear quadratic regulator (LQR). The simulation results demonstrate that the proposed controller scheme exhibits high-speed tracking performance with reduced overshoot. The results show that the Mean Square Error (MSE) for the arm angle is decreased to 0.2229, compared to 0.22346 for reinforced PID-SMC, 0.2250 for SMC, and 0.2299 for LQR. Moreover, the MSE for the pendulum angle is reduced by approximately 69.36%, 28.6%, and 25.68% compared to the reinforced PID-SMC, SMC, and LQR algorithms, respectively. Furthermore, the designed controller achieves a 41.99%, 10.06%, and 18.33% reduction in the RMS value of the control input compared to the reinforced PID-SMC, SMC, and LQR controllers, respectively. The simulation results reveal that the designed controller achieves superior tracking accuracy, faster response, and reduced overshoot, while maintaining efficient energy consumption.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:09
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:13
Stability of Equilibrium Configuration: Problem Solving
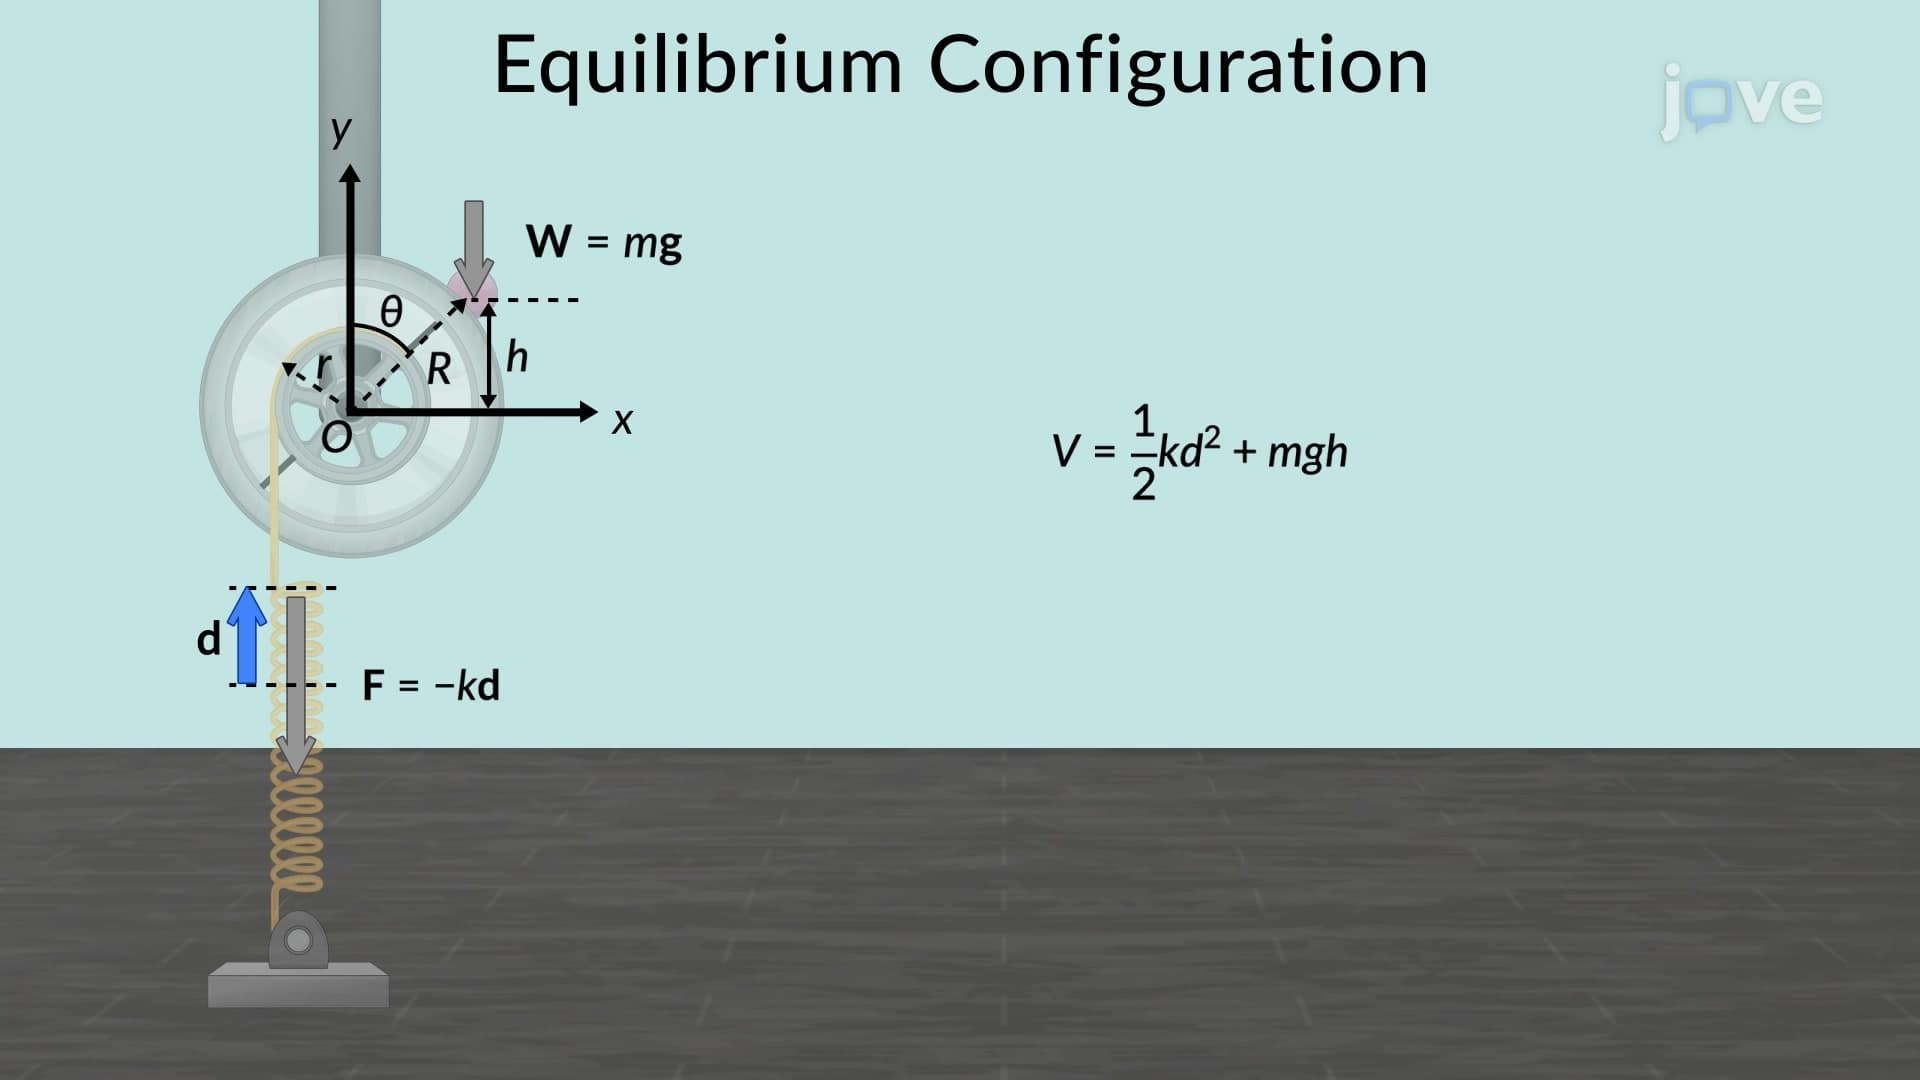
Problem-solving in the context of the stability of equilibrium configuration...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...