Related Experiment Video
Updated: Jun 25, 2026
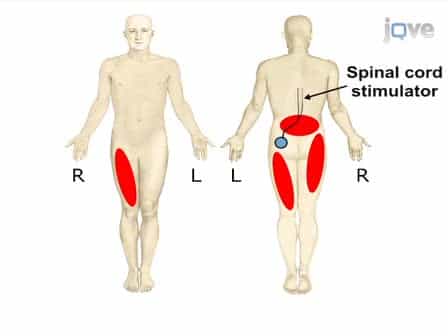

Dorsal Column Steerability with Dual Parallel Leads using Dedicated Power Sources: A Computational Model
Published on: February 10, 2011
Data-Driven Steering Control for Heterogeneous Autonomous Vehicle Platoons via Interval Excitation-Based Learning

Abstract:
This article investigates the path following problem for heterogeneous two-degree-of-freedom (2-DoF) autonomous ground vehicle platoons (AGVPs) with unknown dynamics. The control objective is formulated as an inhomogeneous linear quadratic tracking (LQT) problem, aiming to minimize the lateral relative offset and heading error between the following vehicle and its preceding vehicle by designing the steering angle. To overcome the reliance on accurate system models, a novel data-driven control scheme is proposed. First, a model-based iterative learning algorithm is proposed using the matrix decomposition method. This algorithm removes the requirement for an initial stabilizing control policy while guaranteeing the convergence speed. Furthermore, it avoids the ill-conditioned numerical issues caused by small discount factors in LQT problems. Furthermore, the algorithm is extended to a data-driven implementation via a double-layer integral structure, which relaxes the persistence-of-excitation (PE) condition to the interval excitation (IE) condition. The proposed algorithm can iteratively solve the optimal LQT controller from any initial policy, while reducing the computational complexity and eliminating the requirement for historical data storage. Finally, the simulation results demonstrate the feasibility and superiority of the proposed method.
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:18
Hierarchy of Motor Control
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:19
PID Controller
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...