Related Experiment Video
Updated: Jun 25, 2026


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
A driving simulator study on drivers' reactions to sudden appearing of a Powered Two-Wheeler in a left-turn manoeuvre
Costanza Carini1, Andrea Paliotto1, Monica Meocci1
1Department of Civil and Environmental Engineering, University of Florence 50139 Florence, Italy.

Abstract:
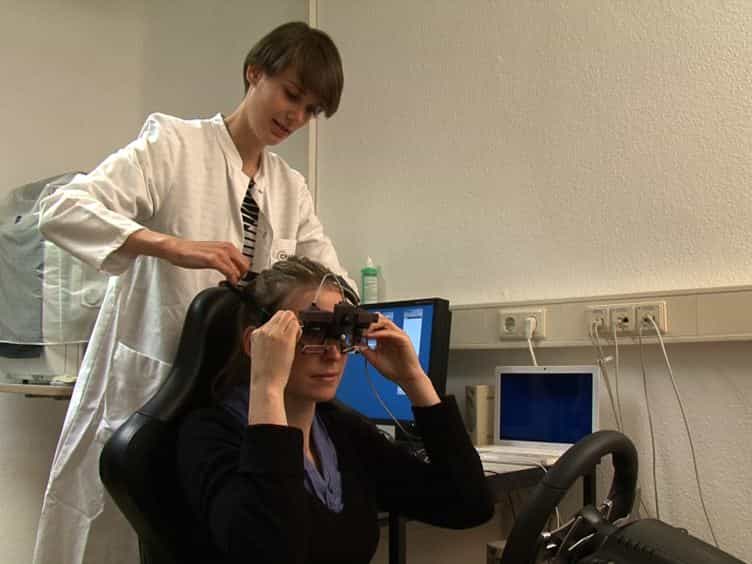
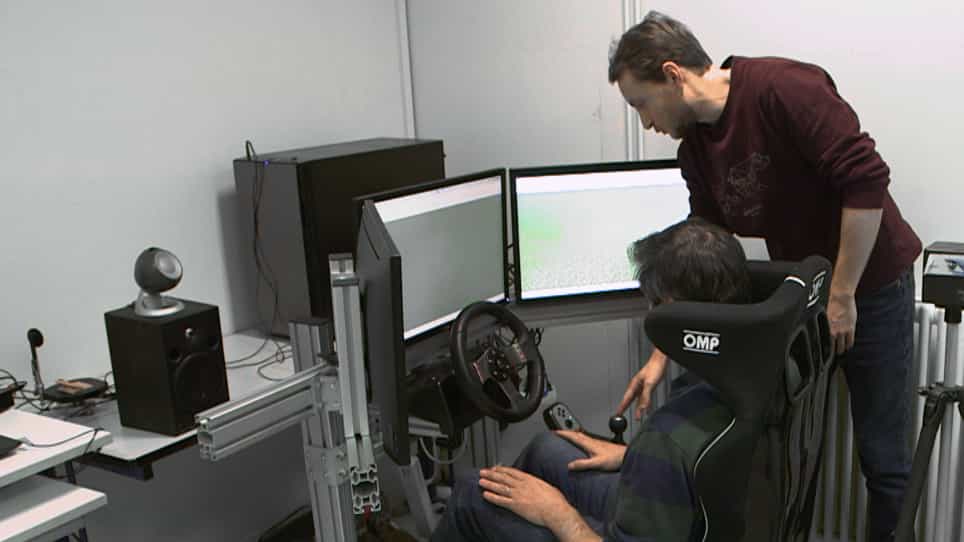
Nowadays, it is widely recognised that most accidents are caused by human errors and many of them are related to the delay in reacting to sudden stimuli. Even small delays in reaction time can have substantial implications, as they directly affect the stopping distance and the ability to avoid potential hazards. The driving simulator study carried out aims at investigating the reaction time and type of drivers in a critical scenario. The scenario considered is a T-intersection where the ego vehicle is driving on the main road and must turn left at the intersection. While the vehicle is turning, a Powered Two-Wheeler (PTW) travelling in the opposite direction suddenly appears and crosses the trajectory of the ego vehicle. Eye-tracking glasses were used to determine where the driver's gaze was directed throughout the simulation. Many different parameters have been studied in the experiment. The relationship between the 70 participants' characteristics (gender, age, experience) has been related to the reaction times and reaction types (breaking or steering). Additional parameters have been also studied considering their influence on reaction time, such as the position of the gaze in the field of view when the PTW appears. The results show an average response time of about 0.9 s from the moment the PTW appears and the start of the reaction, with a large predominance of steering manoeuvres. Such results can be also useful in the development of in-vehicle systems able to inform the driver about a danger or autonomously react to it.
Related Concept Videos
 01:29
Sight Distance in a Vertical Curve
 01:17
Dynamics Of Circular Motion: Applications
 01:17
Rolling Resistance: Problem Solving
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:29
Evaluating Limits by Direct Substitution
 01:22
Multi-input and Multi-variable systems
In the absence of...