Related Experiment Video
Updated: Jun 26, 2026
Cardiac Muscle-cell Based Actuator and Self-stabilizing Biorobot - PART 1
Published on: July 11, 2017
Characterization and Optimization of Intelligent Dampers Based on Bionic Principles
Niancheng Guo1,2, Yujing Zhang1,2, Hao Cheng1,2
1School of Mechanical Engineering, Shandong University, Jinan 250061, China.

Abstract:
From the perspective of human vibration perception, reducing vibration stimuli transmitted to occupants is essential for improving ride comfort and reducing fatigue. Intelligent dampers, as key actuators in semi-active suspension systems, provide adjustable damping capabilities for vibration control. This article combines them with biomimetic control principles to study the vibration control of semi-active suspension. The effects of damper forward and inverse models, damping force ranges, and time delays on suspension performance were analyzed. The results show that a function prediction-based damper model, a damping force range below 0.2 times and above 1.4 times the passive curve, and a 10 ms delay could balance vibration reduction and economy. Particle swarm optimization is used to optimize LQR control parameters for different road grades and typical speeds. Inspired by the adaptive behavior of chameleons, graded weights are assigned according to road characteristics, with greater emphasis on comfort on Grade A and B roads and driving stability on Grade C and D roads. The results show that proper matching of damper models and parameter constraints can fully exploit the adjustable damping capability of smart dampers. These findings provide a theoretical basis for designing and optimizing semi-active suspension control strategies.
Related Concept Videos
 01:22
Mechanical Systems
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:20
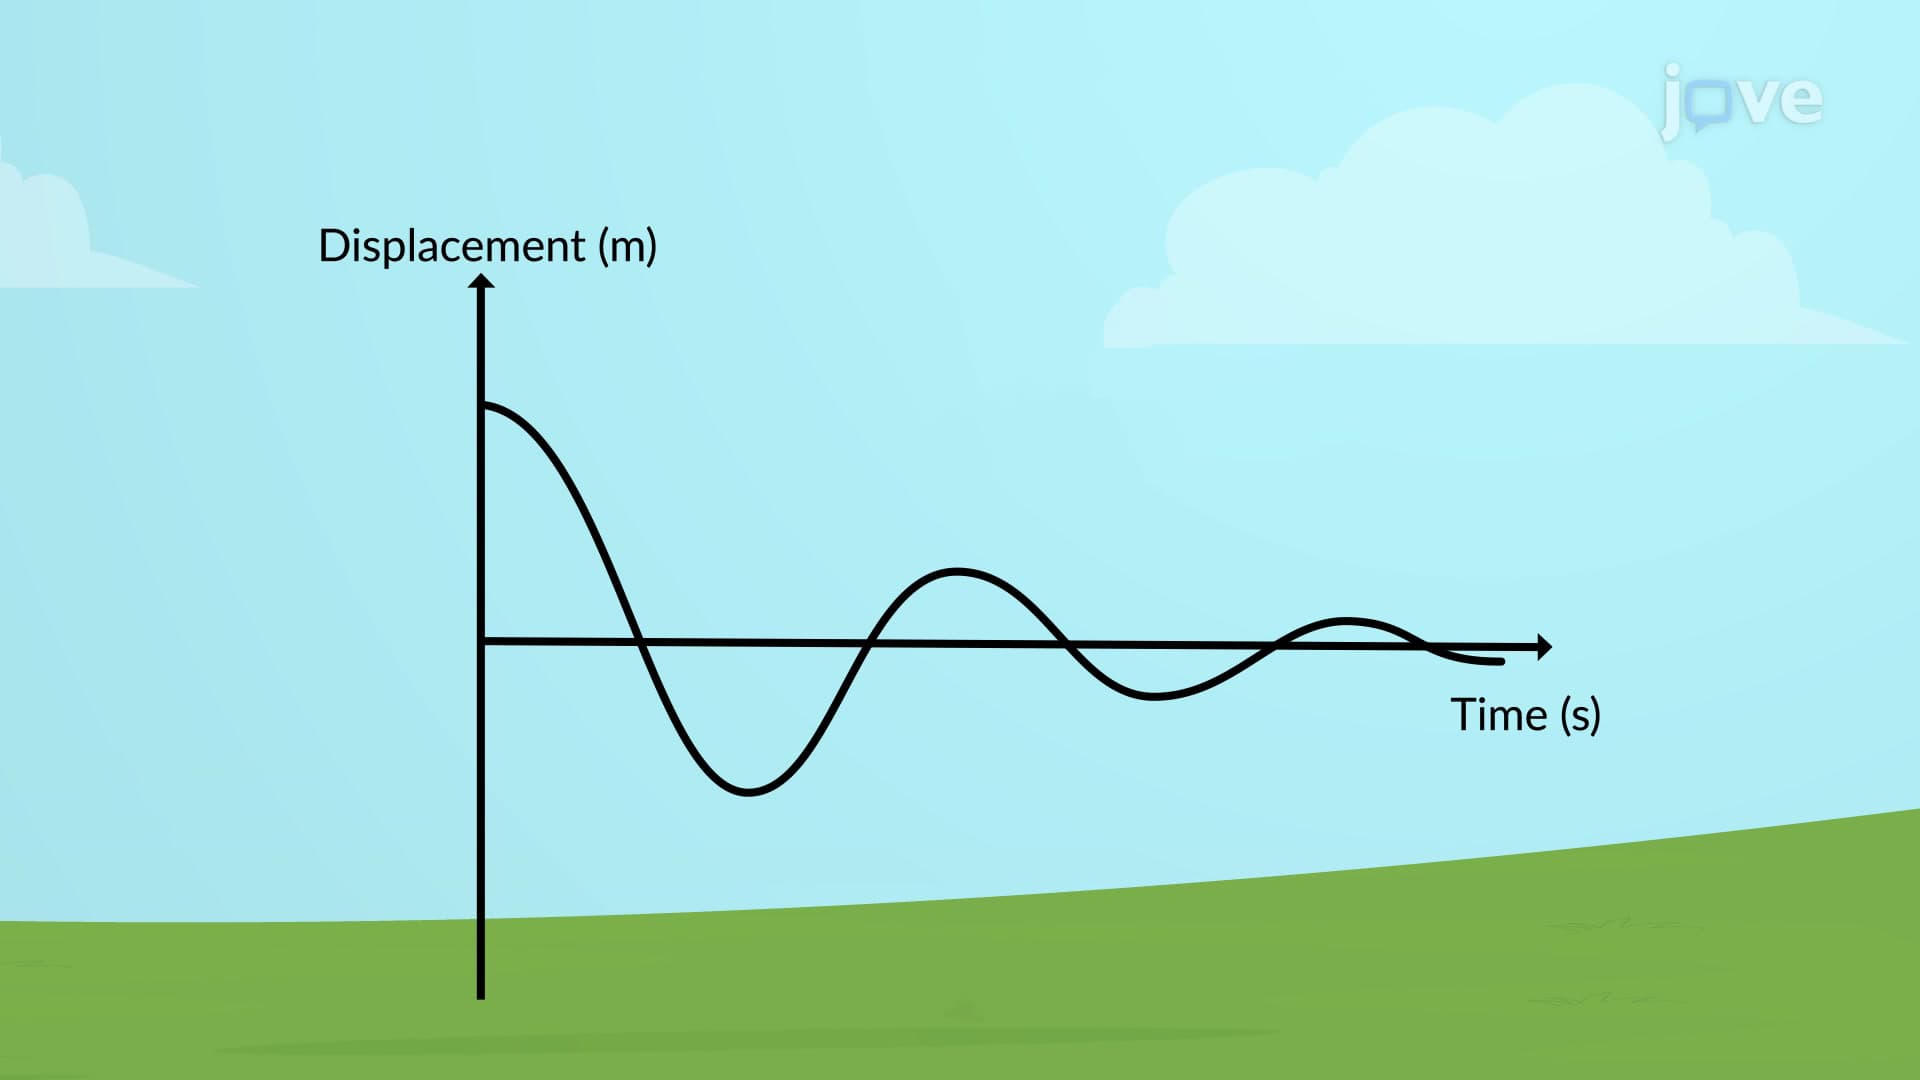
Types of Damping
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:14
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...