Related Experiment Video
Updated: Jun 27, 2026

Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy (iPALM)
Published on: December 1, 2016
Linearly Solving Robust Rotation Estimation

Abstract:
Rotation estimation plays a fundamental role in computer vision and robot tasks, and extremely robust rotation estimation is significantly useful for safety-critical applications. Typically, estimating a rotation is considered a non-linear and non-convex optimization problem that requires careful design. However, in this paper, we provide some new perspectives that solving a rotation estimation problem can be reformulated as solving a linear model fitting problem without dropping any constraints and without introducing any singularities. In addition, we explore the dual structure of a rotation motion, revealing that it can be represented as a great circle on a quaternion sphere surface. Accordingly, we propose an easily understandable voting-based method to solve rotation estimation. The proposed method exhibits exceptional robustness to noise and outliers and can be computed in parallel with graphics processing units (GPUs) effortlessly. Particularly, leveraging the power of GPUs, the proposed method can obtain a satisfactory rotation solution for large-scale ($10 ^{6}$106) and severely corrupted (99$\%$% outlier ratio) rotation estimation problems under 0.5 seconds. Furthermore, to validate our theoretical framework and demonstrate the superiority of our proposed method, we conduct controlled experiments and real-world dataset experiments. These experiments provide compelling evidence supporting the effectiveness and robustness of our approach in solving rotation estimation problems.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:16
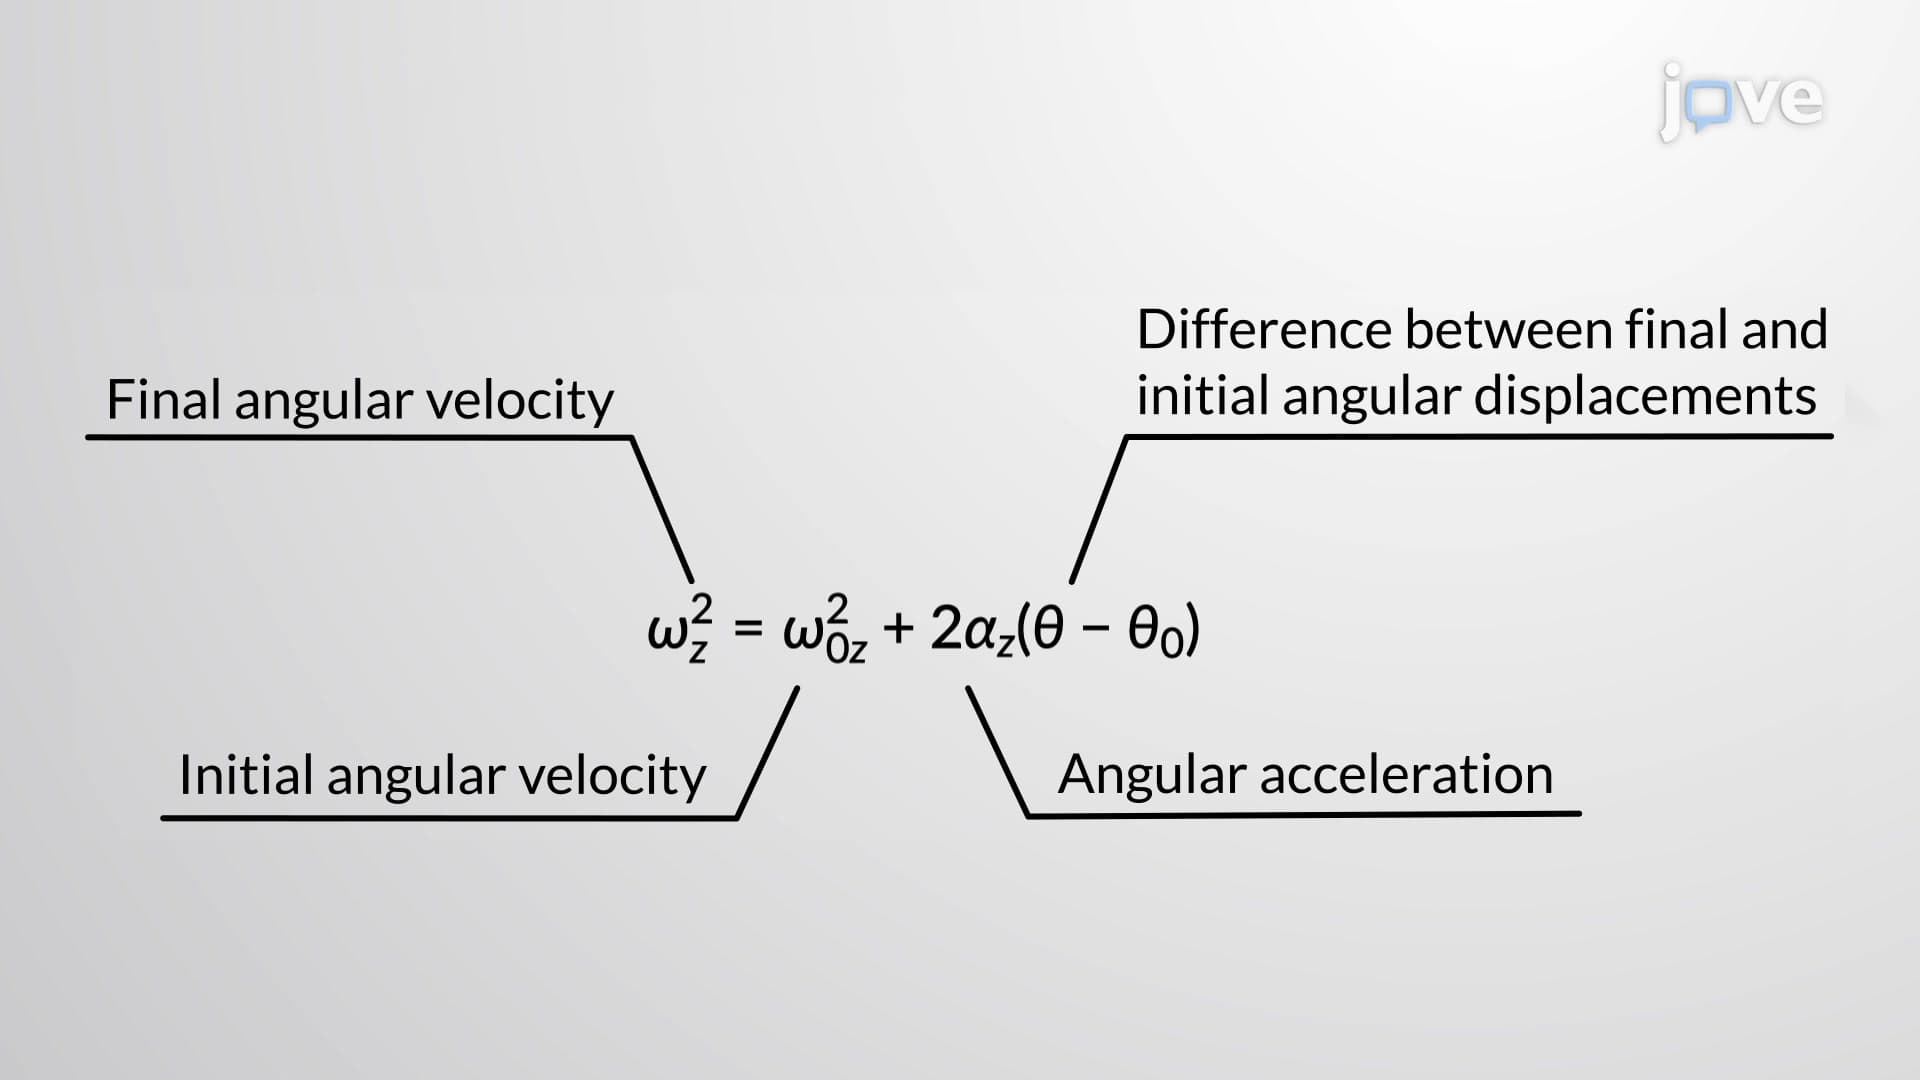
Rotation with Constant Angular Acceleration - II
The first...
 01:13
Angle of Twist: Problem Solving