Related Experiment Video
Updated: Jun 28, 2026
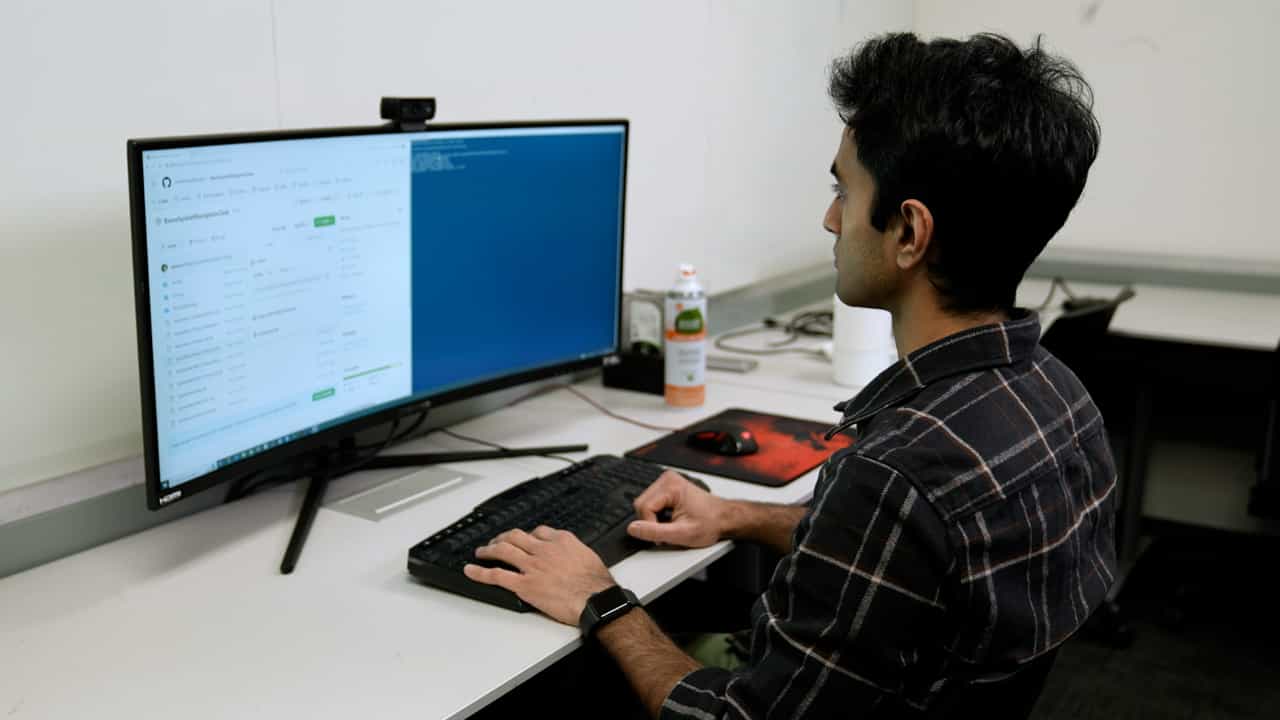

Assessing Human Spatial Navigation in a Virtual Space and its Sensitivity to Exercise
Published on: January 26, 2024
Composing trajectories for rapid inference of navigational goals
Nada Y AbdelRahman1, Wan-Chen Jiang2, Luke T Coddington1
1Janelia Research Campus, Howard Hughes Medical Institute, Ashburn, VA 20147, USA.

Abstract:
Animals efficiently learn to navigate their environment. In the laboratory, naive mice can localize new spatial targets within a handful of trials. It is unclear how such efficiency is possible, as existing models require far more experience to achieve comparable performance. Taking inspiration from behavior as mice learned to intercept hidden spatial targets, we designed agents that generate structured behavioral trajectories by controlling their speed and angular velocity between anchor points. To rapidly learn good anchors, agents use Bayesian inference on past trajectories to infer the probability that an anchor will be successful and active sampling to refine hypothesized anchors. Agents learn within tens of trials to intercept a hidden target, capturing the evolution of behavioral structure and the upper limits of learning efficiency observed in mice. This algorithm further explains how mice avoid obstacles and rapidly adapt to target switches, and it naturally encompasses both egocentric and allocentric strategies for navigation.
Related Concept Videos
 01:26
Orthogonal Trajectories
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:29
Real-World Applications of Space Curves
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:30
Vector Functions and Motion: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...