Related Experiment Video
Updated: Jul 2, 2026
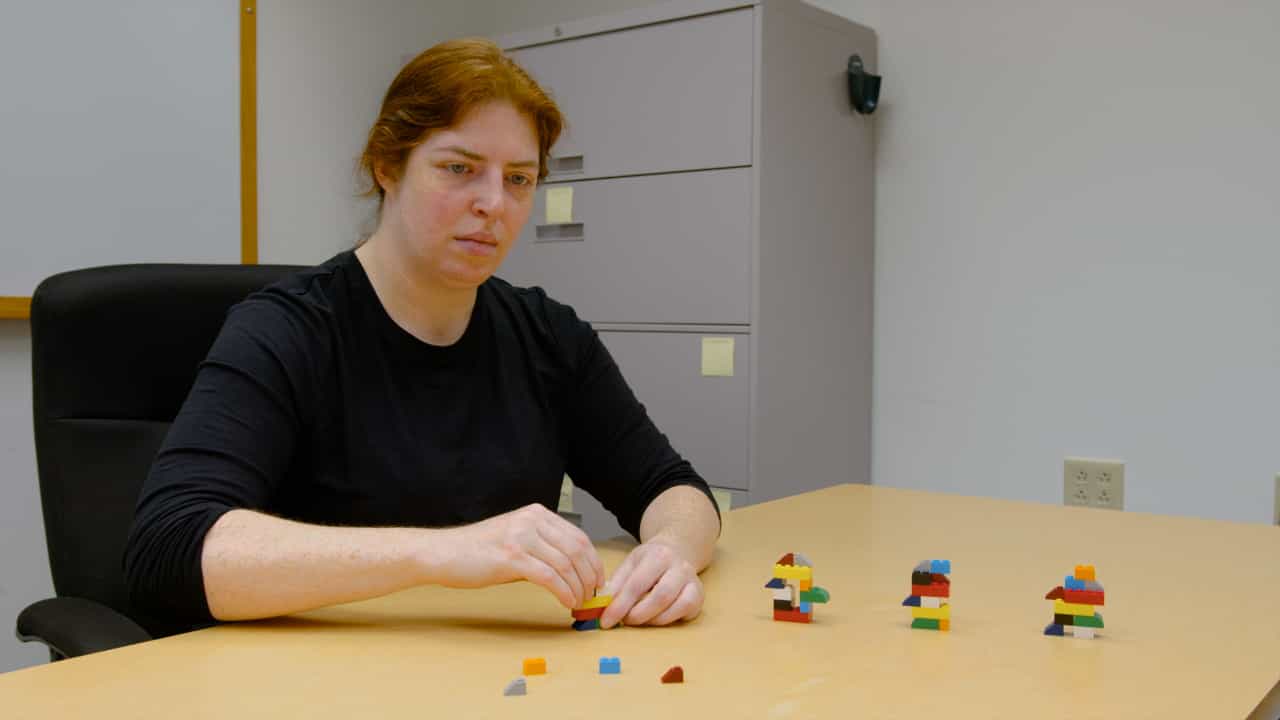

Block Building Task Identifies Distinct Groups of Left/Right-hand Choice Patterns After Unilateral Peripheral Nerve Injury
Published on: March 21, 2025
Arm dominance is an emergent effect of practice executing complex trajectory shapes required by tools and objects
Ahmet Arac1, Nicolas Y H Jeong Lee1, John W Krakauer2,3
1Department of Neurology, David Geffen School of Medicine, University of California, Los Angeles, CA 90095.

Abstract:
Limb dominance is a human behavioral characteristic with many cultural, practical, scientific, and clinical implications. Yet why the dominant limb performs better across a range of motor skill-requiring tasks remains unanswered. Is it because of an intrinsic hemispheric advantage or instead is it the result of life-long practice with the dominant side? We tested these alternatives using two tasks either cross sectionally or after training. The first was 3D reaching with either an inertial challenge or the need to use a stick-like tool. The second required participants to write with their dominant and nondominant elbows. We applied a geometric analysis to quantify movement-trajectory shape. We show that 1) tool-use unmasks markedly inferior control in the nondominant arm, and this is because tools impose the need to generate unfamiliarly shaped movement trajectories; and 2) there is no general dominant limb motor control advantage, only task-specific experience or practice riding on top of an initial preference. These results reframe dominance as predominantly about learned control of tool kinematics rather than baseline asymmetry in control of limb dynamics.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:27
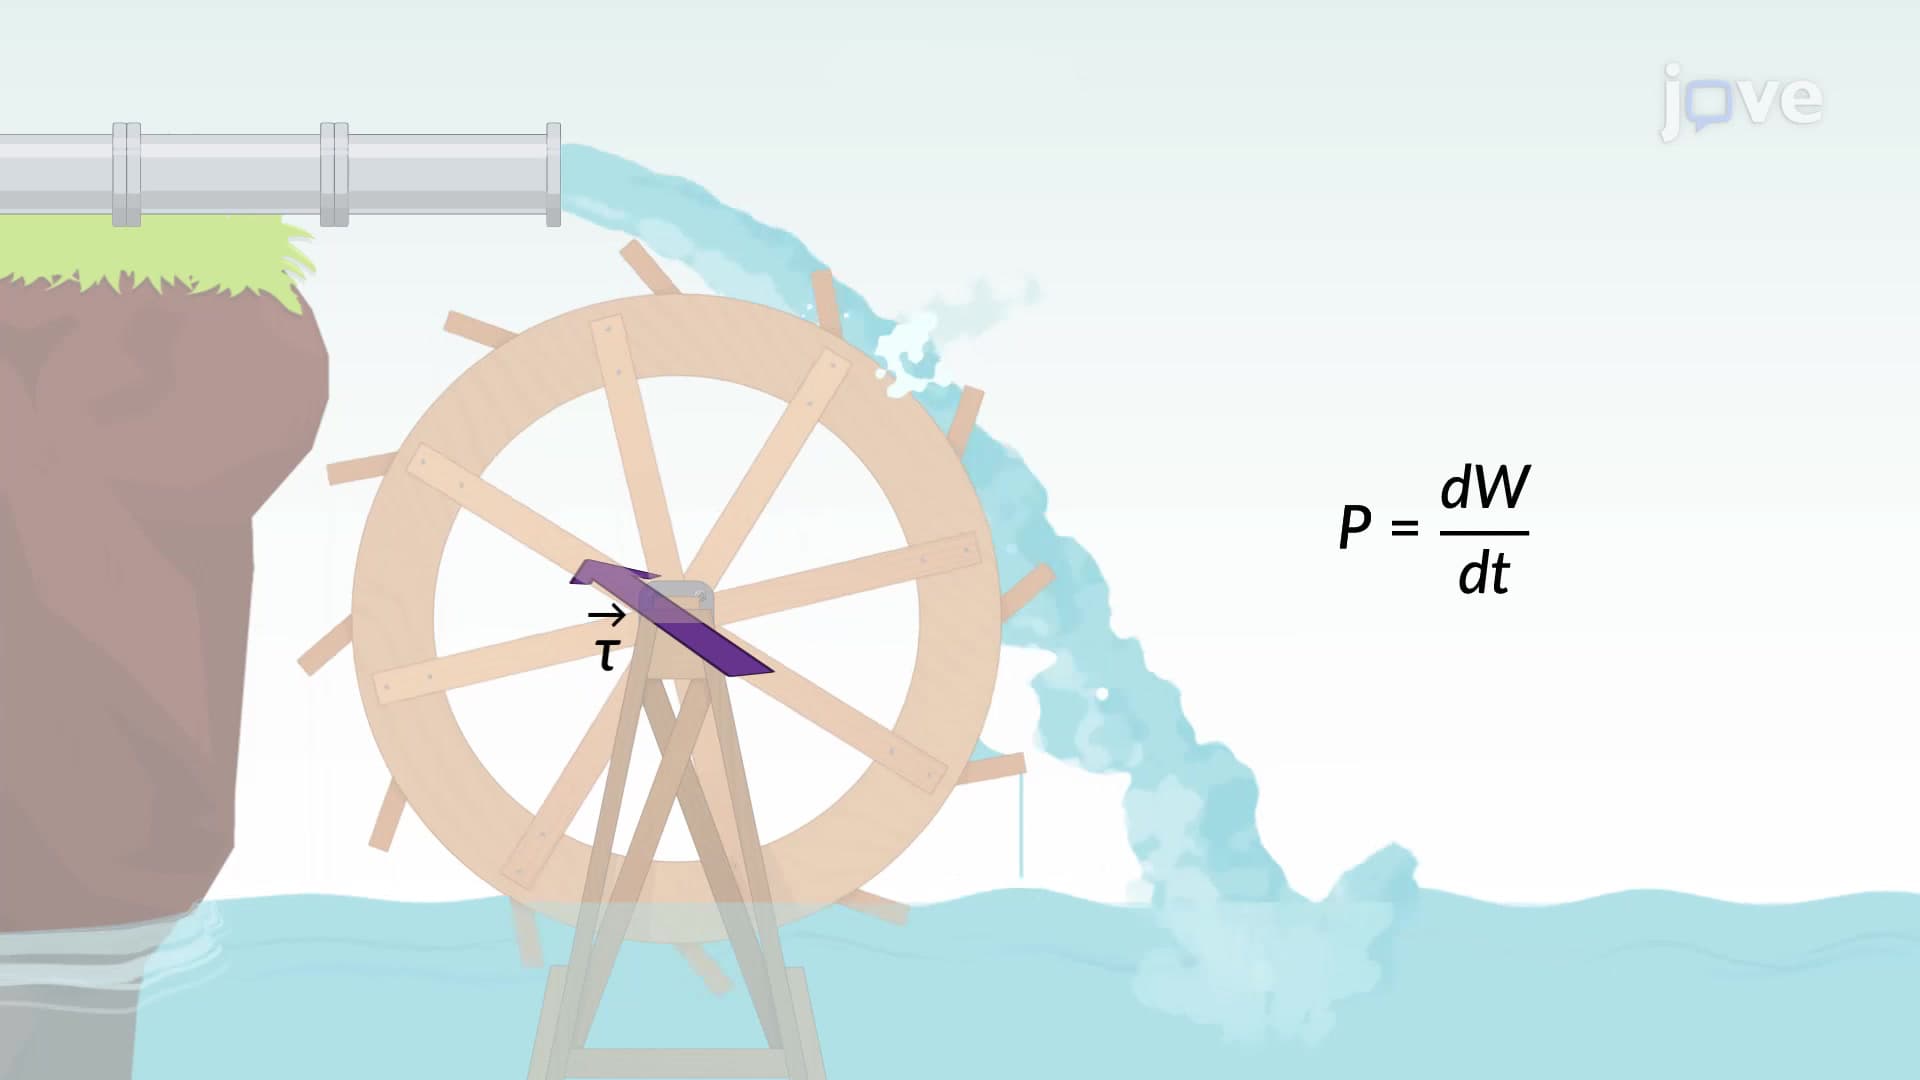
Work and Power for Rotational Motion
Similarly, the power delivered to a system that is rotating about a fixed axis is given by the...
 01:07
Moment of Inertia of Compound Objects
Consider a child of mass (mc) 25 kg standing at a distance (rc) of 1 m from the axis of a rotating...
 01:43
Incomplete Dominance
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...