Related Experiment Video
Updated: Jul 3, 2026


Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Multiaxial vibration dataset obtained on a triaxial electrodynamic shaker rig using multiple control strategies
Christophe Gautrelet1, Leila Khalij1, Carole Dovillaire2
1INSA Rouen Normandie, Normandie Univ, LMN UR 3828, F-76000, Rouen, France.

Abstract:
This article presents an experimental vibration dataset obtained on a triaxial electrodynamic shaker rig, equipped with a magnesium cube fixture instrumented with five triaxial and three single-axis accelerometers. Eleven sweep-sine and random vibration tests were conducted over the 5-2000 Hz frequency range using four closed-loop control strategies and acquisition settings corresponding to 1600 frequency lines (1.25 Hz frequency resolution). The dataset includes raw, Frequency Response Functions (FRFs), Power Spectral Densities (PSDs), and coherence matrices acquired using the Jaguar MIMO control system. The measurements highlight the strong influence of fixture resonances and sensor location on spatial acceleration variability and control stability, particularly above 1500 Hz where low-amplitude compression was required. The dataset can support benchmarking of multiaxial control strategies, assessment of spatial variability, and validation of numerical models for structural dynamics and vibration qualification.
Related Concept Videos
 01:16
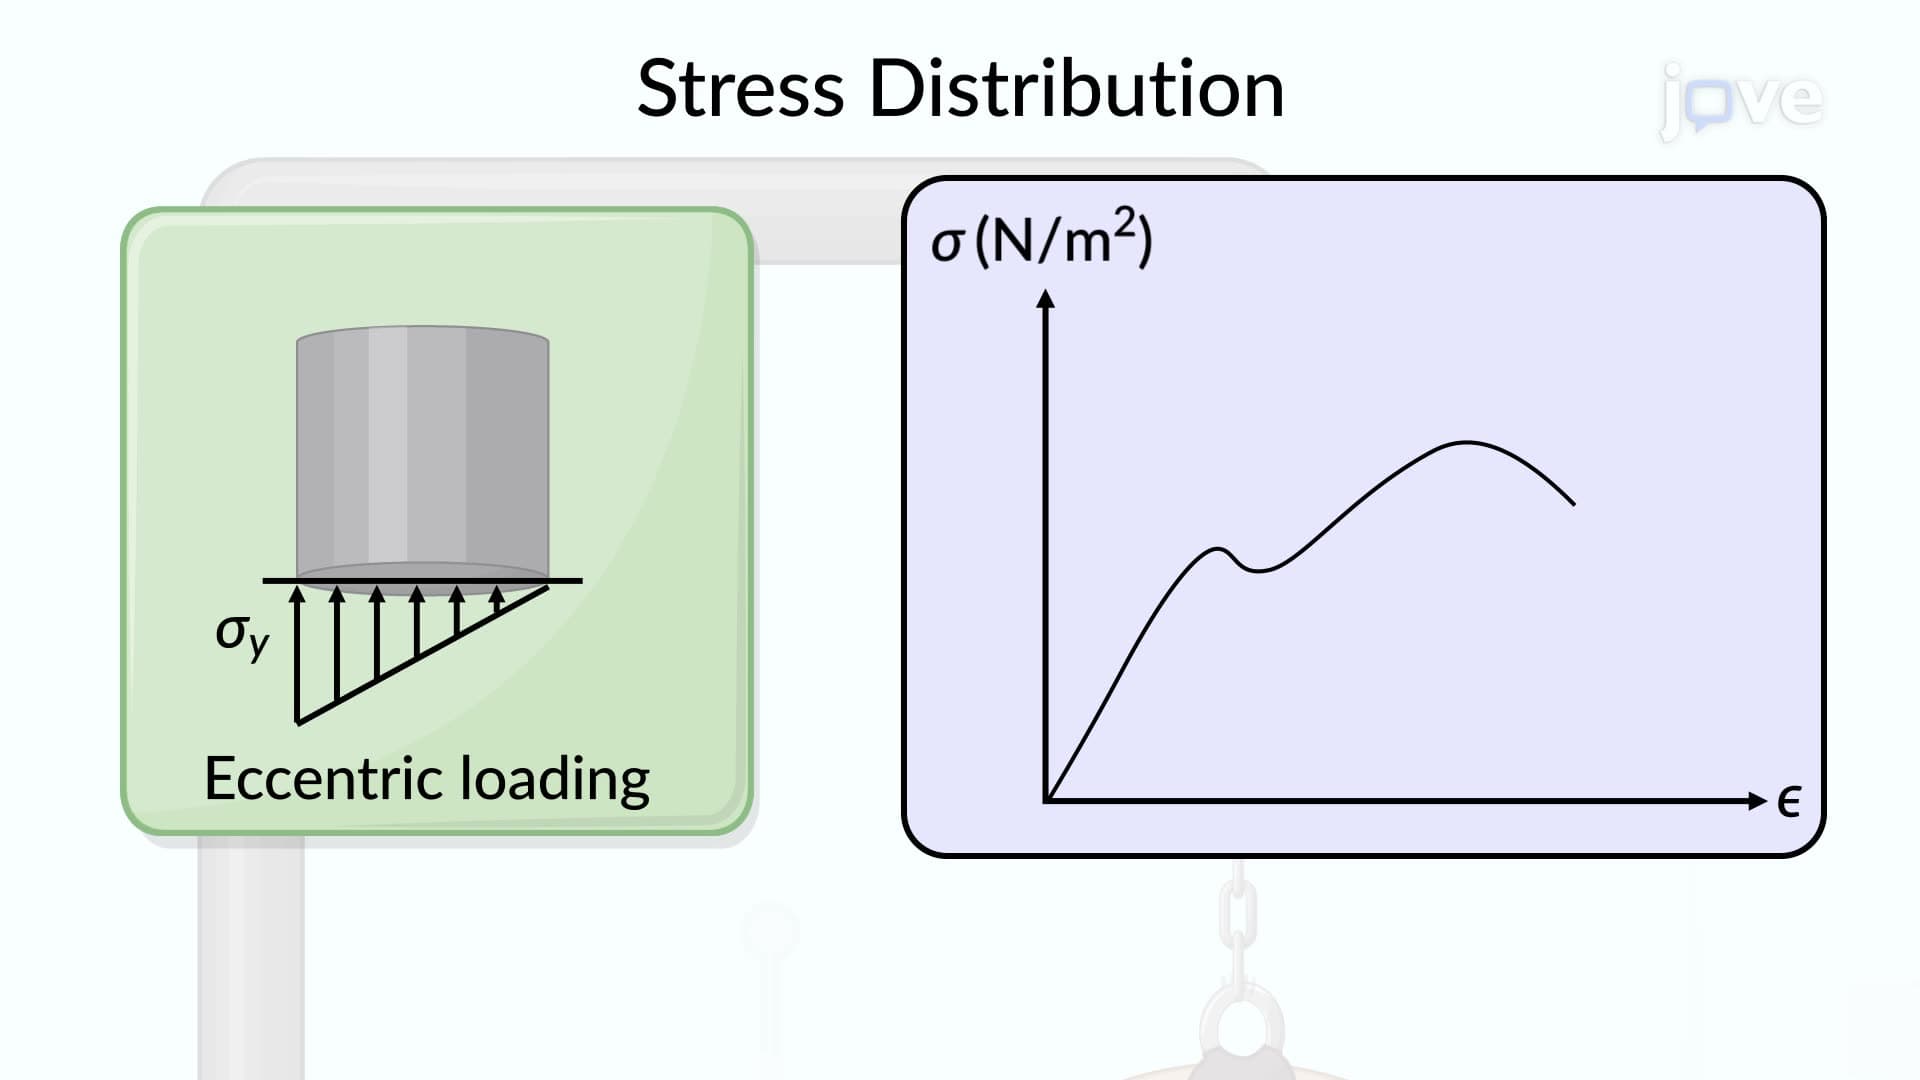
Eccentric Axial Loading in a Plane of Symmetry
 01:09
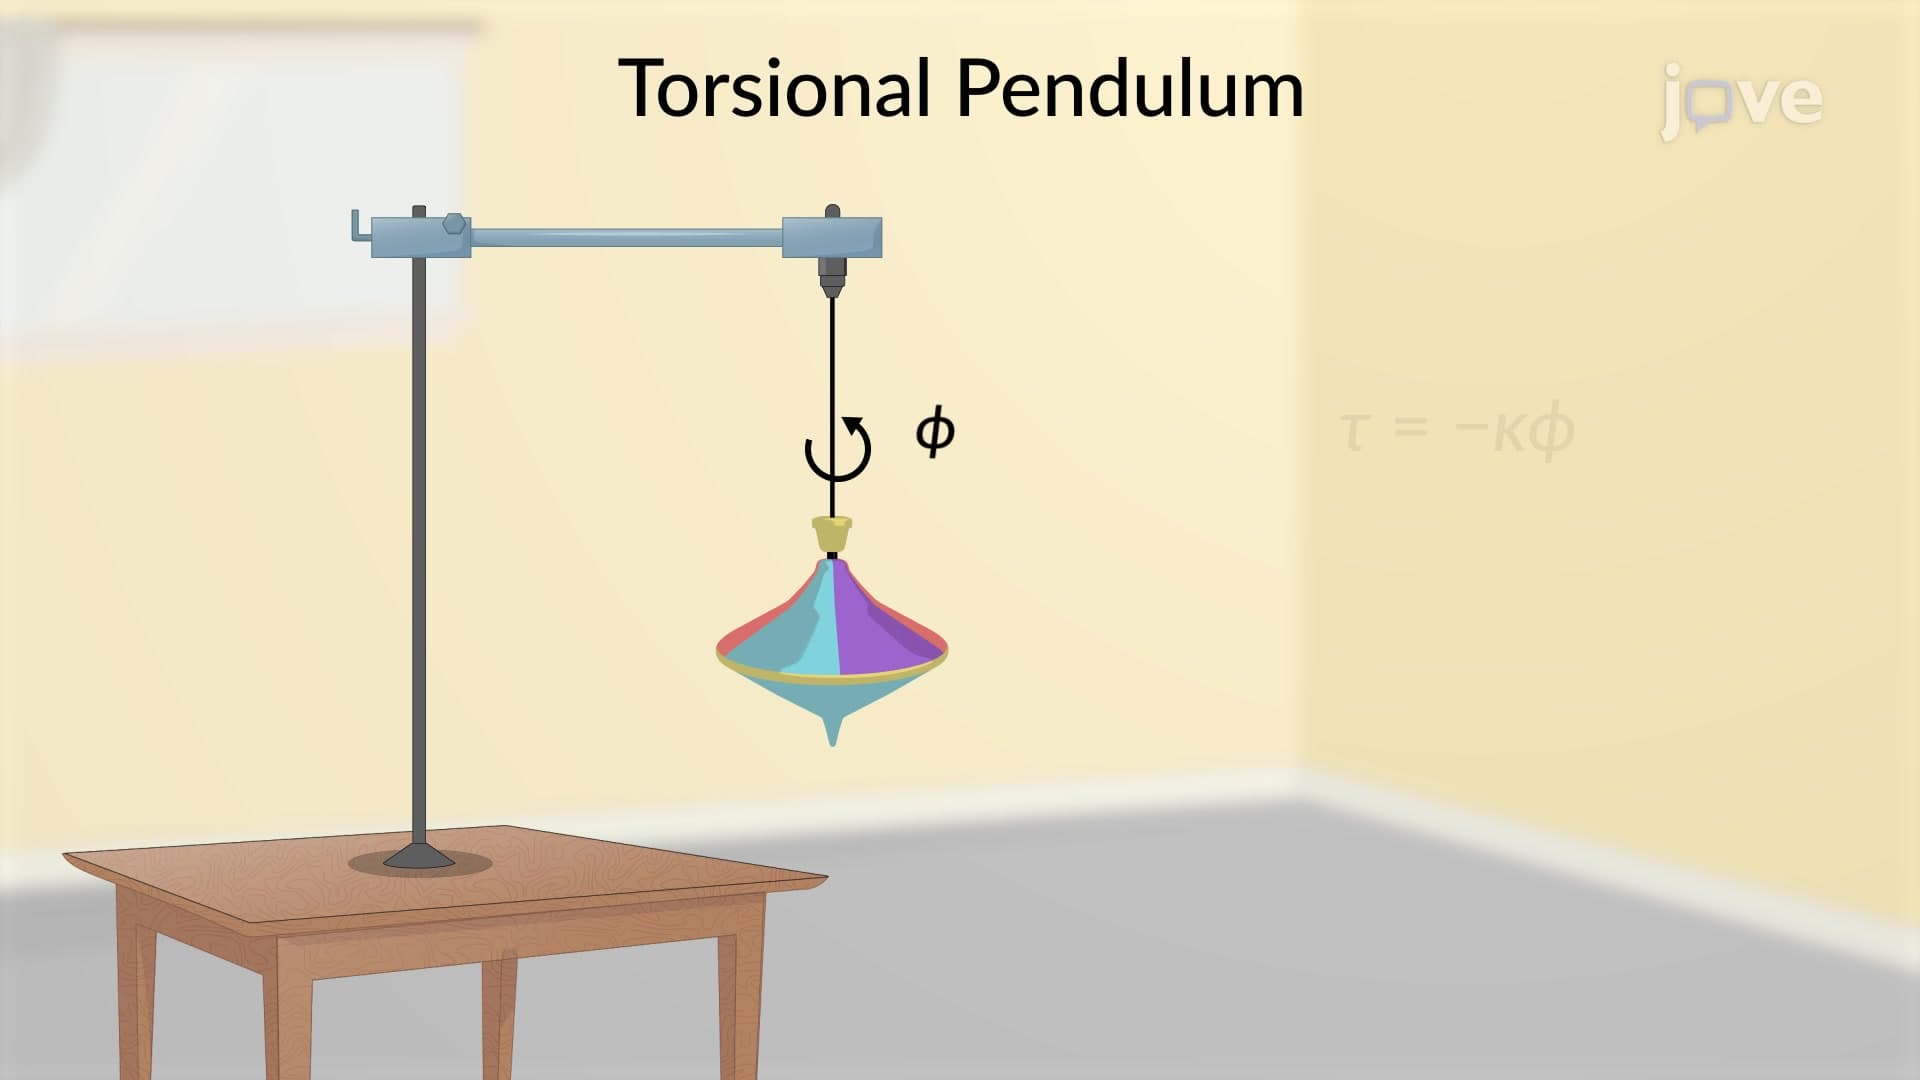
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:12
General Case of Eccentric Axial Loading
Consider a member subjected to equal and opposite forces that are applied along a line that does not coincide with the member's neutral axis. In unsymmetrical bending,...
 01:20
Normal Strain under Axial Loading
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...